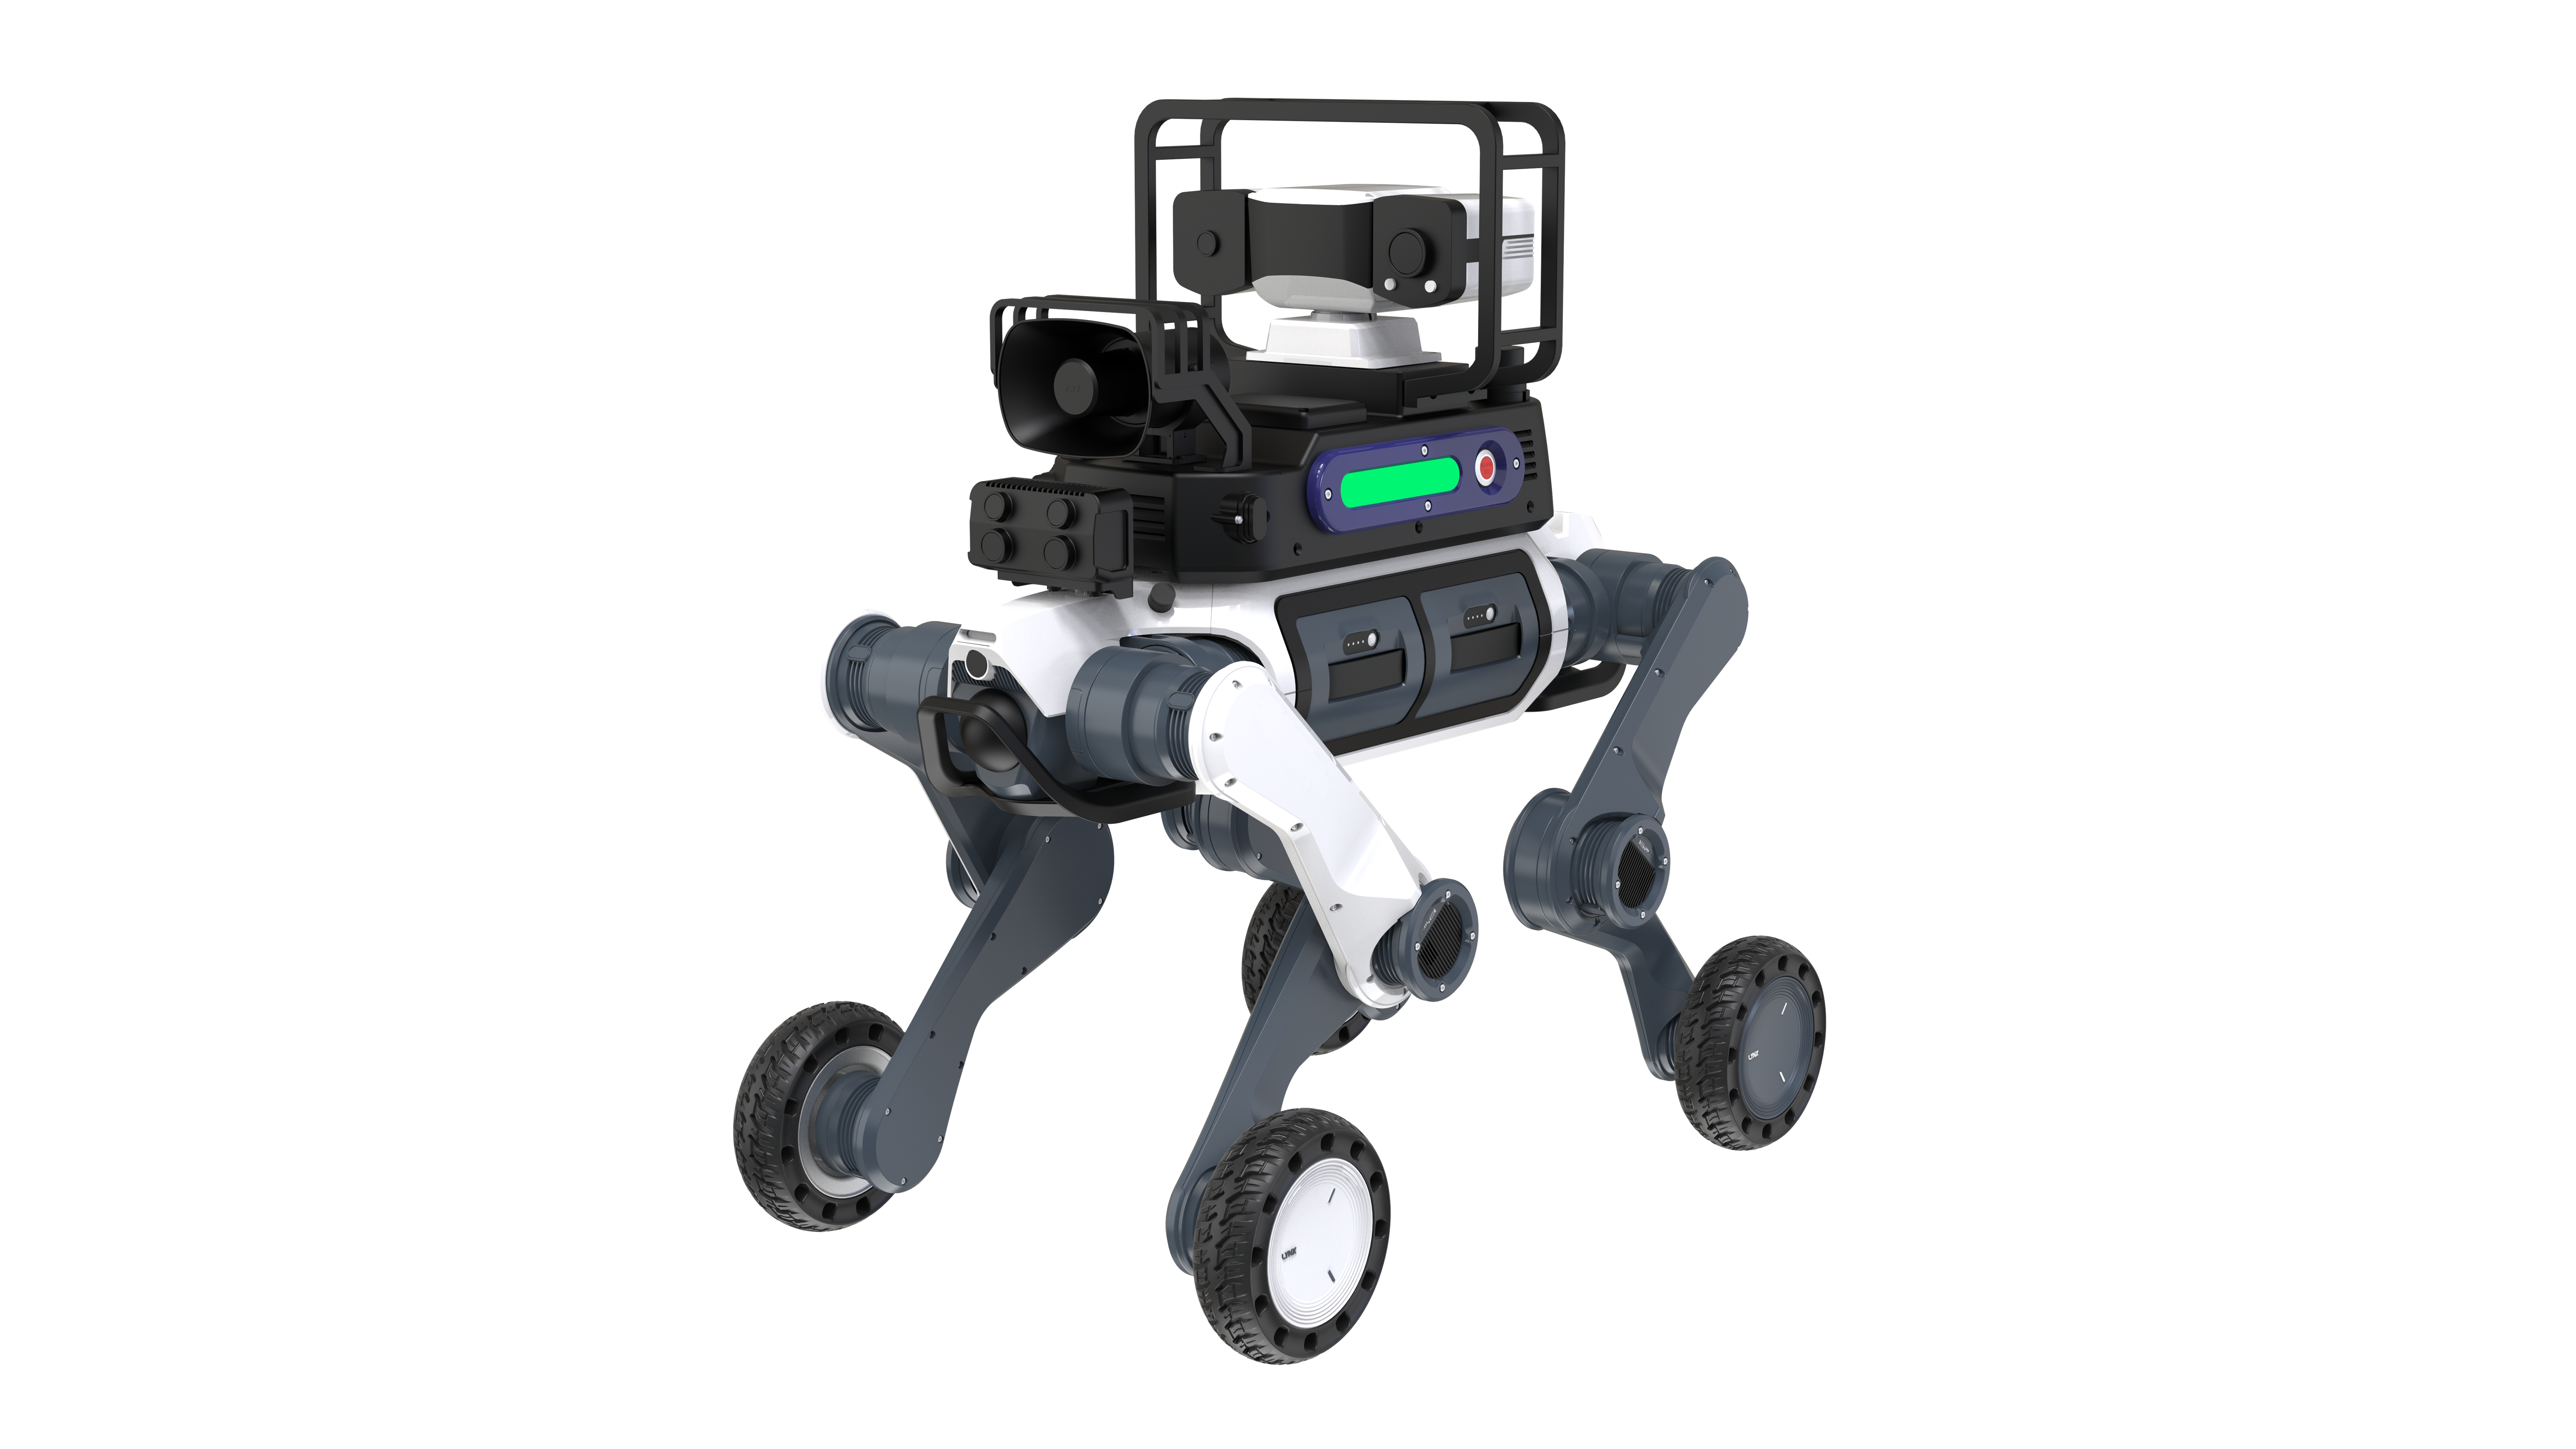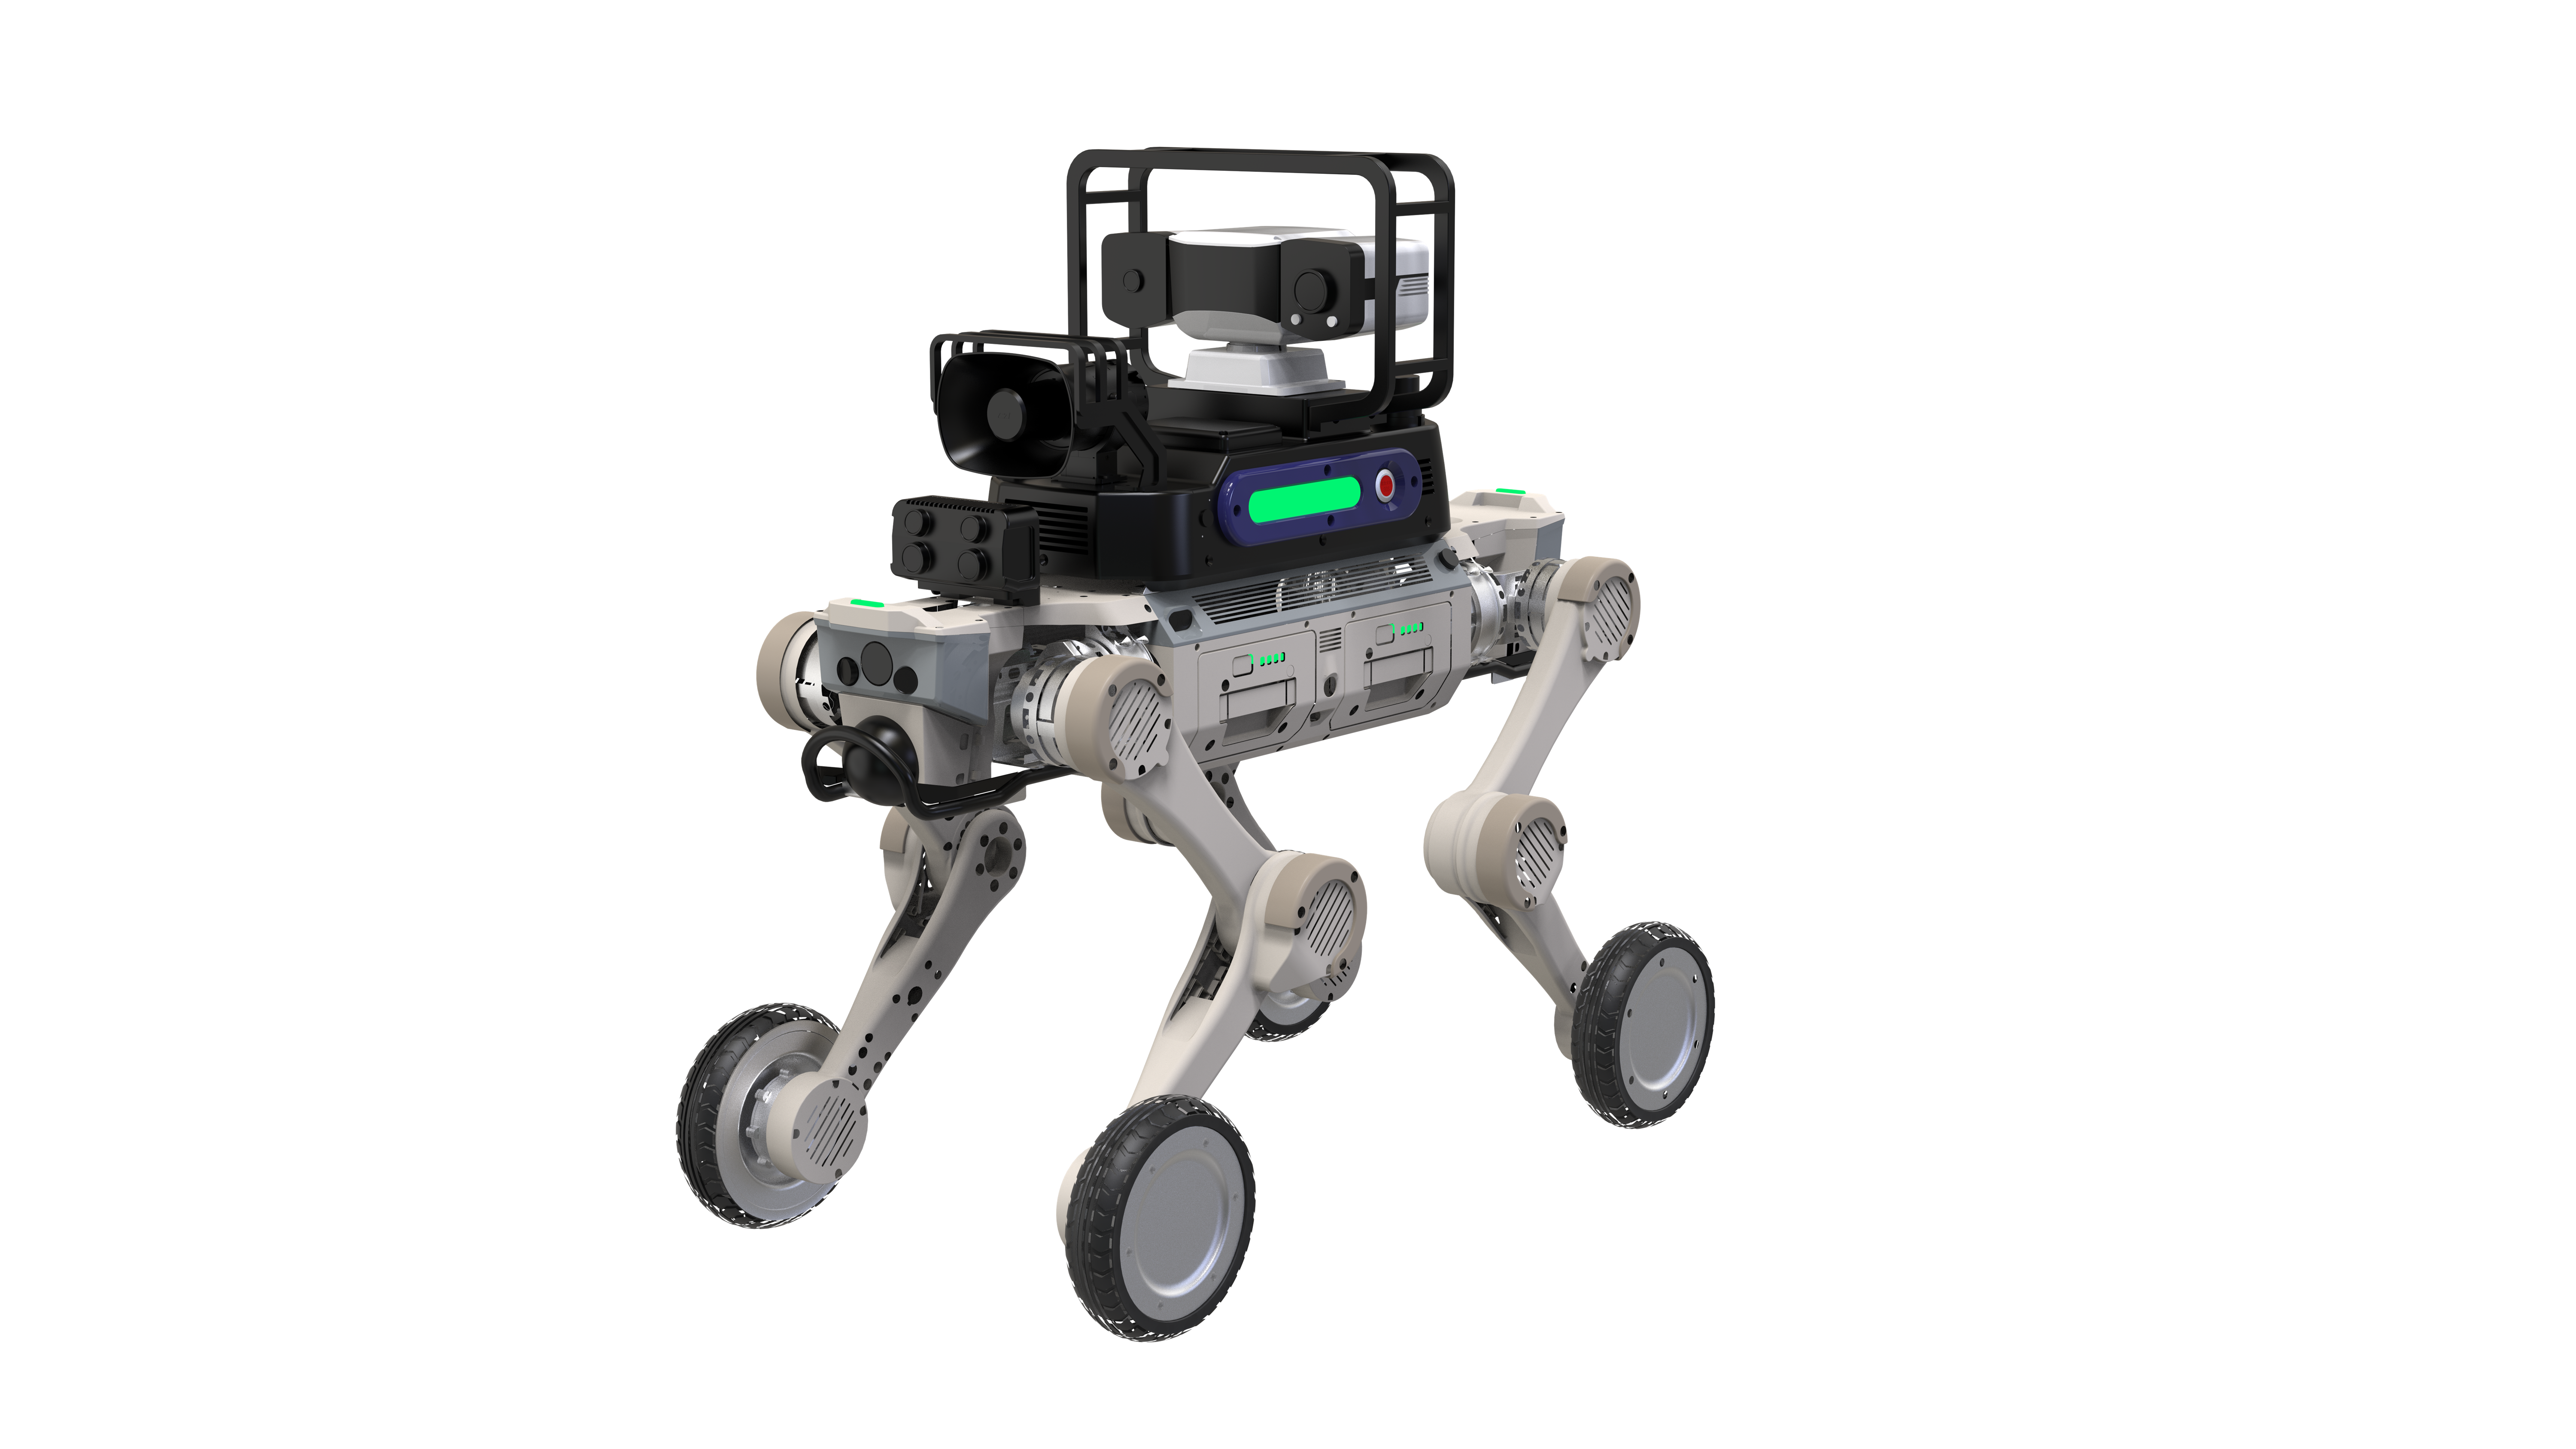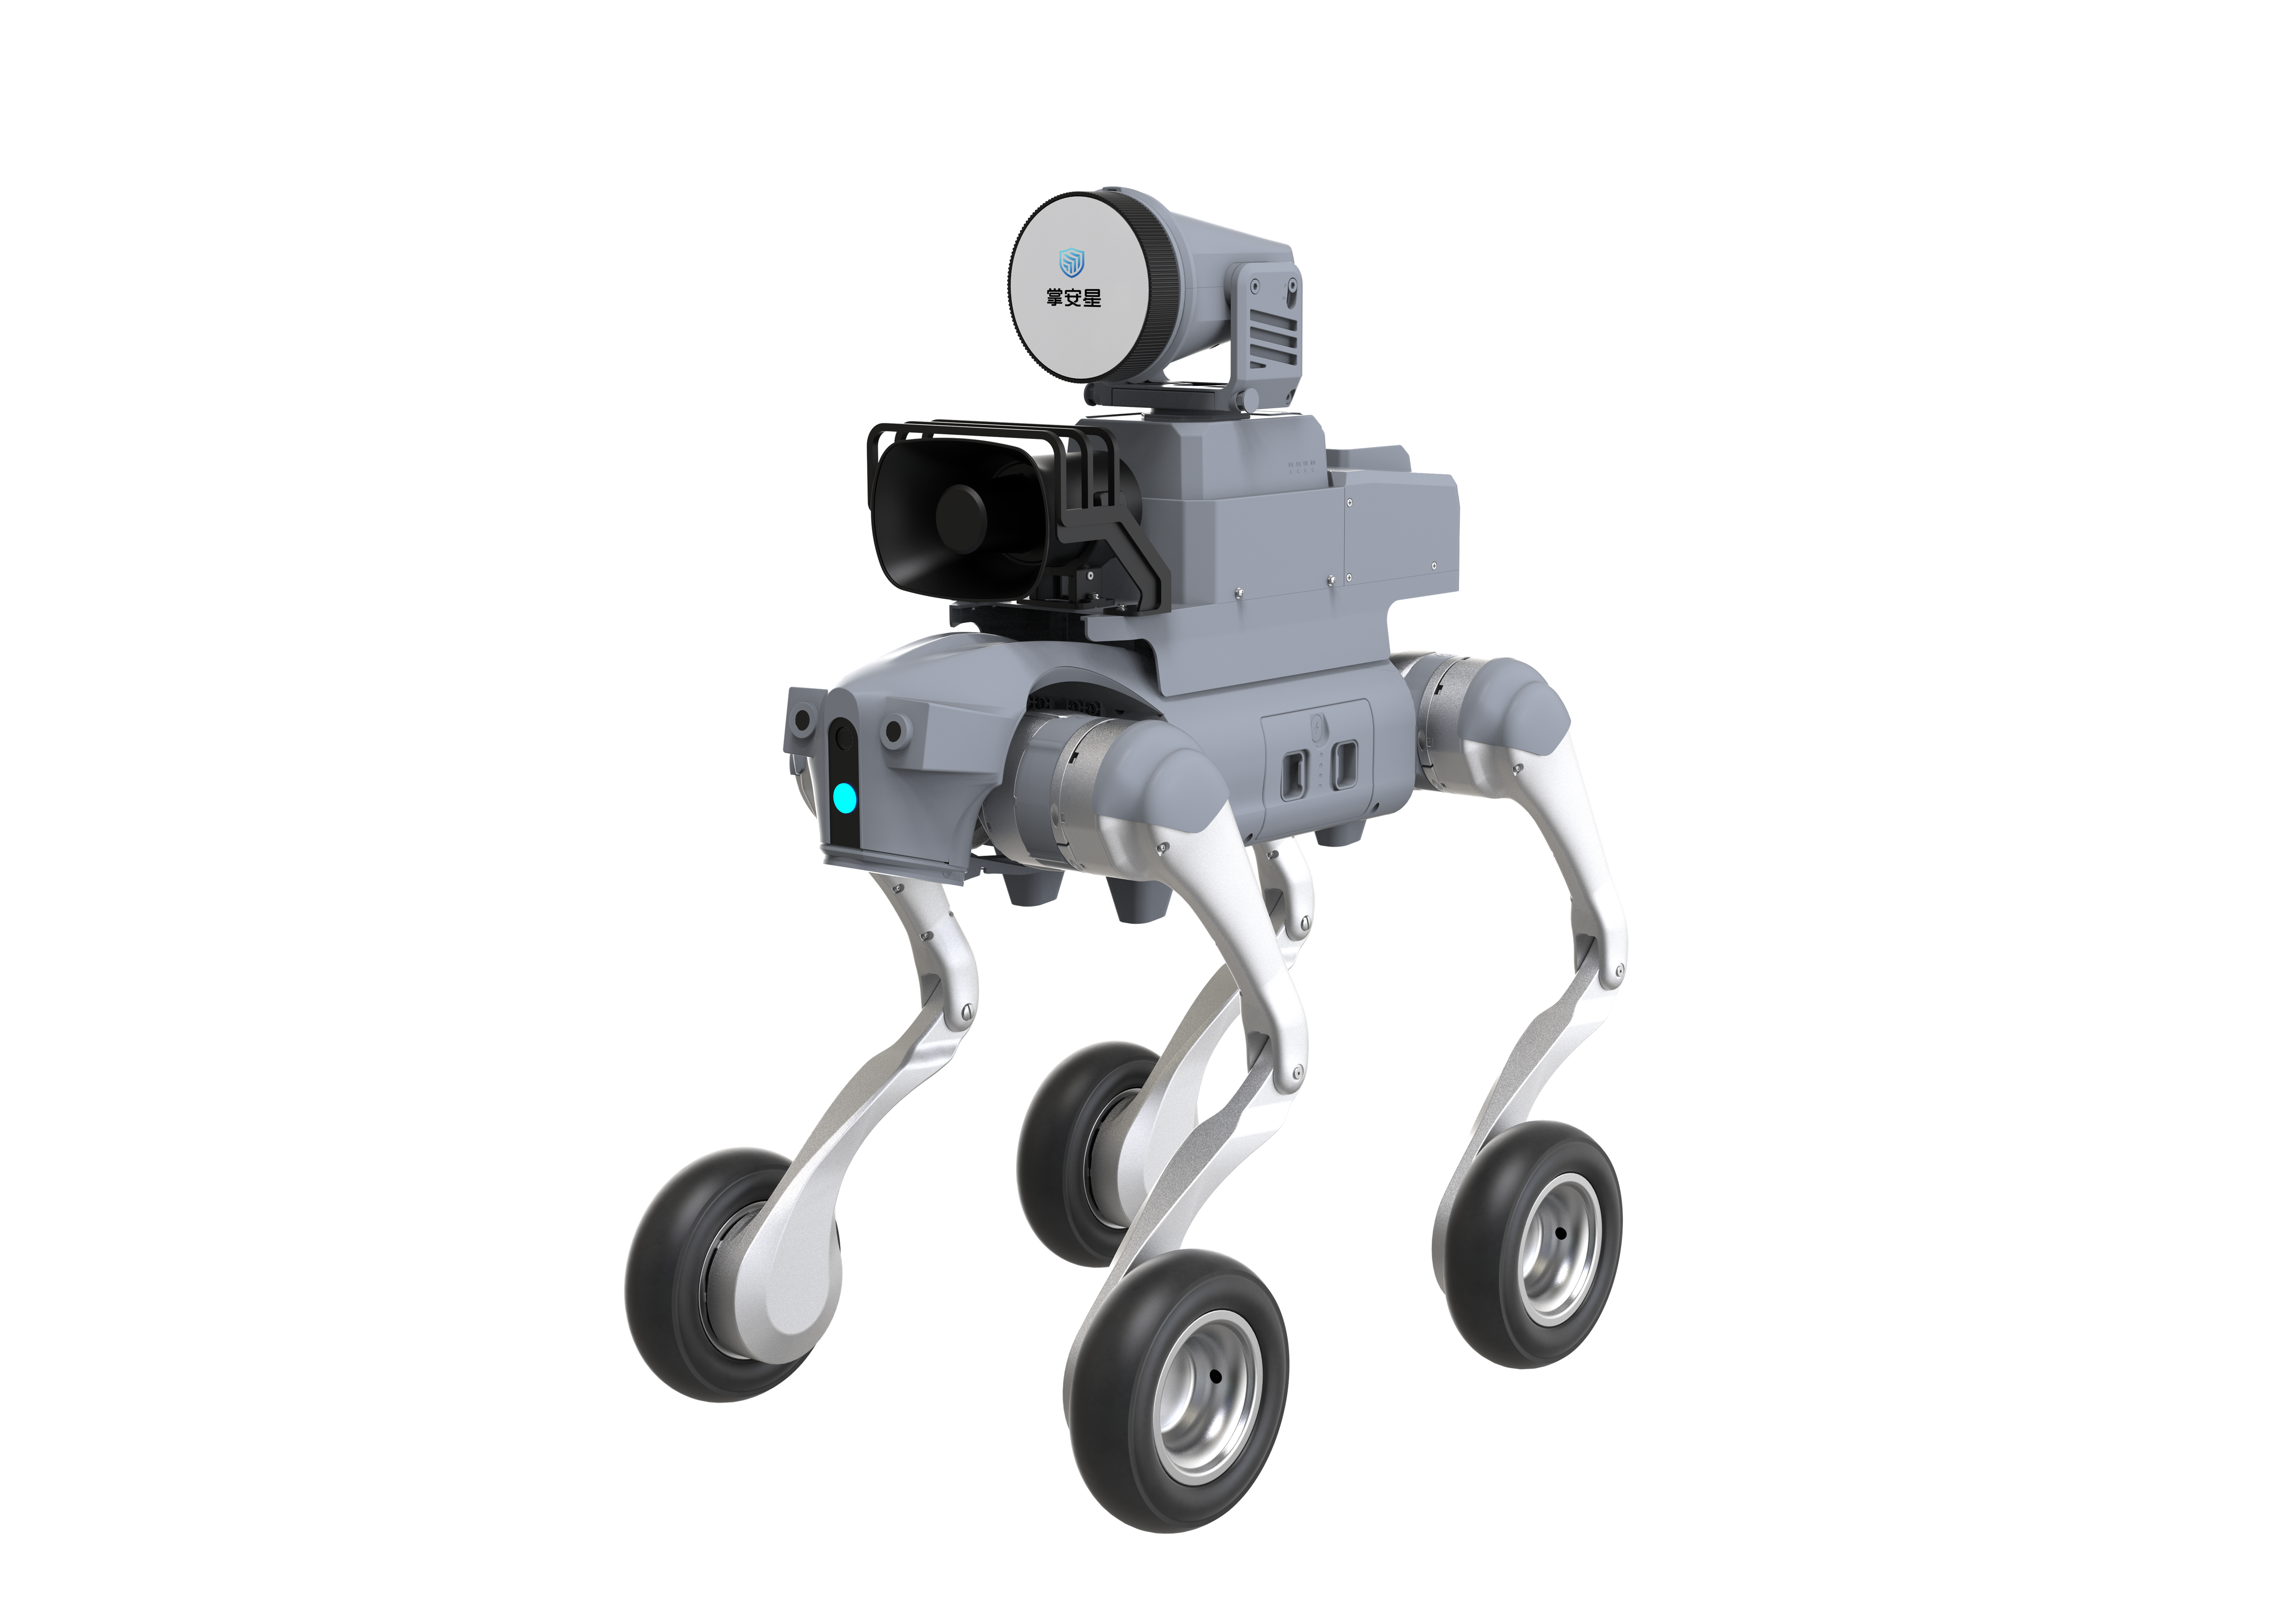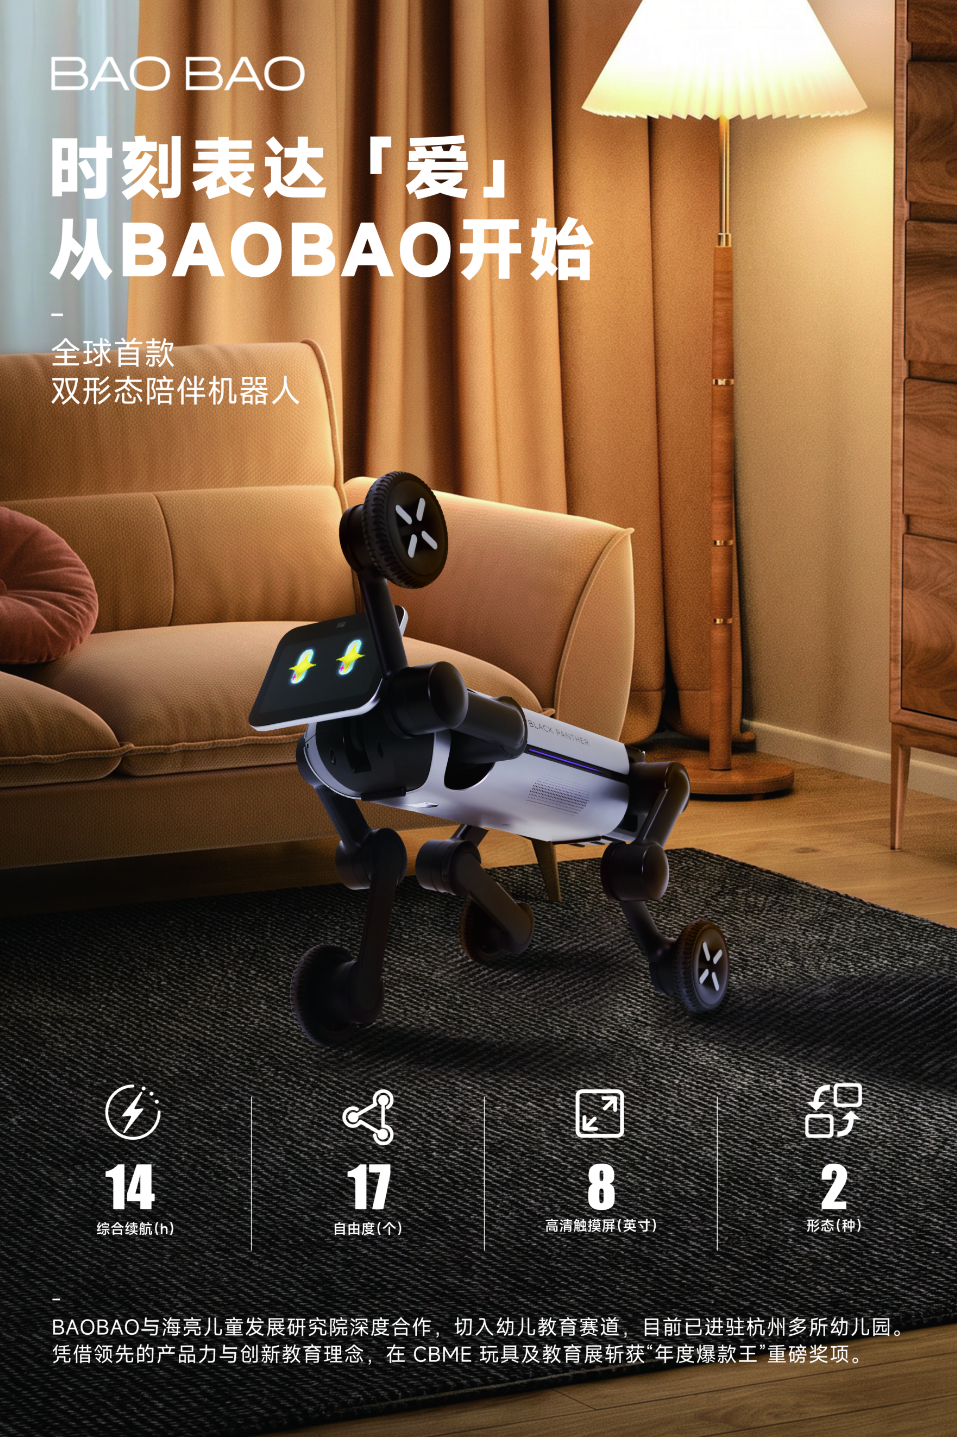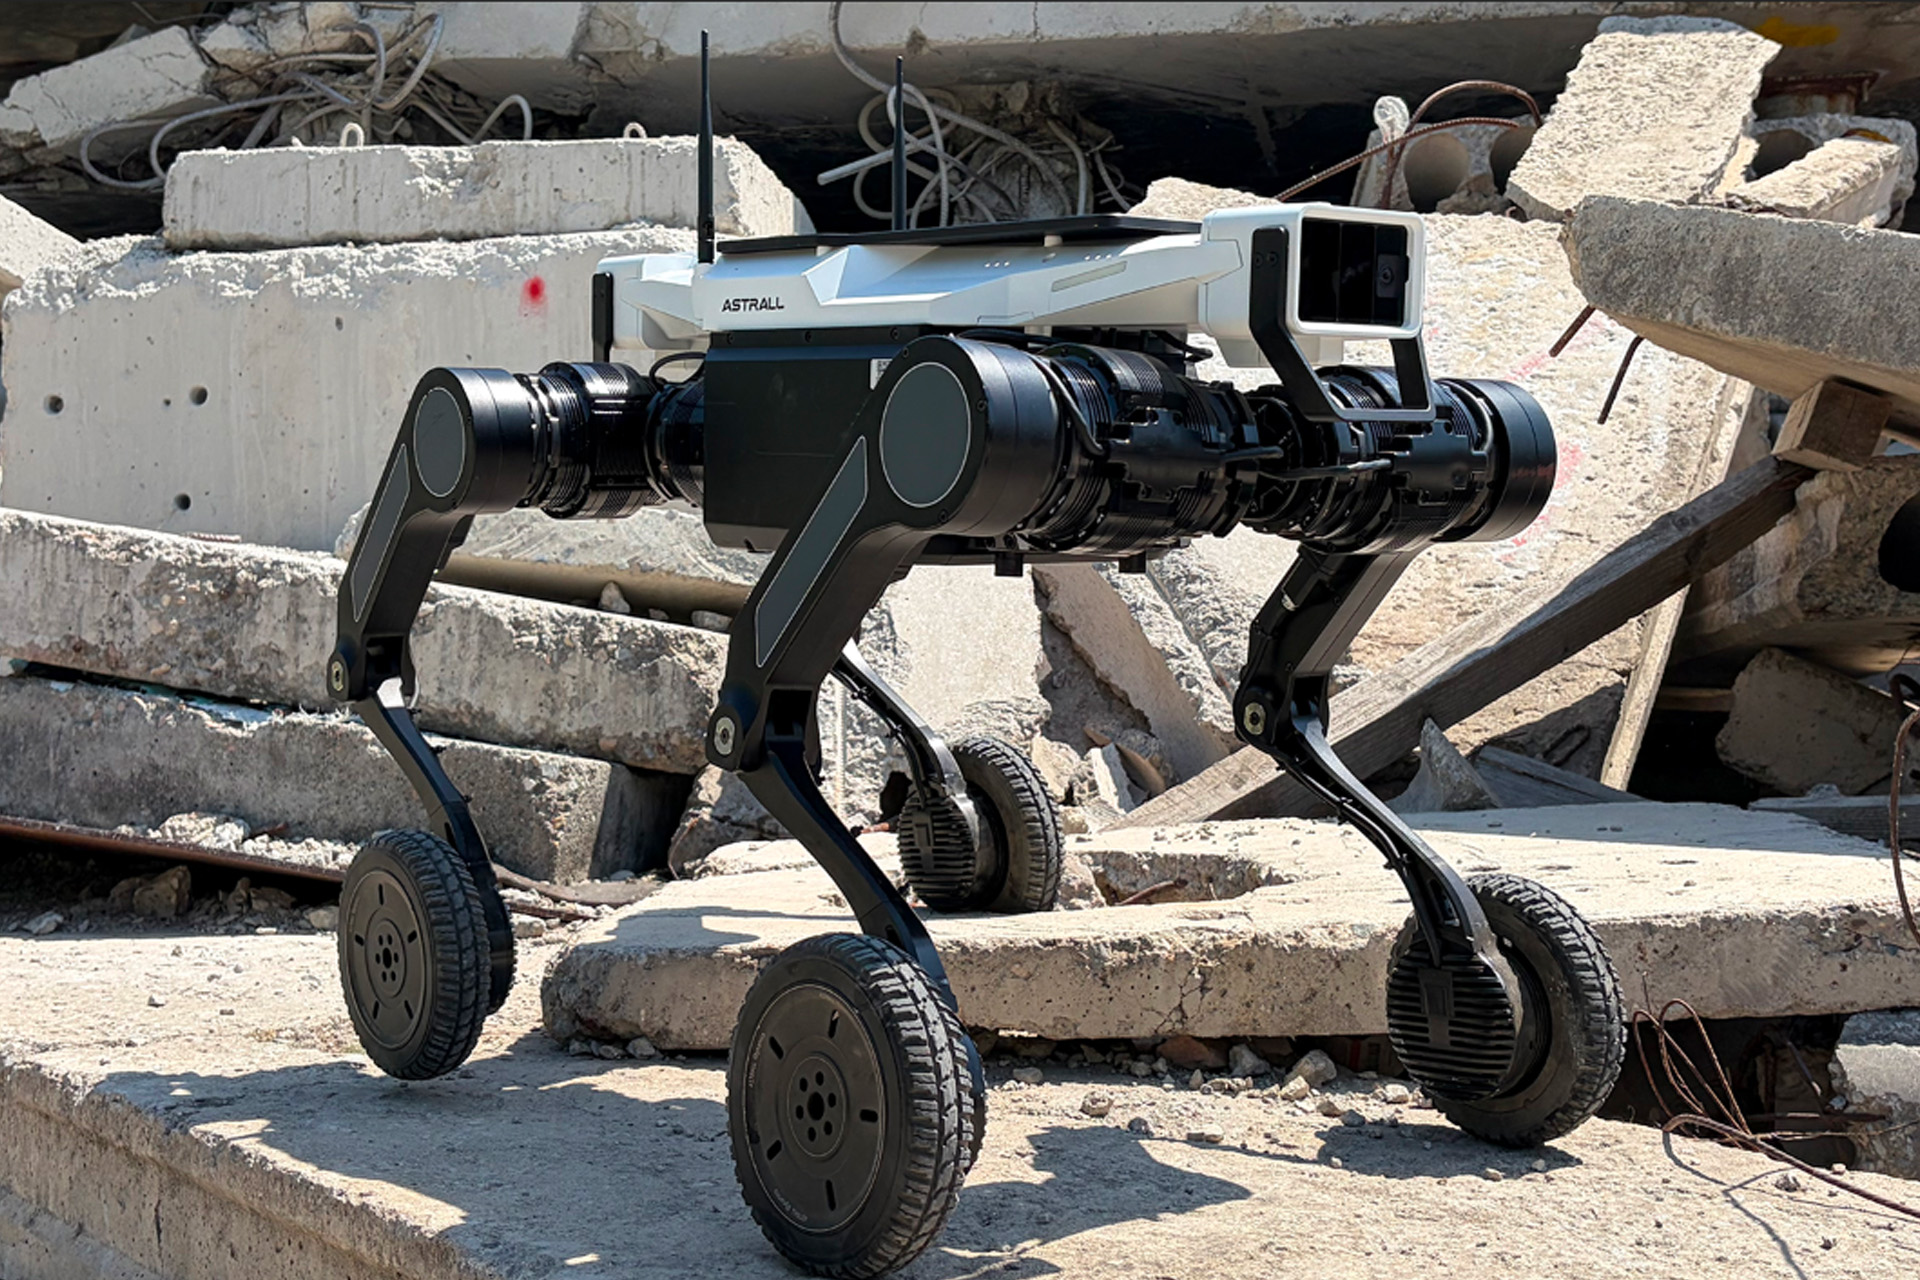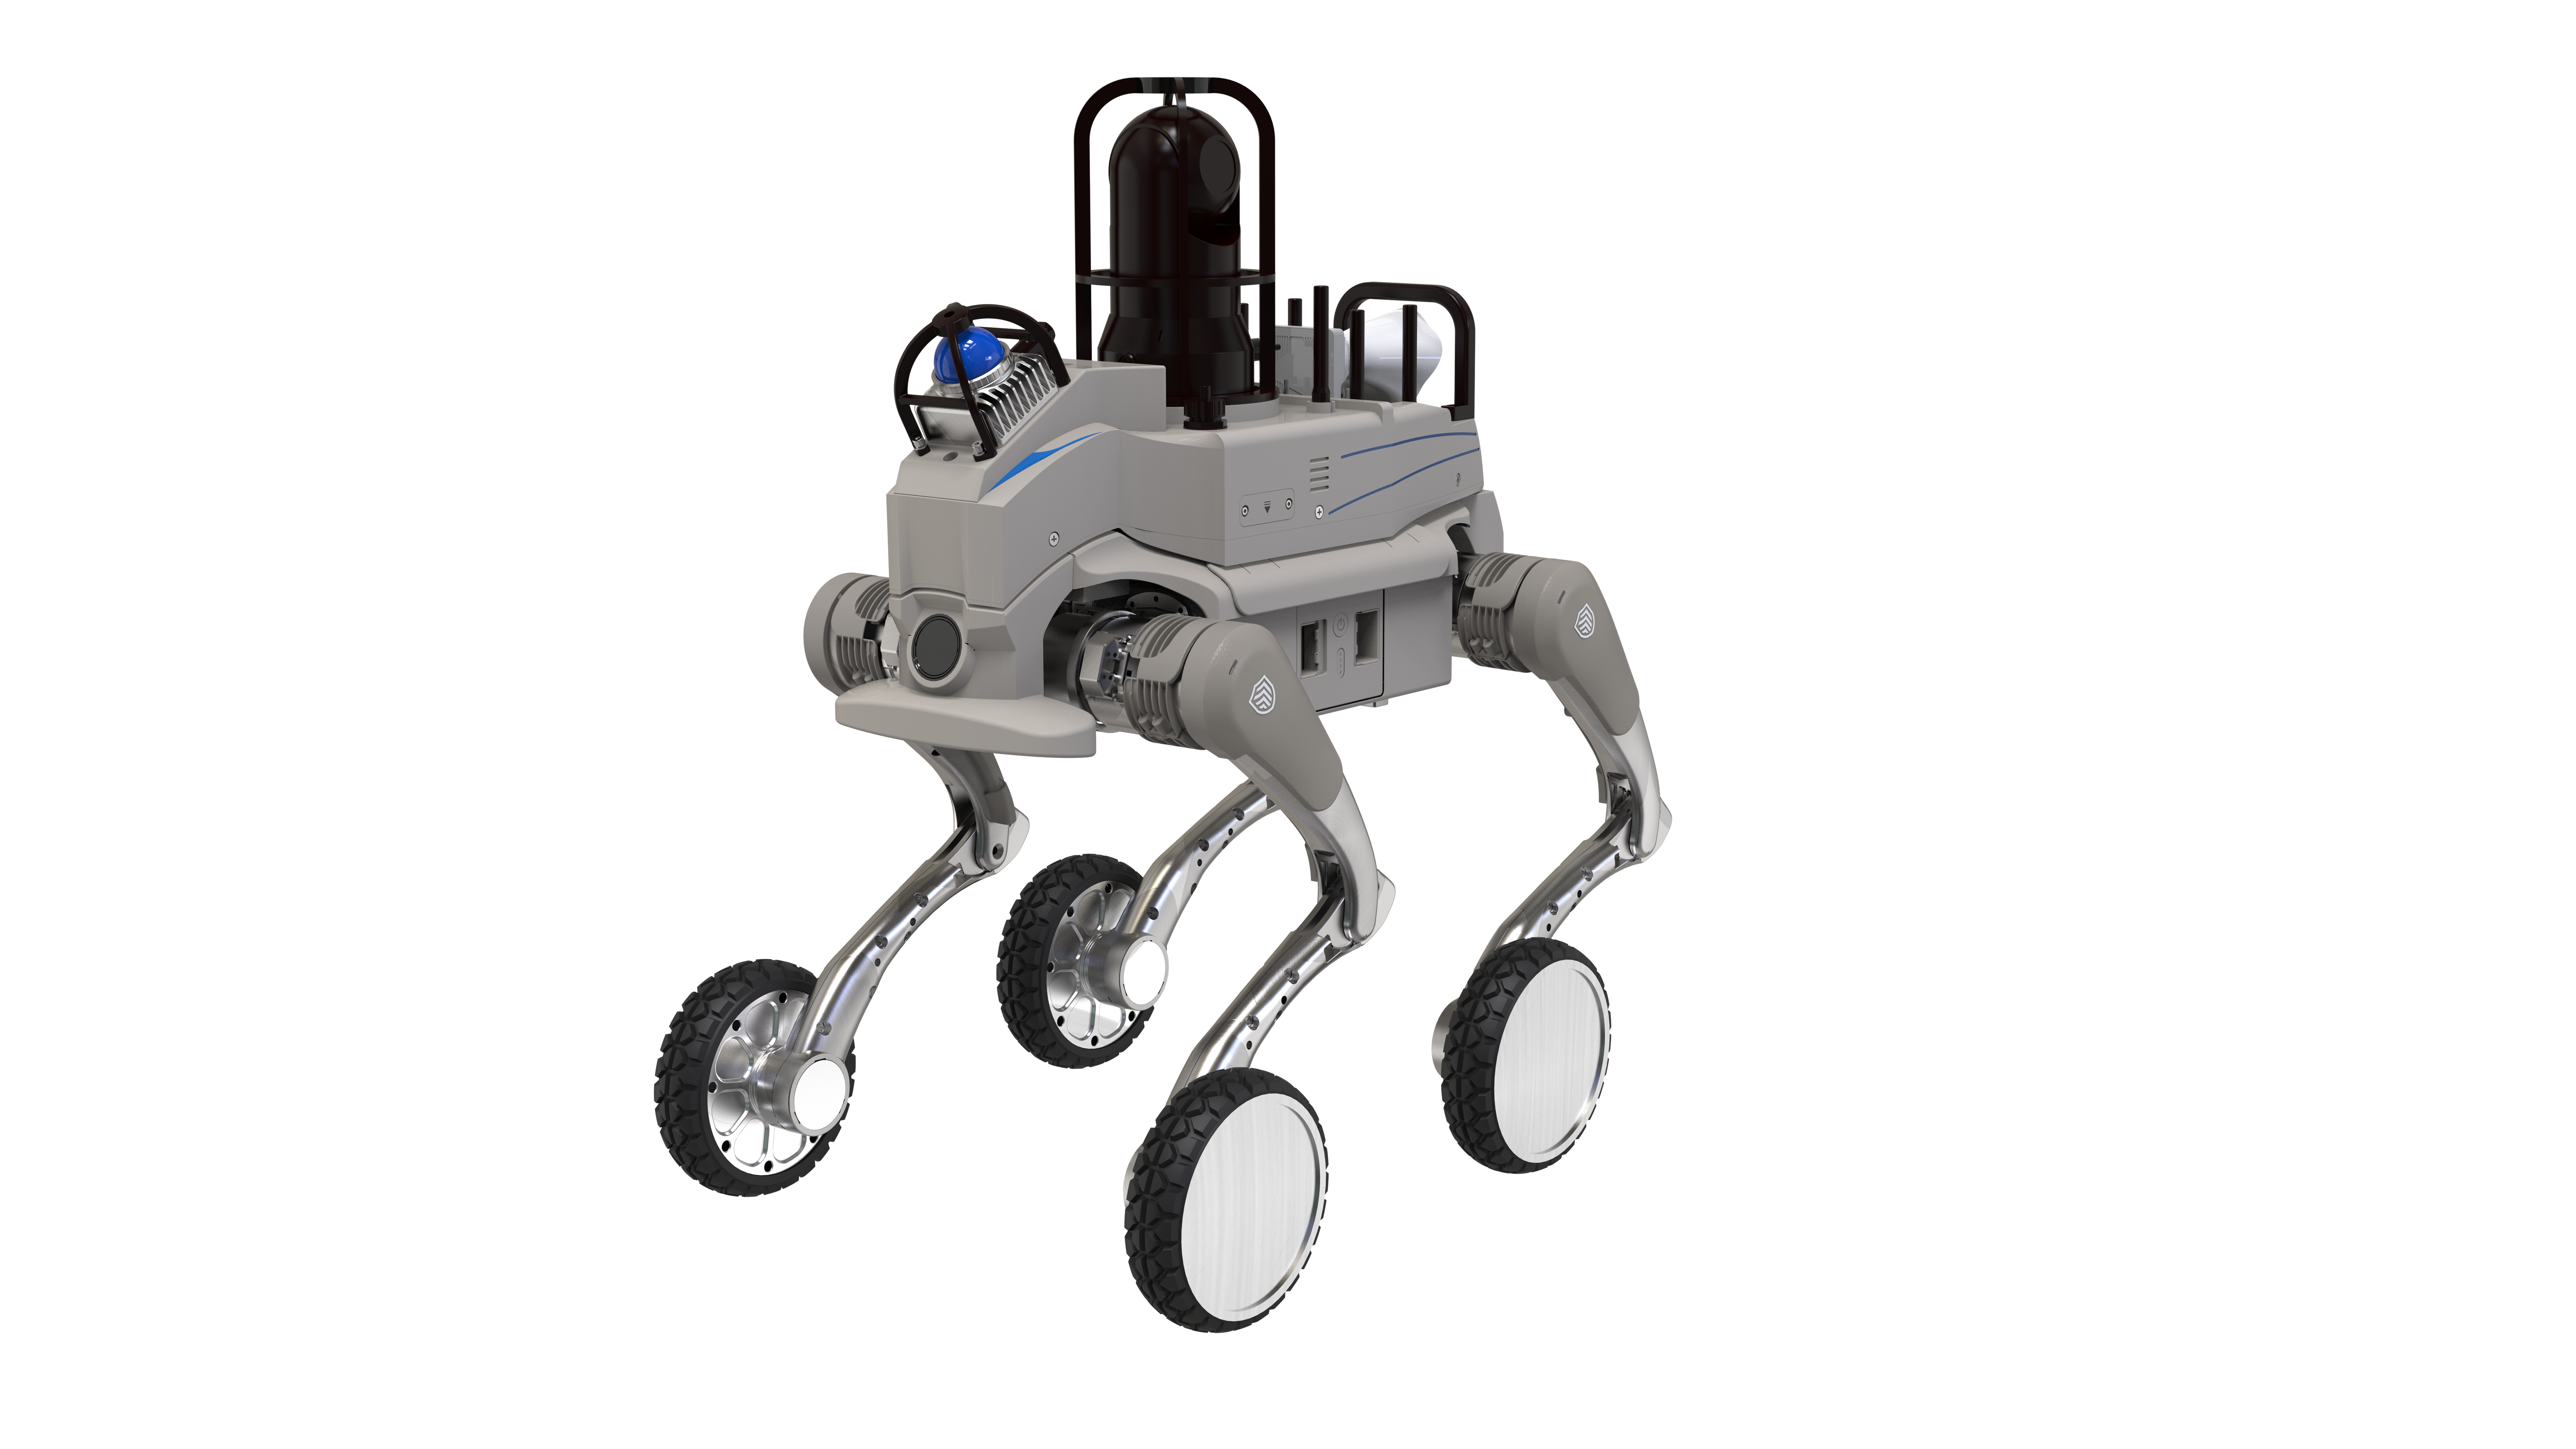
Commercial robotQuadruped
NEXWISE PW2
Official specs 16
Galileo C1 Series, a quadruped robot.
Data & sources
Key specifications
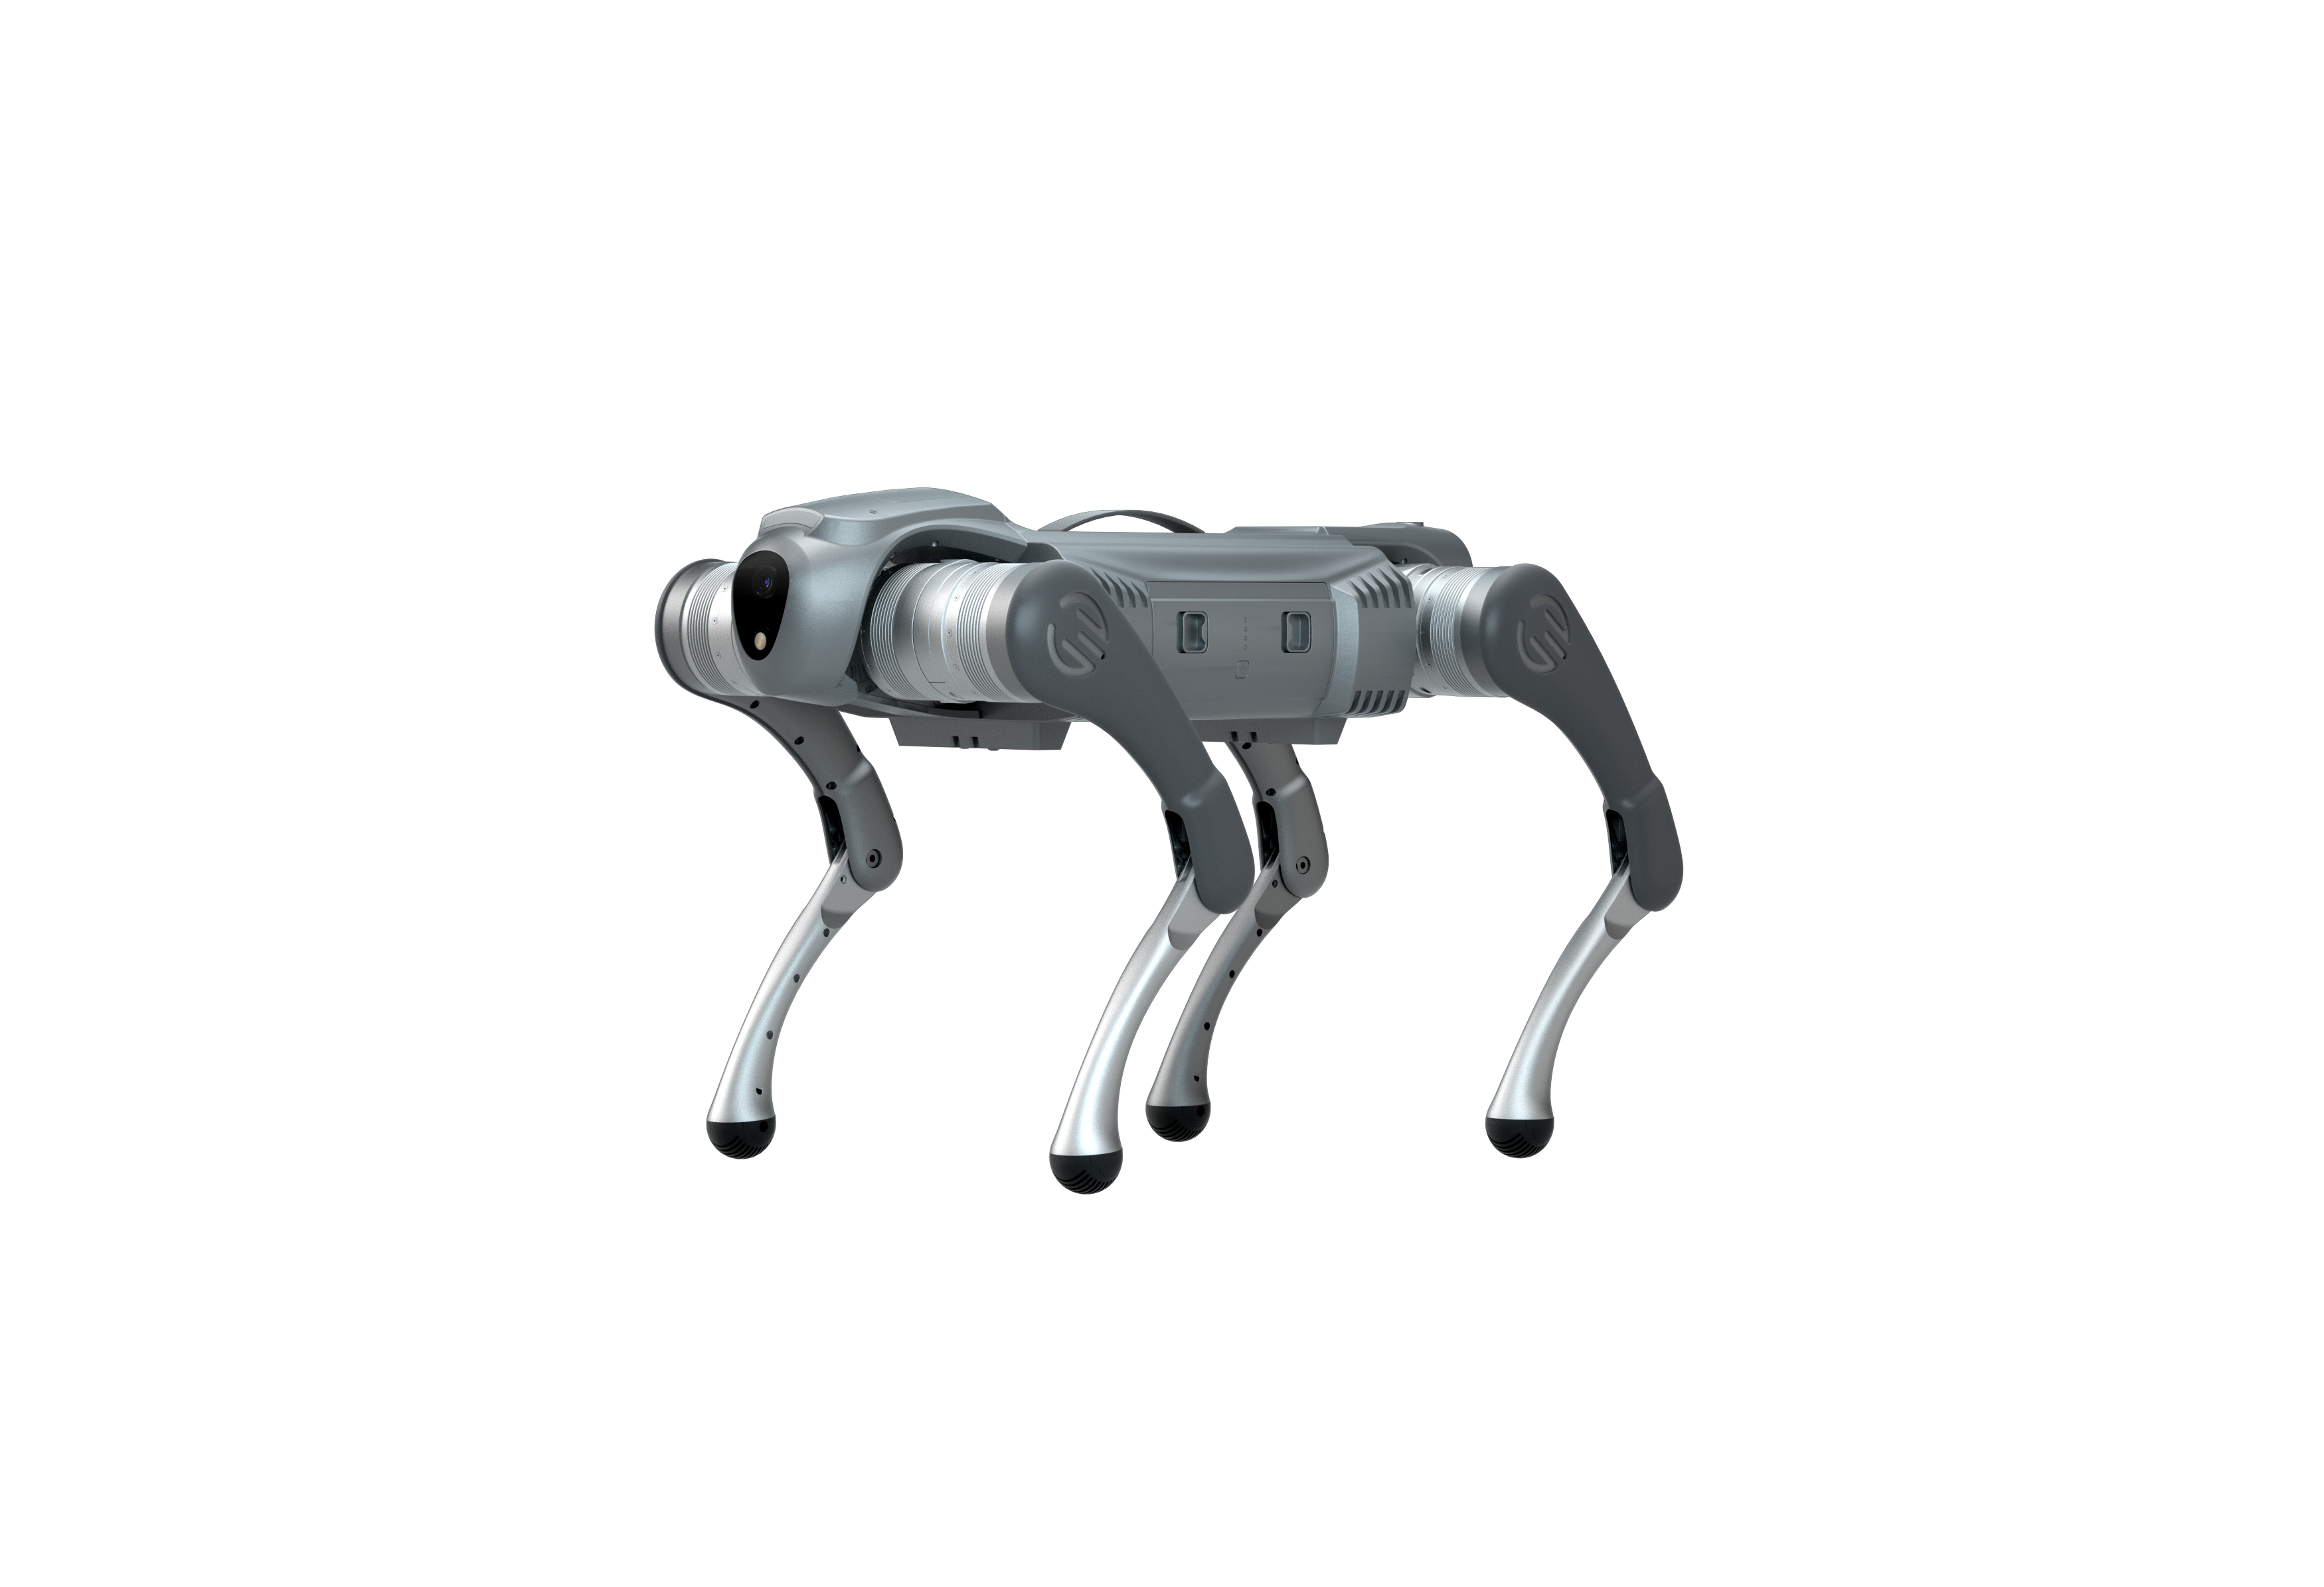
| Locomotion type | quadruped locomotion |
|---|---|
| Motion control | Mature quadruped motion control |
| Movement characteristics | Agile movement; stable gait; strong environmental adaptability |
| Operating terrain | Flat ground; gentle slopes; complex indoor spaces |
| Robot form | Lightweight multifunctional biomimetic robot |
|---|
| Primary use cases | Consumer scenarios; research and education; small industrial equipment inspection |
|---|---|
| Experimental platform | Experimental platform for university laboratories and technology education projects |
| Development and interface support | Secondary development and open-source interfaces |
|---|
| Inspection module payload | Small inspection module |
|---|
| Equipment status monitoring | Equipment operating status monitoring |
|---|
01 · Official source