Commercial robotHumanoid
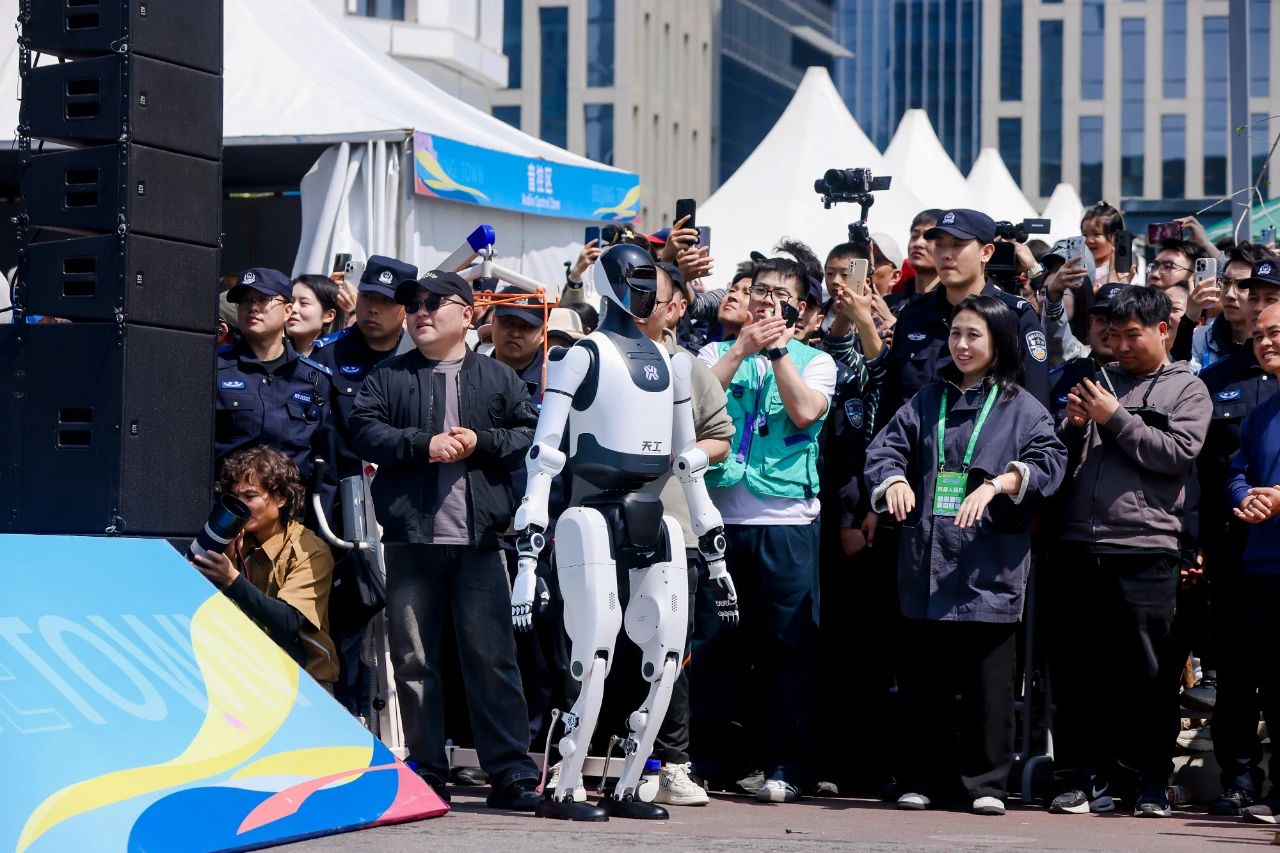
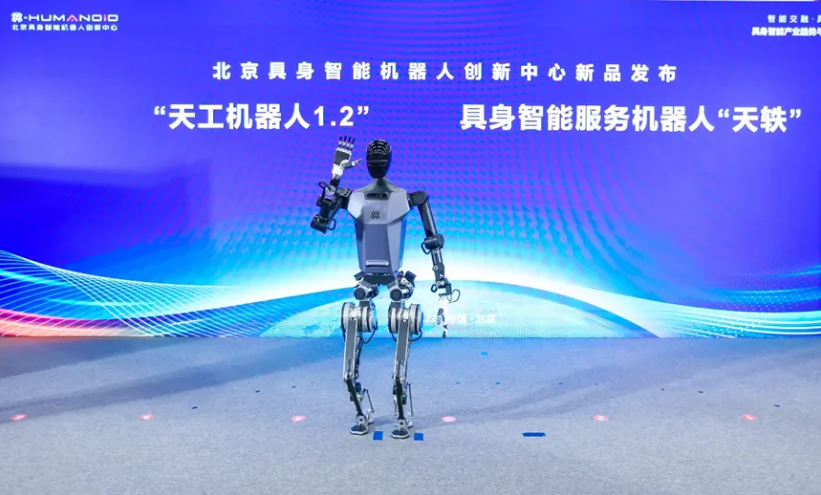
X-Humanoid Tiangong Ultra
Official specs 11
X-Humanoid TianGong platform with 1.0 Lite, 1.1 Pro, and 1.2 Max models.
Data & sources
No specifications are verified across every edition yet.
01 · Official source
02 · Official source
03 · Official source
7 per arm[2] |
| — |
| Battery | 15 Ah / 48 V[1] | 15 Ah / 48 V[2] | — |
|---|
| Charge time | 4 h[1] | 4 h[2] | — |
|---|
| CPU maximum frequency | 4.7 GHz[1] | 4.7 GHz[2] | — |
|---|
| Actuation | |||
|---|---|---|---|
| Degrees of freedom | 20[1] | 42[2] | — |
| Leg degrees of freedom | 6 per leg[1] | 6 per leg[2] | — |
| Shoulder peak torque | — | 140 N·m[2] | — |
| Waist yaw peak torque | — | 143 N·m[2] | — |
| Hip/knee joint torque | — | — | 320 N·m[3] |
| Compute | |||
|---|---|---|---|
| Development compute | — | 275 TOPS per module × 2[2] | — |
| Development computer | — | 2 × NVIDIA Jetson AGX Orin 64GB[2] | — |
| Memory | 16 GB[1] | 16 GB[2] | — |
| Middleware | ROS 1[1] | ROS 1[2] | — |
| Motion computer CPU | Intel x86, 10 cores / 12 threads[1] | Intel x86, 10 cores / 12 threads[2] | — |
| Operating system | Ubuntu 22.04.4 LTS[1] | Ubuntu 22.04.4 LTS[2] | — |
| SSD storage | 256 GB[1] | 256 GB[2] | — |
| Dimensions | |||
|---|---|---|---|
| Frame and shell | Aluminum alloy frame; engineering plastic alloy shell[1] | Aluminum alloy frame; engineering plastic alloy shell[2] | — |
| Height | 1630 mm[1] | 1630 mm[2] | 173 cm[3] |
| Weight | 43 kg[1] | 56 kg[2] | 60 kg[3] |
| Other | |||
|---|---|---|---|
| External connectivity | Wi-Fi 6, Ethernet, Bluetooth[1] | Wi-Fi 6, Ethernet, Bluetooth[2] | — |
| Internal bus update rate | CAN/EtherCAT, 1 kHz[1] | CAN/EtherCAT, 500–1,000 Hz[2] | — |
| Power | |||
|---|---|---|---|
| Standing runtime | 4 h[1] | — | — |
| Walking runtime | 2 h[1] | — | — |
| Sensors | |||
|---|---|---|---|
| Force sensing | — | Six-axis force sensing[2] | — |
| IMU update rate | ≥400 Hz[1] | >400 Hz[2] | — |
| Microphones | — | 4 linear-array microphones[2] | — |
| RGB D cameras | 2[1] | 4[2] | — |
| RGB D frame rate | 30 Hz[1] | 30 Hz[2] | — |
| Sensors | 2 RGBD cameras; high-precision IMU[1] | 4 RGBD cameras; IMU; 6-axis force[2] | — |
| Speakers | — | 2[2] | — |
| Details | Official specs → | Official specs → | Official specs → |
|---|
— Not published