Commercial robotHumanoid
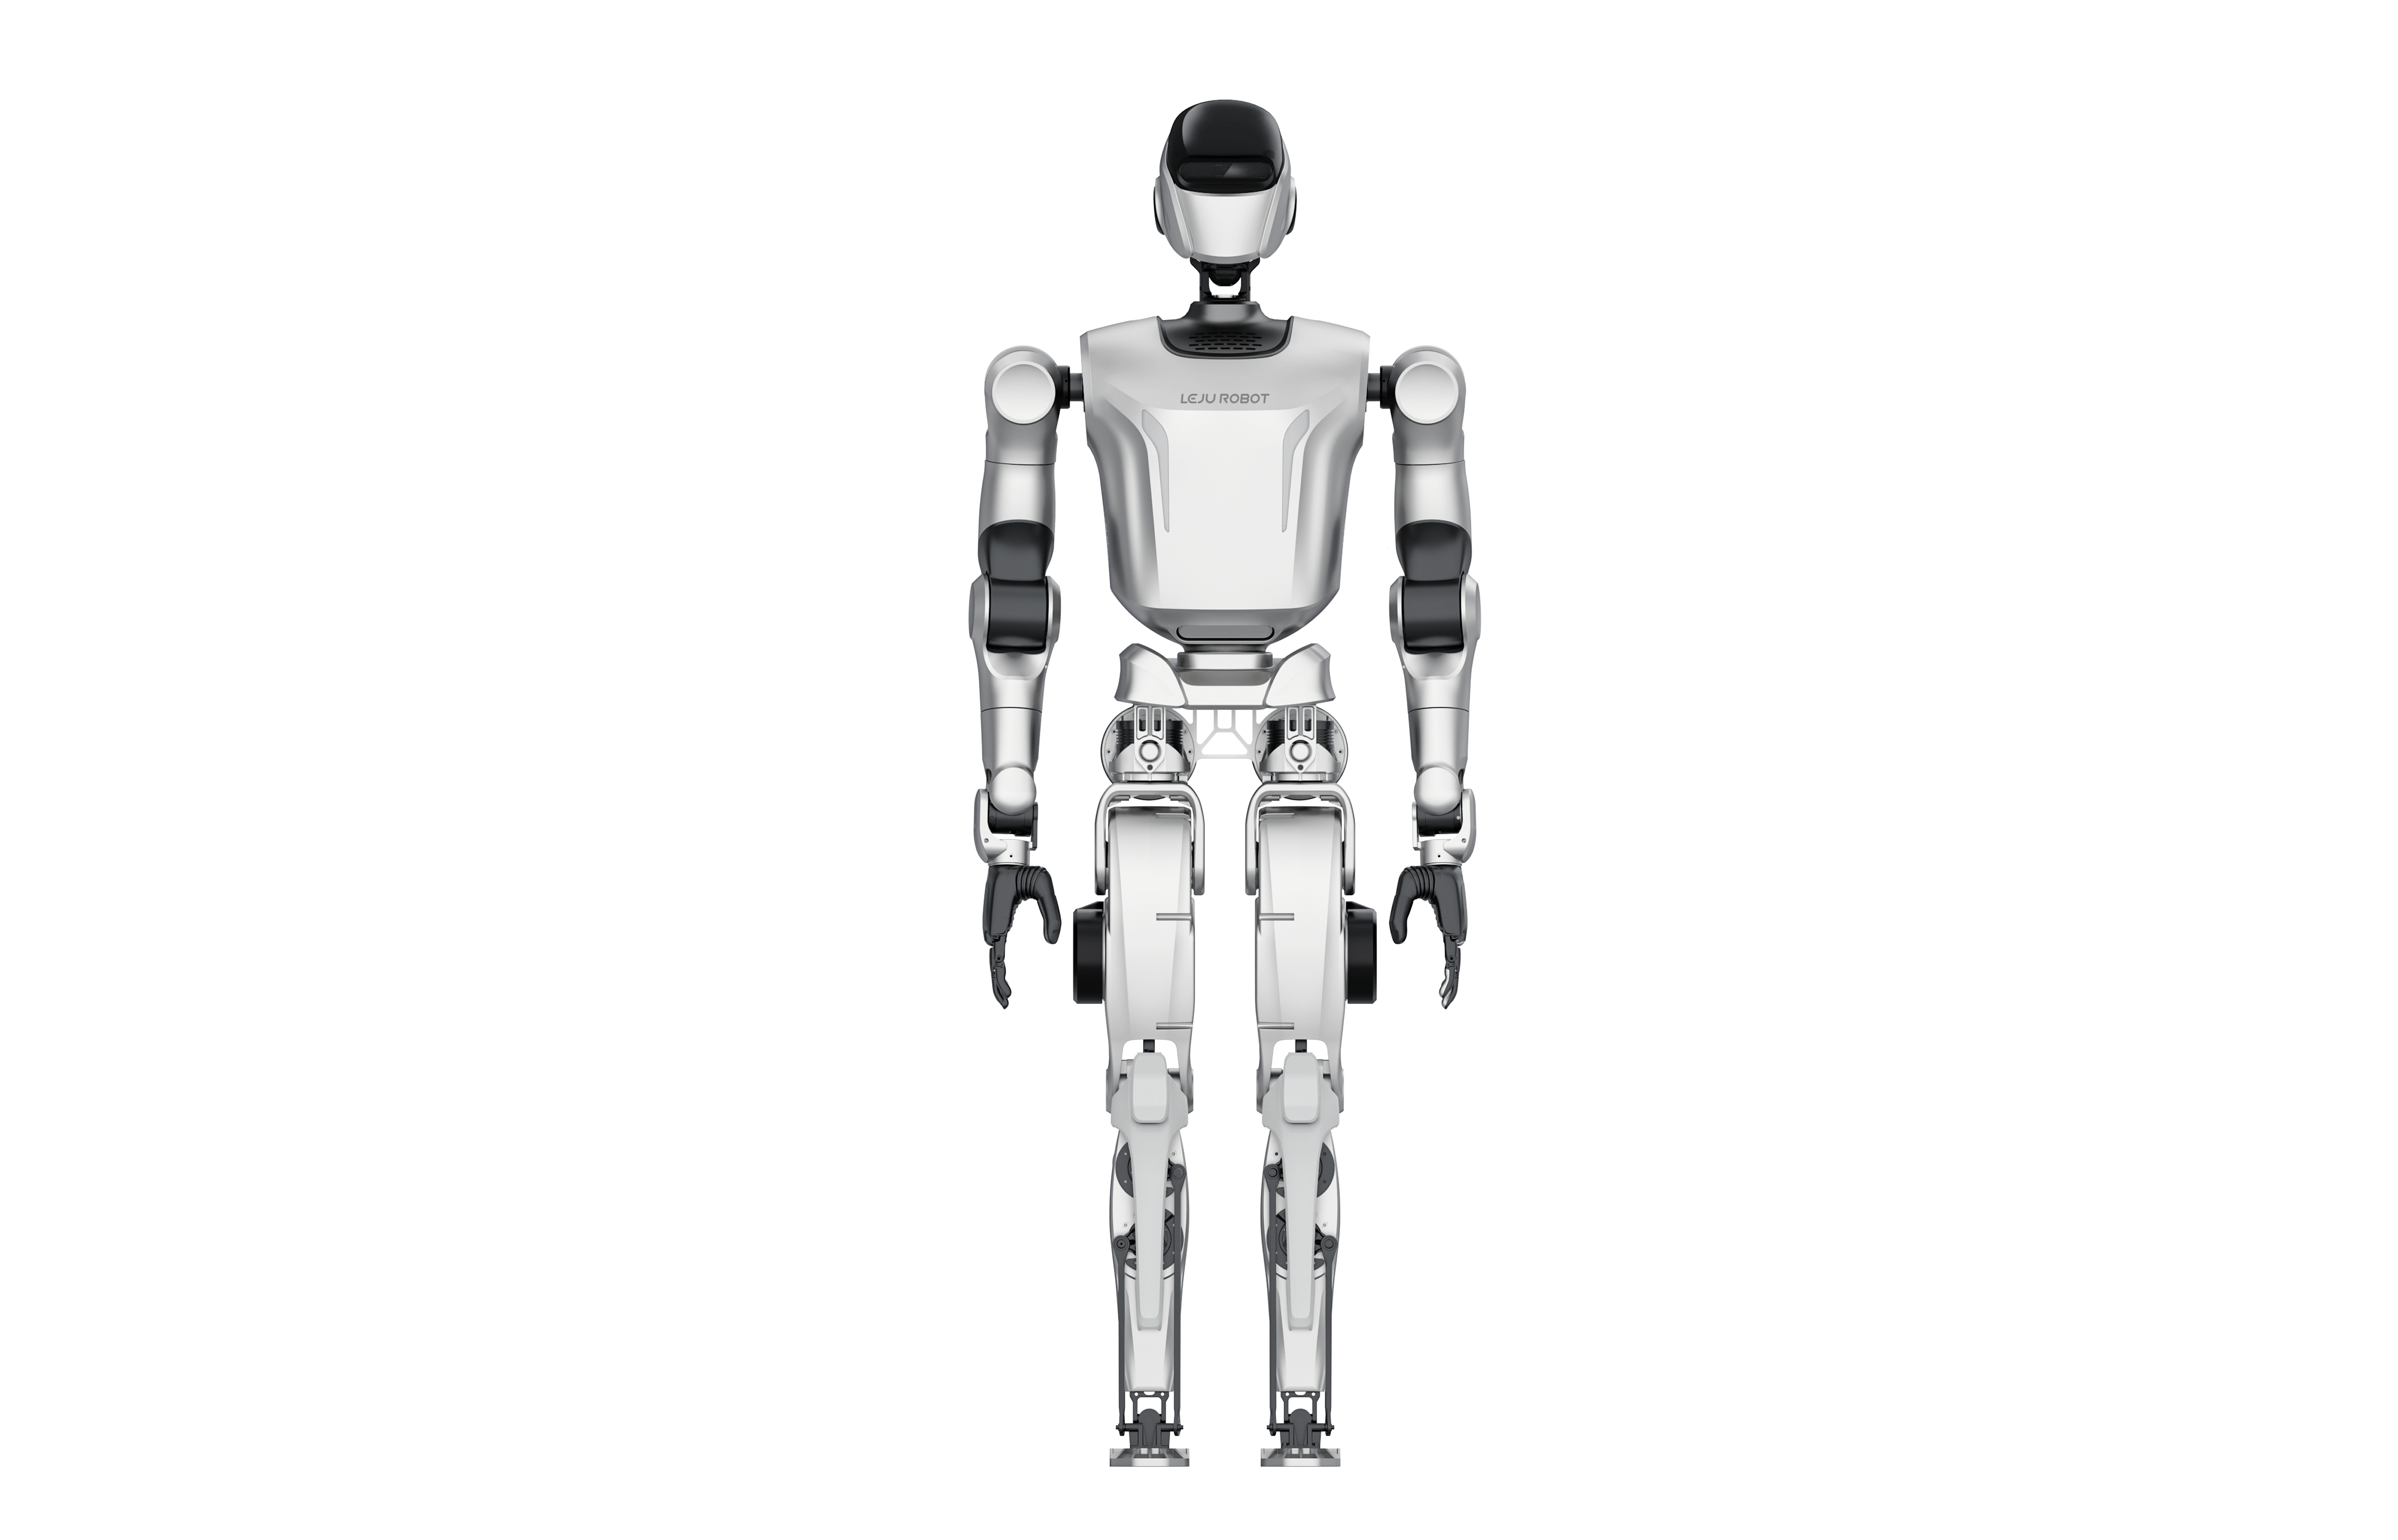
Leju Kuavo 5
Official specs 15
development_status: Under Development · Development status: Under development
Data & sources
Key specifications

| Height | 1.615 m |
|---|---|
| Weight | approximately 120 kg |
| Cart width | 0.59 m |
| Dual arm axes | 7 axes for dual arms |
|---|---|
| Waist axes | 3 axes |
| Neck axes | 3 axes |
| Waist degrees of freedom | 3 axes: pitch, pitch, yaw |
| Neck dof | 3 axes: yaw, pitch, roll |
| Power source | built-in battery; continuous operation while charging is also possible |
|---|---|
| Runtime | up to approximately 3 h |
| Single-arm payload | 7 kg in worst-case posture |
|---|
| Undercarriage axes | 4 axes for omnidirectional undercarriage 4-axis undercarriage (omnidirectional mobile base) |
|---|
| Optional head sensor set | wide-angle stereo camera; fisheye camera; depth camera; stereo microphone |
|---|---|
| Torque sensors | torque sensors at all arm and waist joints |
| Head sensor set | ToF-based depth camera, a fisheye camera, a wide-angle stereo camera, and microphones |
| Wide angle stereo camera count | 1 wide-angle stereo camera |
| Fisheye camera count | 1 fisheye camera |
| Depth camera count | 1 depth camera |
| Stereo microphone count | 1 stereo microphone |
| Speaker count | speaker |
|---|---|
| Tool flange terminals | 24 V DC power supply terminal x 1; general-purpose signal wire x 8 |
| Digital input ports | 8 digital inputs ports |
| Digital output ports | 8 digital outputs ports |
| Analog input ports | 8 analog inputs ports |
| Analog output ports | 8 analog outputs ports |
| Ethernet ports | 2 Ethernet ports |
| Ros compatibility | ROS-compatible |
|---|---|
| Gazebo support | Gazebo support |
| Moveit support | MoveIt! support |
| Onboard pc | standard onboard PC |
| Optional nvidia rtx 4070 pc | optional second NVIDIA RTX 4070 PC |
| Mujoco simulation model | model can be tested in MuJoCo made by Google DeepMind MuJoCo simulation model |
| Isaac sim simulation model | model can be tested in Isaac Sim made by NVIDIA Isaac Sim simulation model |
| Optional image processing pc | NVIDIA RTX 5070 for machine-learning training and inference |
| Force controllable motion software | force-controllable humanoid motion functions |
| Control and safety software | Cartesian impedance control; ZMP fall prevention; movement state machine; interference-detection safety stop |
| Ros software base | ROS-based software |
| Ros software tools | RViz visualization; MoveIt! planning; sensor-information logging |
01 · Official source