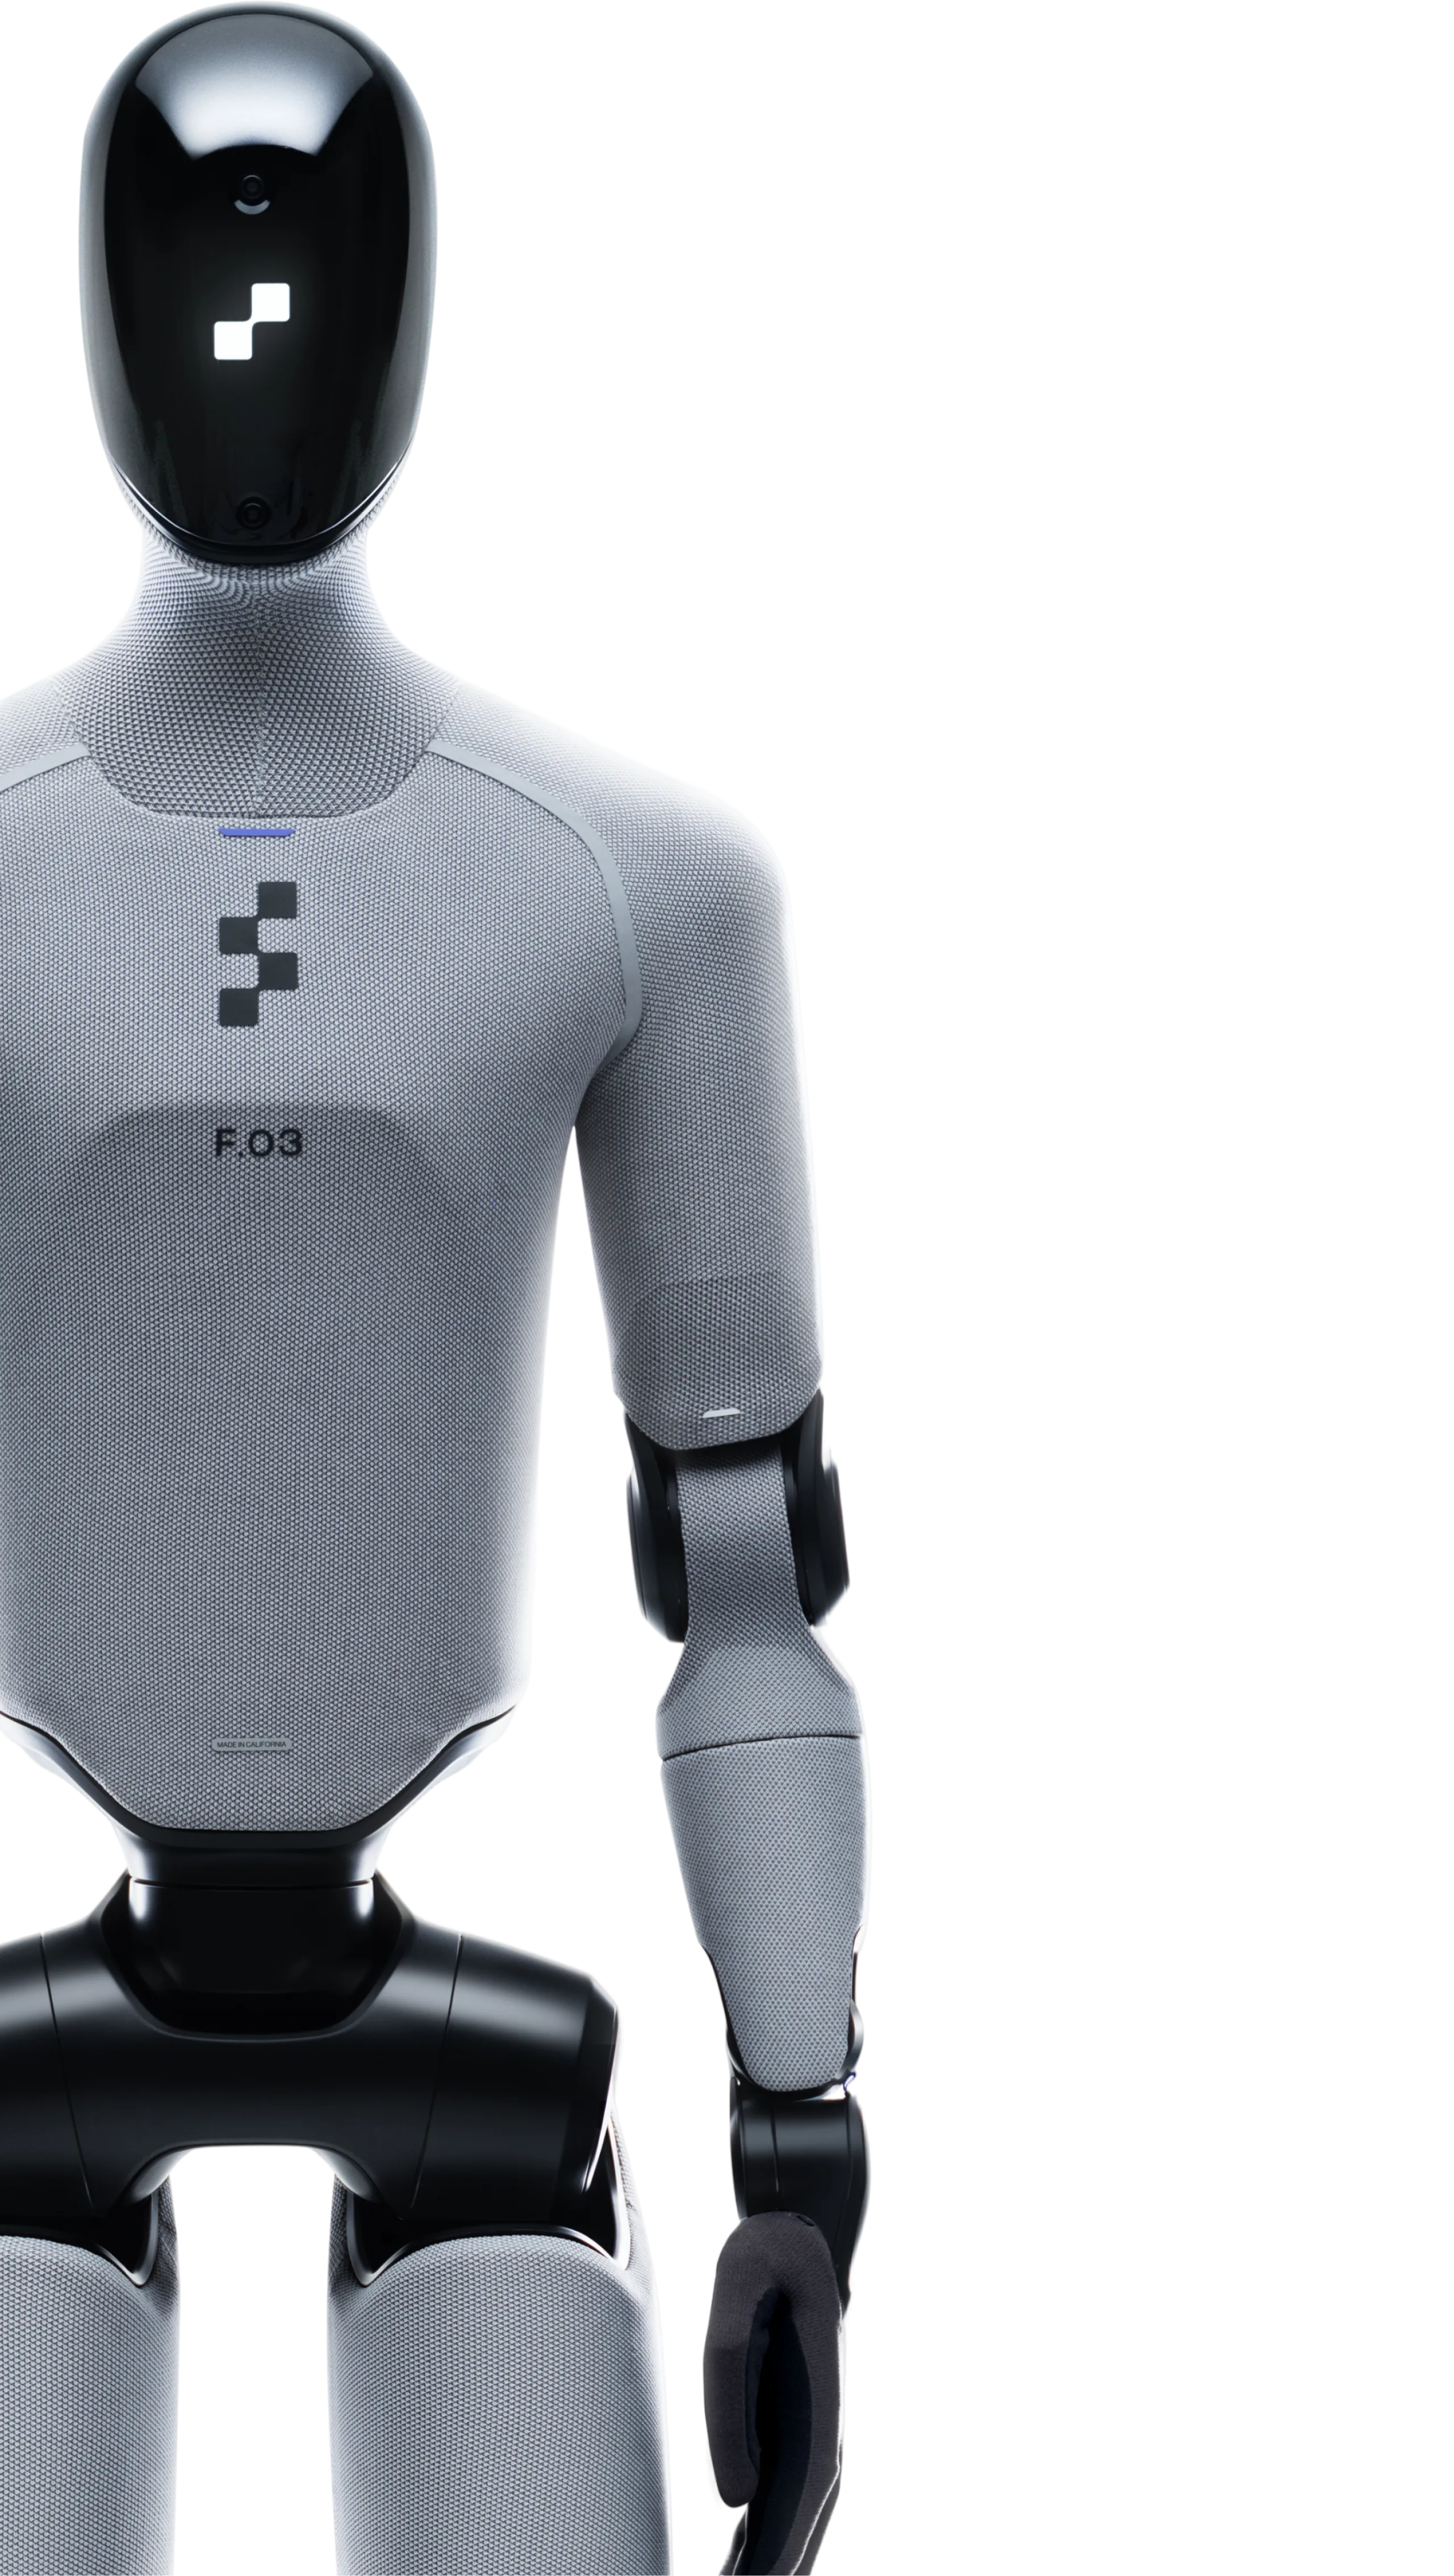
Commercial robotHumanoid
Hexagon AB AEON
Official specs 7
product_category: Humanoid Robot · Robot class: AI humanoid robot
Data & sources
Key specifications

| Height | 0.015 m |
|---|---|
| Weight | 56 kg |
| Standing dimensions | 1.54 × 0.44 × 0.3 m |
| Total degrees of freedom | 53 DoF (Legs 6 DoF ×2, Arms 7 DoF ×2, Waist 3 DoF, Neck 2 DoF, Hands 11 DoF ×2) |
|---|---|
| Hand dof per hand | 6 DoF × 2 hands DoF per hand 6 DoF × 2 DoF per hand 6 DoF ×2 DOF per hand |
| Arm dof per arm | 7 DoF × 2 arms DoF per arm 7 DoF × 2 DoF per arm |
| Neck dof | 2 DoF |
| Waist degrees of freedom | 3 DoF |
| Leg dof per leg | 6 DoF × 2 legs DoF per leg 6 DoF ×2 DoF per leg |
| Hand dof total | 11 DoF (6 Active DoF + 5 Passive DoF) |
| Maximum joint torque | 150 Nm |
| Hand dof | 6 DoF Grasping |
| Thumb dof | 2-DoF thumb |
| Coupled fingers dof | 1-DoF coupled fingers |
| Hand mechanism | Tendon-Driven Mechanism |
| Hand internal design | Lightweight and space-optimized internal design |
| Degrees of freedom per arm | 7 DoF ×2 |
| Degrees of freedom per leg | 6 DoF ×2 |
| Battery capacity | 17,000 mAh 48 V |
|---|---|
| Battery voltage | 48 V |
| Recharge method | Direct charge |
| Charging time | 2.5 h |
| Included remote control app | Remote Control App |
|---|---|
| Software update status | Continuously Updated |
| Included data platform | Data Platform |
| Computing system | Intel Core i7 |
| Operating system | Linux |
| Middleware | Cyclone DDS |
| Apis | C++ & Python APIs |
| Learning capabilities | Reinforcement & Imitation Learning |
| Imitation data collection | collecting imitation learning data |
| Data platform capabilities | episode inspection and data labeling |
| Ai training datasets | essential datasets required for advanced AI training |
| Software stack | Linux, Cyclone DDS, C++/Python APIs |
| Customizable robotic hands | customizable robotic hands |
|---|---|
| Finger count | 5 |
| Dual-arm payload | 6 kg (using both arms) |
| Custom robotic hands | Custom robotic hands |
| Custom end effectors | Diverse end-effectors tailored to specific physical demands |
| Hand structure | 5-Finger Humanoid Structure |
| Adaptive grasping | Adaptive Grasping Mechanism |
| Connectivity | Wi-Fi (AP), BLE Wi-Fi AP/BLE |
|---|---|
| Control interfaces | App, Physical buttons |
| Feedback interface | Head LED |
| Compliance class | Industrial Standard Class A |
| Included teleoperation device | Master Arm |
| Included remote control app | Remote Control App |
| Head status indicator | Head Indicator (LED) |
| Teleoperation device | teleoperation device |
| Motion mapping | maps human arm movements to the robot |
| Remote monitoring | real-time monitoring of the robot's status |
| Joystick control | Intuitive joystick controls |
| Preset functions | preset functions |
| Force limiting | Force limiting |
| Collision detection | Collision detection |
| Emergency stop | Emergency stop |
| Collaborative mode | Collaborative mode |
| Vision system | RGB Stereo, Depth Camera RGB stereo + depth camera |
|---|---|
| Sensor suite | 6-Axis IMU, Encoders |
| Imu | 6-axis IMU |
| Encoders | Encoders |
01 · Official source