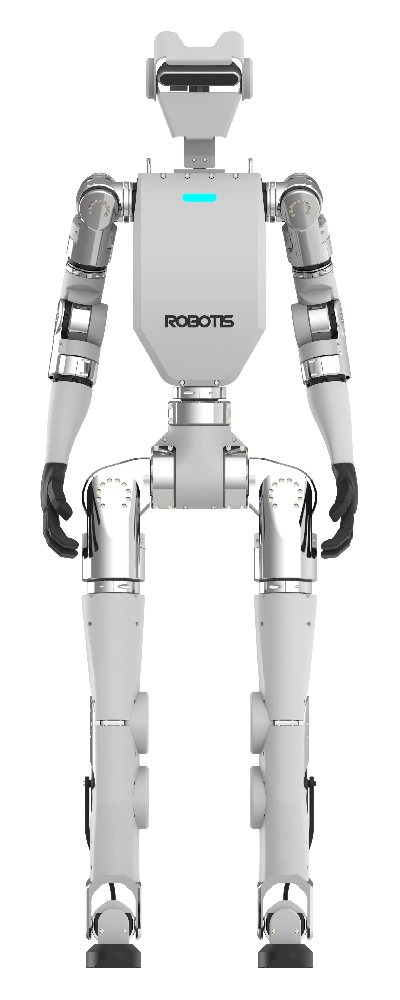
Commercial robotHumanoid
ROBOTIS AI Sapiens
1 editions
Official specs 13
ROBOTIS AI Worker, a humanoid robot.
Data & sources
Key specifications
| Weight | 90 kg |
|---|---|
| Dimensions | 604 × 602 × 1623 mm |
| Total DoF | 25 DoF |
|---|---|
| Arm dof | 7-DOF dual arms |
| dual arm degrees of freedom | 7 degrees of freedom, dual arms |
| Hand dof | 16 to 20 Degrees of Freedom (DOF) per hand 16–20 DoF per hand |
| dexterous hand degrees of freedom | 16-20 degrees of freedom |
| Dual arm degrees of freedom | 7 DOF |
| Power | 25 V / 80 Ah / 2040 Wh |
|---|
| Learning methods | teaching and reinforcement learning |
|---|
| Arm configuration | dual arms |
|---|---|
| Dexterous hand degrees of freedom | 16-20 DOF |
| Supported tasks | wire-harness assembly, welding, quality inspection |
| Locomotion type | Swerve Drive omnidirectional mobile base |
|---|---|
| Locomotion type | Swerve-drive omnidirectional mobility |
| Mobility base | mobile base |
| Drive system | Swerve Drive omnidirectional mobile base |
| Operating environment | industrial environments |
|---|---|
| Robot form factor | semi-humanoid industrial robot |
| Mobile velocity | 1.5 m/s |
|---|
| Single arm payload | 3 kg |
|---|
| Environmental perception | autonomous environmental perception |
|---|
| Open source coverage | full-chain open-source |
|---|
01 · Official source
02 · Official source
03 · Official source
04 · Official source


