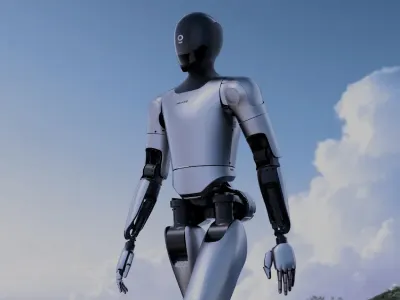
Commercial robotHumanoid
Rainbow Robotics HUBO2
1 editions
Official specs 11
product_type: Dual-Arm Mobile Manipulator · Generative-AI platform: Dual-arm mobile manipulator for generative-AI era.
Data & sources
Key specifications

| Weight | 131 kg |
|---|---|
| Standing dimensions | 0.6 x 0.69 x 1.4 m (W x D x H) |
| Upper body mass | 38 kg |
| Lower body mass | 42 kg |
| Mobile base mass | 51 kg |
| Supplementary height | 120 cm |
| Supplementary mass | 43 kg |
| Total degrees of freedom | 24 DOF |
|---|---|
| Actuator provenance | actuators from collaborative robots and AMR core components used in cooperative robots and AMR |
| Degrees of freedom per arm | 7 DOF x 2 |
| Degrees of freedom per leg | 6 DOF |
| Gripper dof | 1 DOF x 2 |
| Whole body control axes | 20-axis full-body control 20-axis whole-body control |
| Wheel dof | 1 DOF x 2 |
| Non wheel axis count | 22 axes excluding wheels axis |
| Joint actuator type | BLDC and DC motor with harmonic reduction gear |
| Motor servo controller count | Motor servo controller for each 2 actuator (18ea) |
| Battery voltage | 50 V |
|---|---|
| Battery capacity | 25 Ah |
| Wheel dof | 1 DOF x 2 |
|---|---|
| Locomotion type | wheel-type, high-speed mobile base |
| Maximum speed | 1.5 m/s |
| Vertical torso movement | more than 50 cm vertically |
| Single-arm payload | 3 kg (per arm) |
|---|
| Vision camera included | not included |
|---|---|
| Ankle force torque sensing | 6-axis F/T sensor with tilt sensor in the ankle |
| Pelvis inertial sensing | inertial sensor on the pelvis |
| Force torque sensor axes | 3-axis F/T sensor |
01 · Official source
02 · Official source
03 · Official source