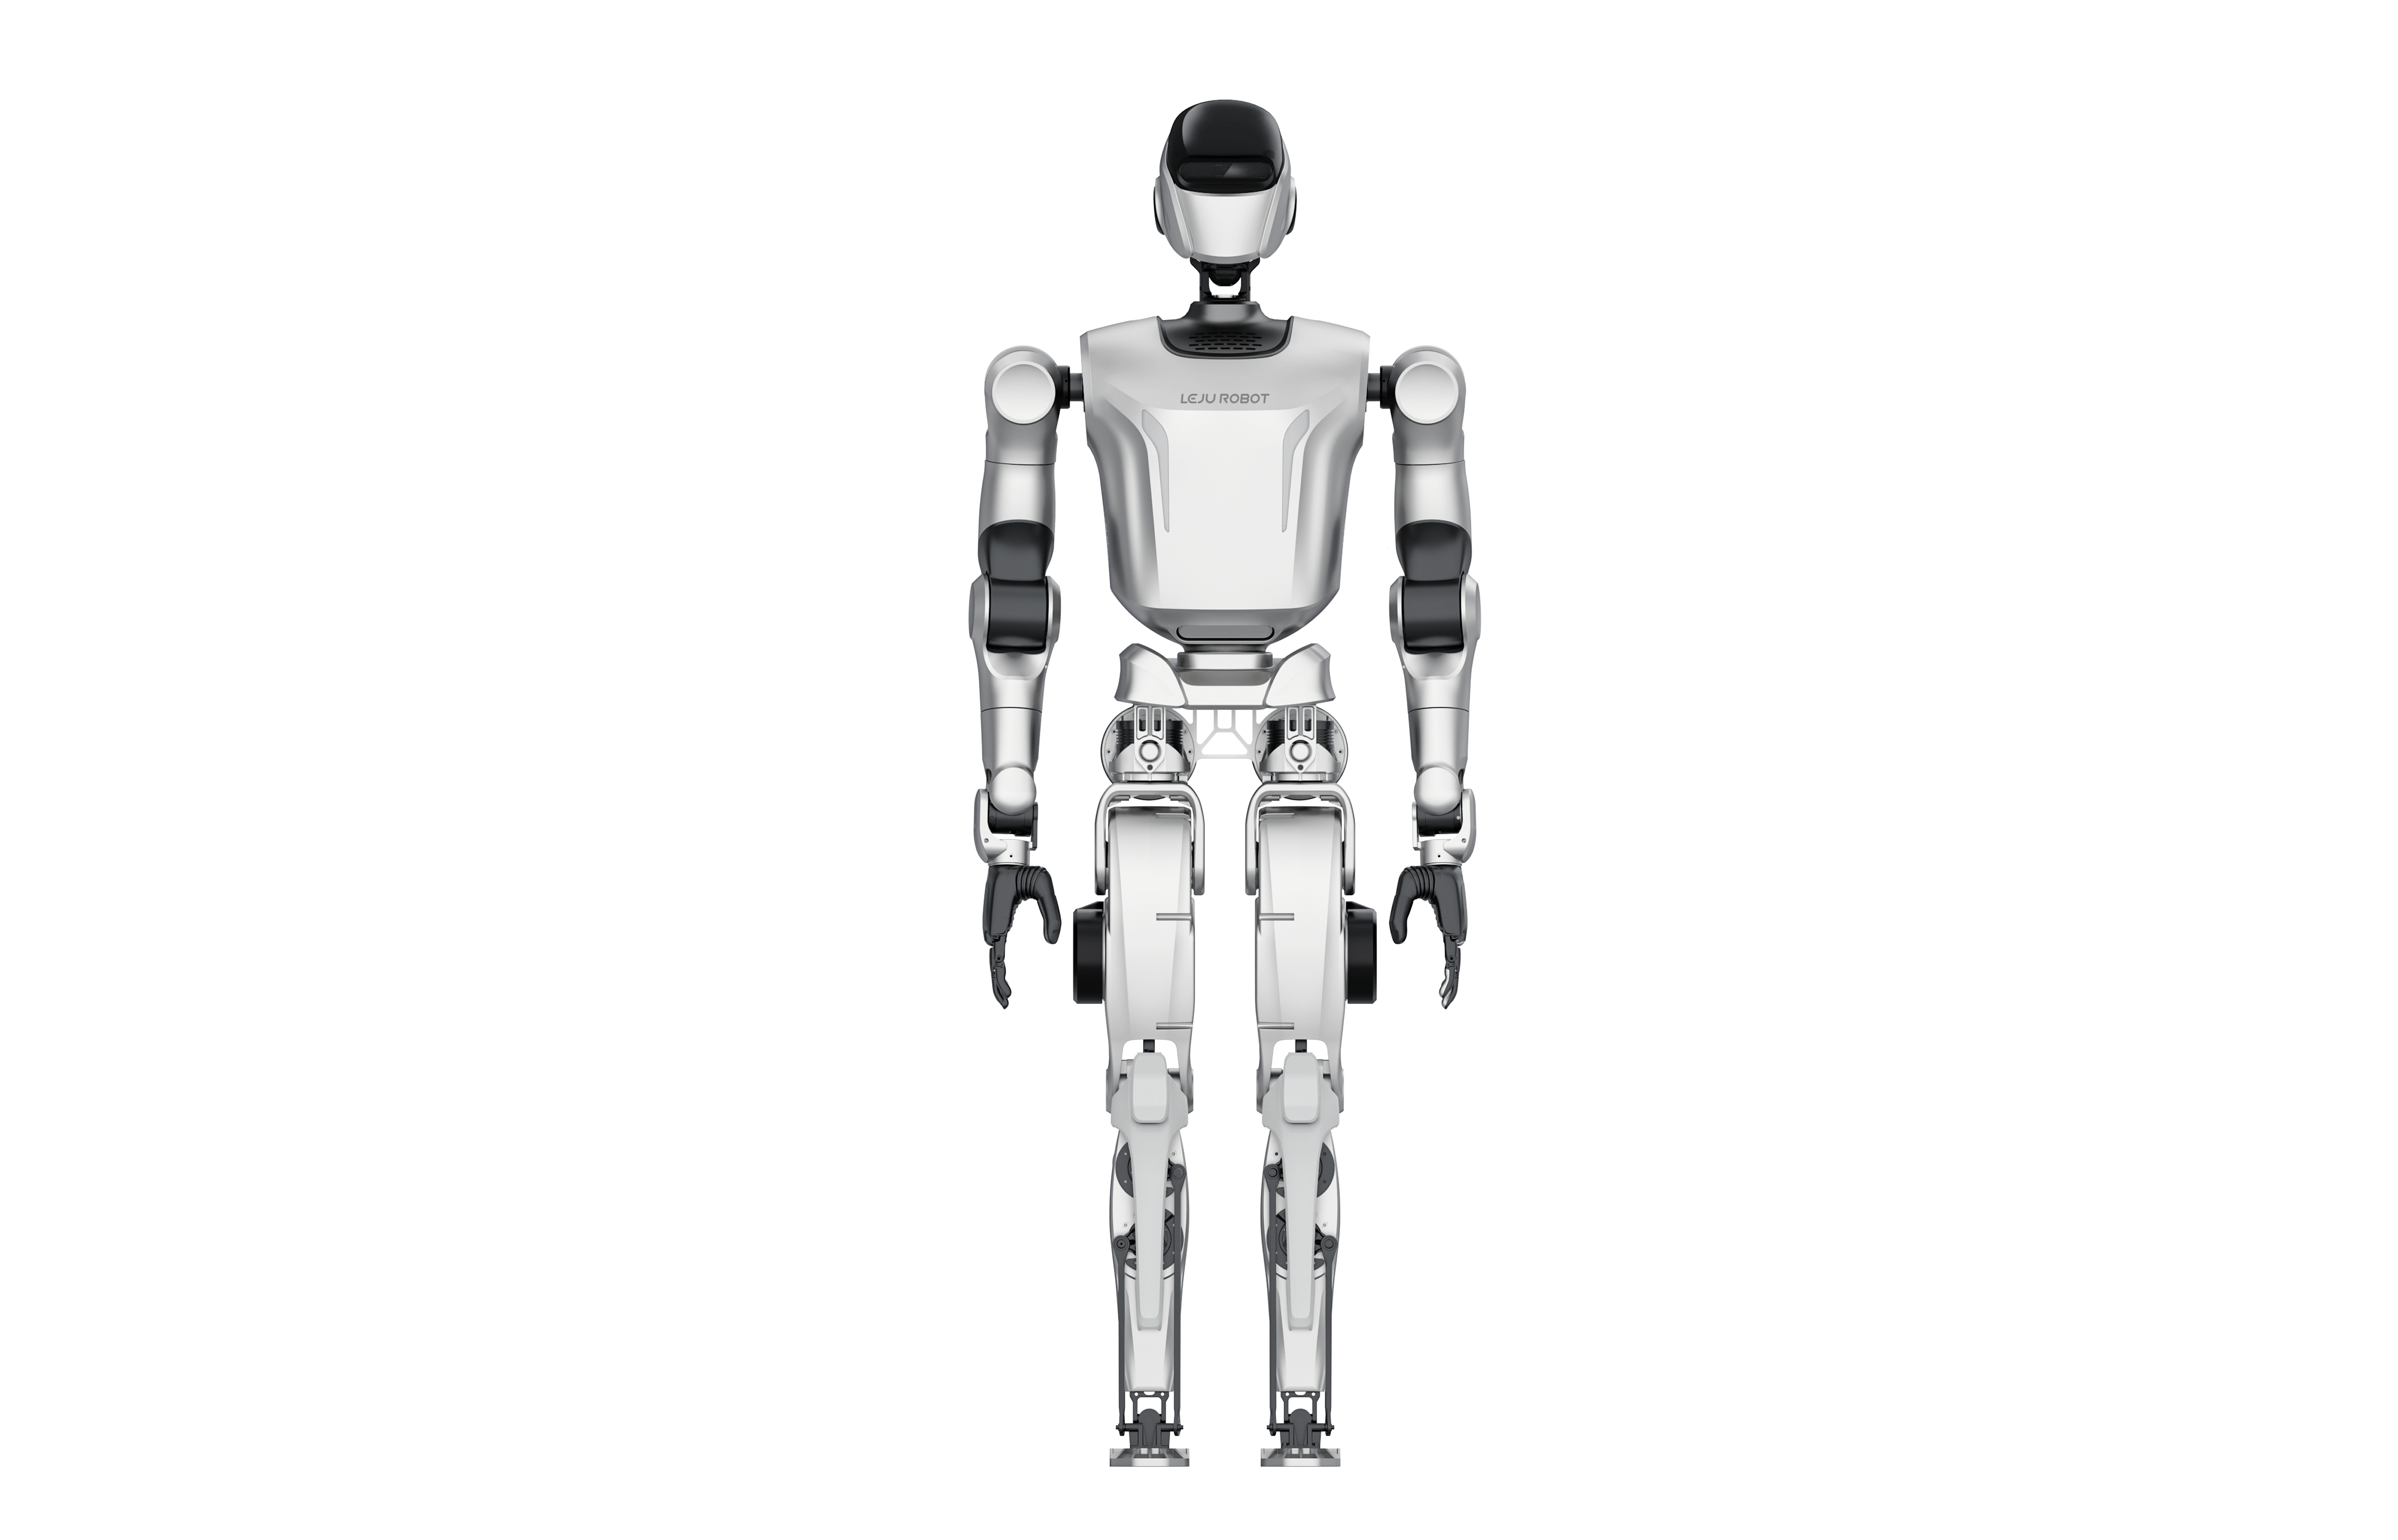
Commercial robotHumanoid
PAL Robotics ARI
Official specs 8
height: 1.58 m · weight: 50–65 kg
Data & sources
Key specifications

| Height | 1.58 m |
|---|---|
| Weight | 50–65 kg |
| Total degrees of freedom | 14–40 DoF (platform configuration) |
|---|---|
| Degrees of freedom per arm | 4, 5 or 7 DoF (platform configuration) |
| Torso dof | 2 DoF (yaw and roll) |
| Degrees of freedom per leg | 6 DoF |
| Actuator control modes | Current; speed; position; impedance; force/torque (optional) PIDs; current; speed; position; impedance; force/torque |
| Actuators and transmissions | Custom linear actuators with integrated force sensors provide a wide range of motion and high speed and torques at the joints |
| Arm configuration | 4 DoF arms (platform configuration) 5 DoF arms (platform configuration) 7 DoF arms (platform configuration) |
| Linear actuators | Custom linear actuators with integrated force sensors |
| Motor placement | Motors close to the body |
| Leg length decoupling | Decoupling leg length from hip swing motions |
| Closed loop force torque control | Closed loop force/torque controllers at joint level |
| Closed loop joint force torque control | Closed-loop force/torque joint controllers |
| Battery capacity | 976 Ah |
|---|---|
| Runtime | 3 h |
| Power output 12v | 12 V/5 A power out |
| Power output 71 4v | 71.4 V/2 A power out |
| Arm tool flange | ISO 9409-1 interface with quick tool changer ISO 9409-1 |
|---|---|
| Quick tool changer | Interface with quick tool changer |
| General payload | 7 kg (4 DoF arms) |
| Box picking policy | Box picking |
| Arm payload 4 extended | 7 kg |
| Arm payload 4 bimanual | 30 kg |
| Arm payload 5 extended | 5 kg |
| Arm payload 5 bimanual | 28 kg |
| Arm payload 7 extended | 3 kg |
| Arm payload 7 bimanual | 25 kg |
| Parallel gripper | Parallel gripper |
| Parallel gripper configuration | 2 fingers, 1 DoF |
| Seed robotics rh8d end effector | Seed Robotics RH8D |
| Seed hand configuration | 5 fingers, 7 DoF |
| Inspire robots hand | Inspire Robots RH56F1 – RH56E2 |
| Inspire hand configuration | 5 fingers, 6 DoF |
| Whole body inverse dynamics controller | Whole body inverse dynamics controller |
|---|---|
| Walking policy | Walking |
| Push recovery policy | Push recovery |
| Running policy | Running |
| Jumping policy | Jumping |
| Stair climbing policy | Stair climbing |
| Dance policy | Dance |
| Low moving inertia | Low moving inertia |
| Control loop frequency | EtherCAT 2 kHz control loop |
|---|---|
| Os and middleware | Ubuntu LTS + ROS 2 LTS + PAL OS |
| Control framework | ros2_control |
| Robot models | URDF and MJCF model |
| Simulation and rl tools | MuJoCo and mjlab |
| Ai development pipelines | Open-source reinforcement learning; motion retargeting; imitation learning |
| Rl policies library | Walking; push recovery; running; jumping; stair climbing; dance; box picking |
| Visualisation and diagnostics | WebGUI – web interface; hardware statistics history; Rviz2 |
| Research access level | Access to real-time loop; custom software deployment; ROS 2 API C++/Python |
| Kinematic whole body controller | Hierarchical IK solver; teleoperation demo with VR kit |
| Gpu | NVIDIA Jetson GPU (optional) |
| Ai controller framework | Online control-policy switching |
| Open source reinforcement learning | Open-source reinforcement learning |
| Motion retargeting | Motion retargeting |
| Imitation learning | Imitation learning |
| Web interface | Web interface |
| Motor control electronics | In-house electronics for motor control and sensor acquisition |
| Decentralized electronics | Embedding custom and decentralization |
| Imu update rate | 1 kHz update rate; accuracy 0.25° static, 0.5° dynamic |
|---|---|
| Imu accuracy static | 0.25° (static) |
| Imu accuracy dynamic | 0.5° (dynamic) |
| Vision system | 4× RGB-D cameras |
| Imu ahrs update rate | 1 kHz update rate |
| Wrist force torque sensor | Wrist 6 axis force/torque sensor |
| Foot force torque sensor | Feet 6 axis force/torque sensor |
| Leg actuator force sensor | Integrated force sensor |
| Seed hand tactile pressure sensors | Tactile pressure sensors |
| Onboard emergency button | Onboard emergency button |
|---|---|
| Wireless emergency button | Wireless emergency button |
| Safety integrity level | SIL 2 based on IEC61508 |
| Performance level | PL d based on EN ISO 13849-1 |
| Connectivity | 2× WiFi6 (2.4 GHz + 5 GHz) |
| Usb 3 type a ports | 2× USB-3 Type A |
| Usb 3 2 type c ports | 4× USB 3.2 Type C |
| Gigabit ethernet ports | 2× Gigabit Ethernet RJ45 |
01 · Official source
02 · Official source