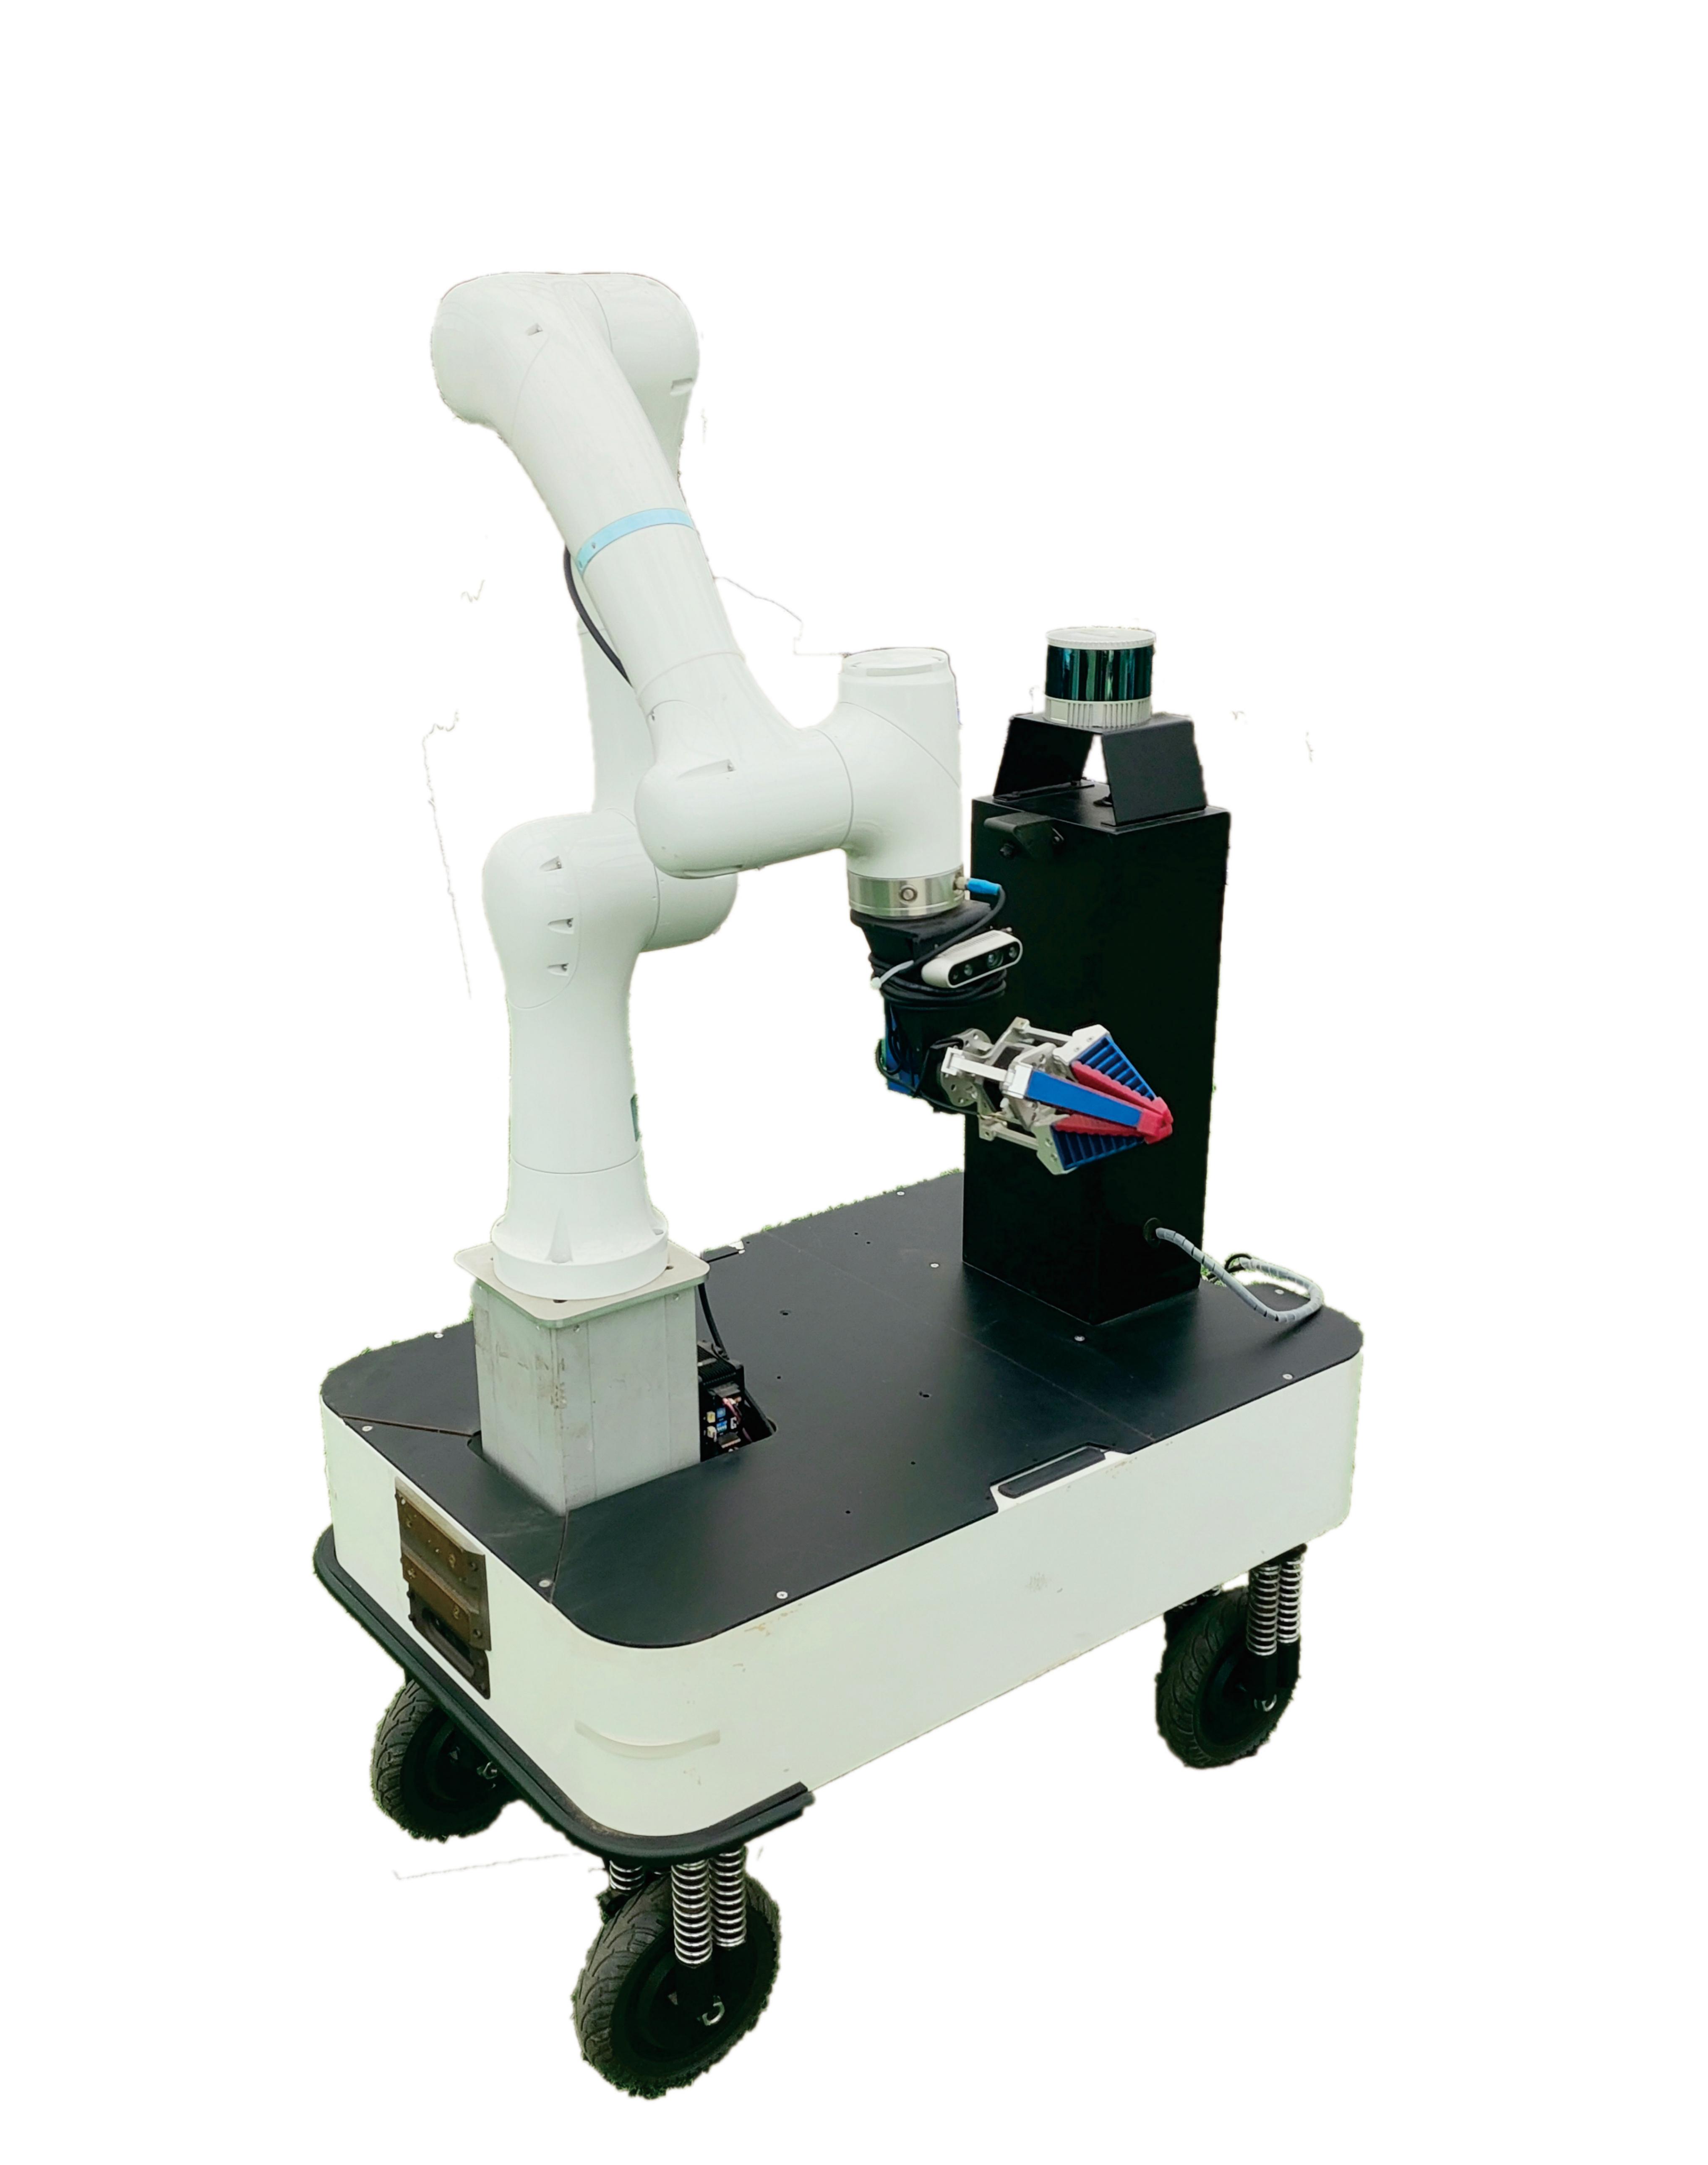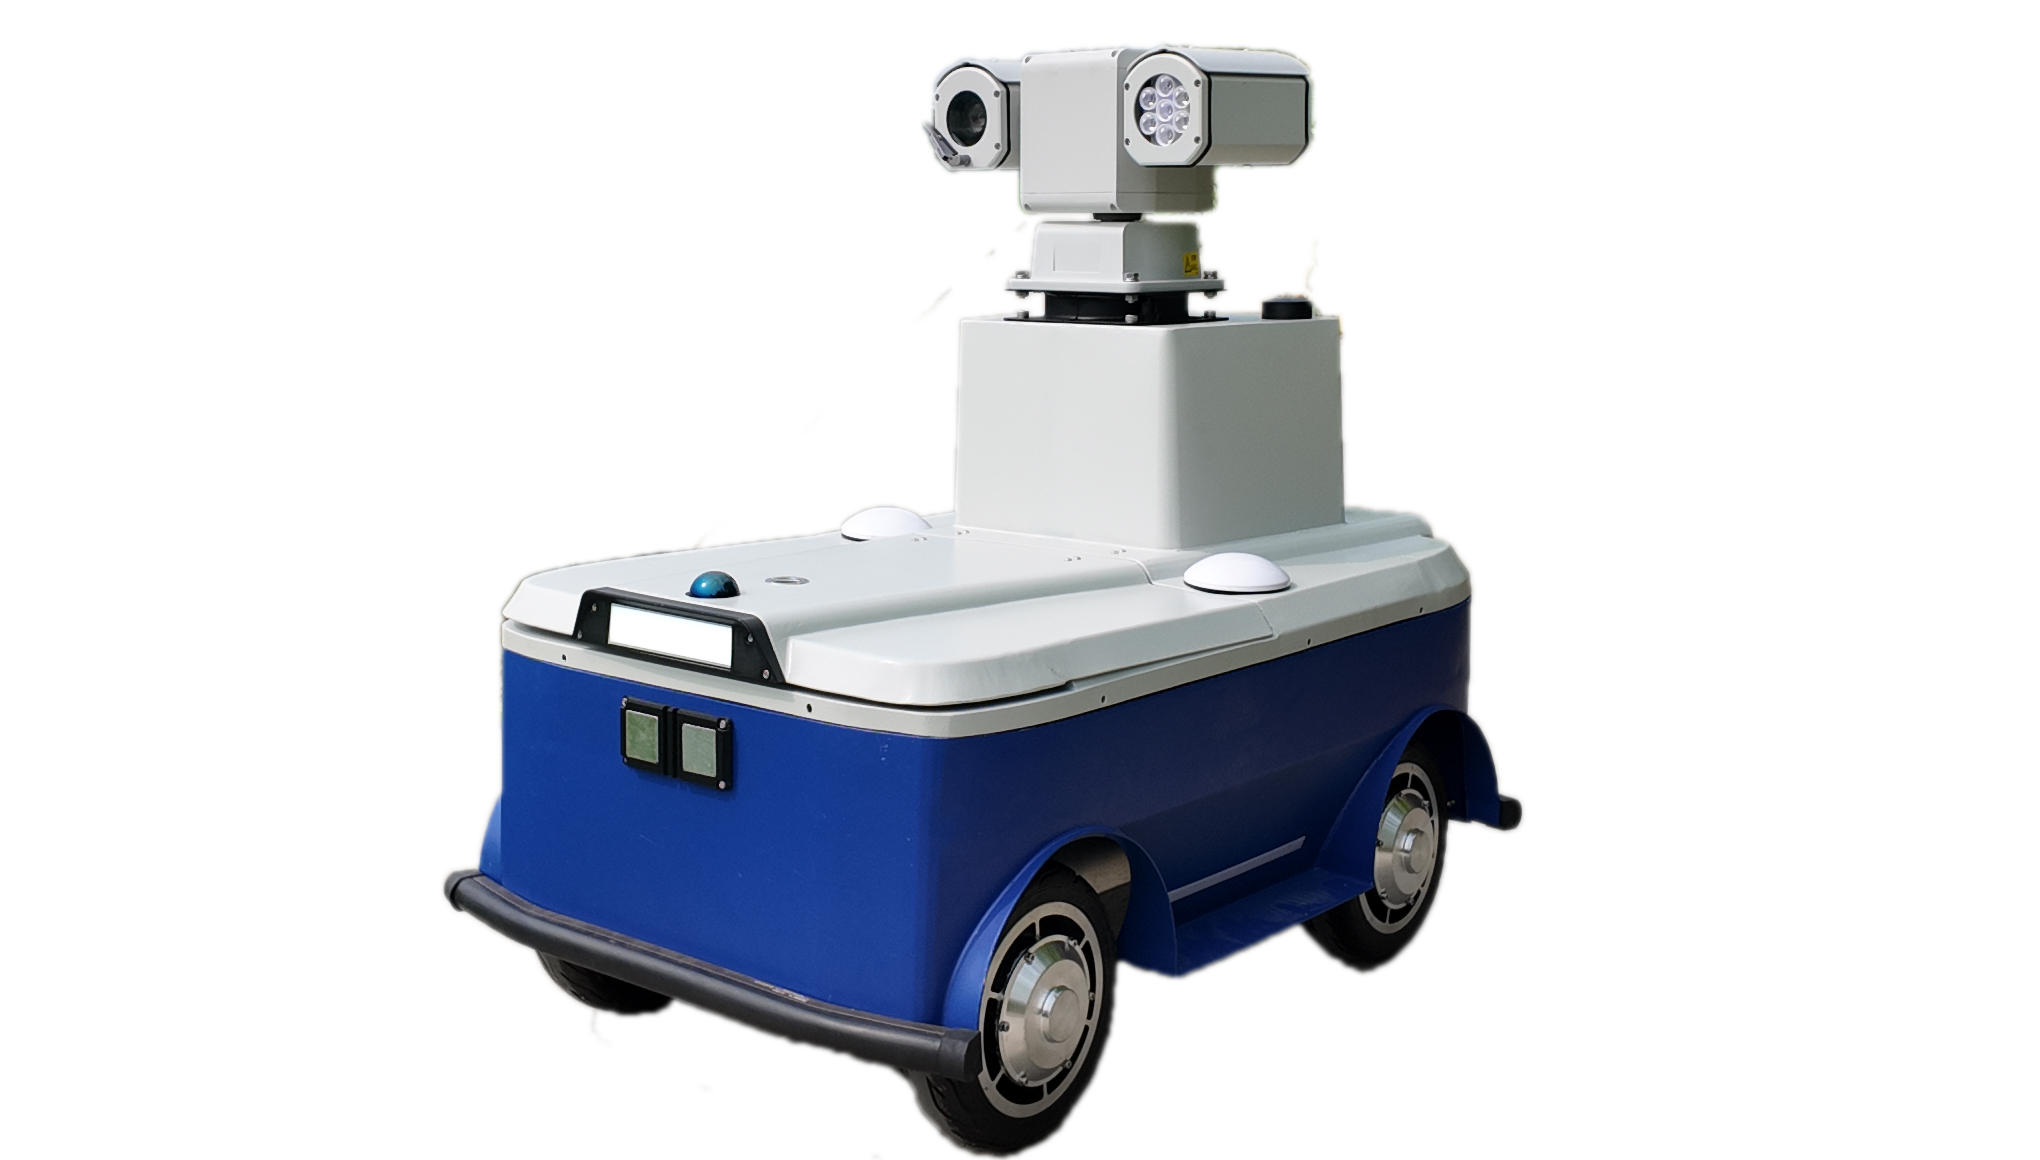
Commercial robotMobile robot
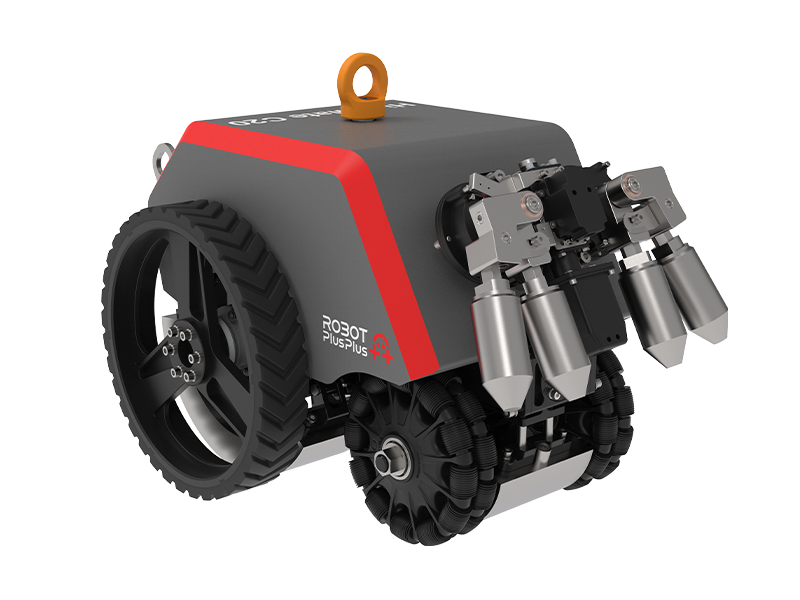
ShiHe HighMate C20
Official specs 13
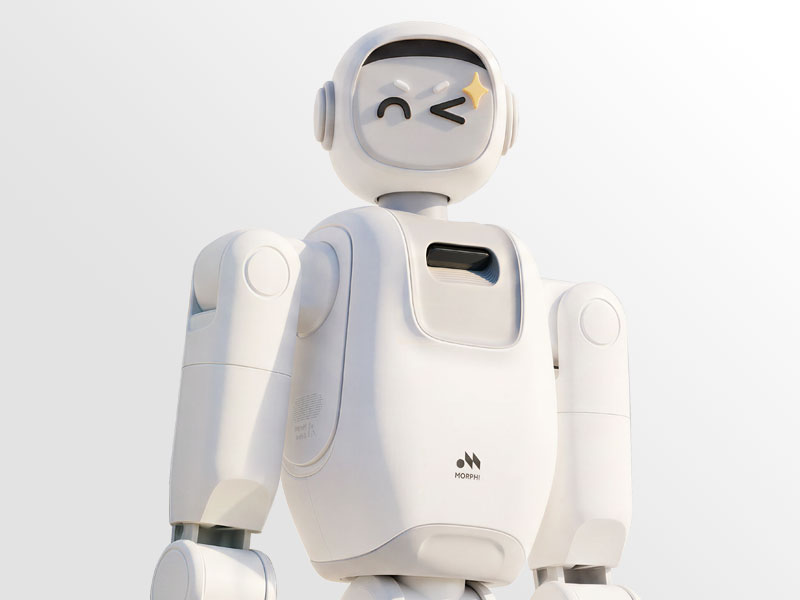
Moqi MORPHI KINO, a mobile robot.
Data & sources
Key specifications
| Motion control | Low-latency motion control |
|---|
| Locomotion type | First wheel-based dual-arm robot |
|---|---|
| Drive type | Wheeled |
| Navigation mode | Autonomous navigation |
| Product position | First product |
|---|
| Arm count | 2 arms |
|---|---|
| Arm operation | Dual-arm collaborative operation |
| Perception mode | Multimodal perception |
|---|
| Embodied model | Self-developed embodied foundation model MoRA |
|---|---|
| Task understanding | Task and environment change understanding |
| Operation sequence | Continuous operation from moving to recognition, grasping, delivery, and organizing |
|---|
01 · Official source