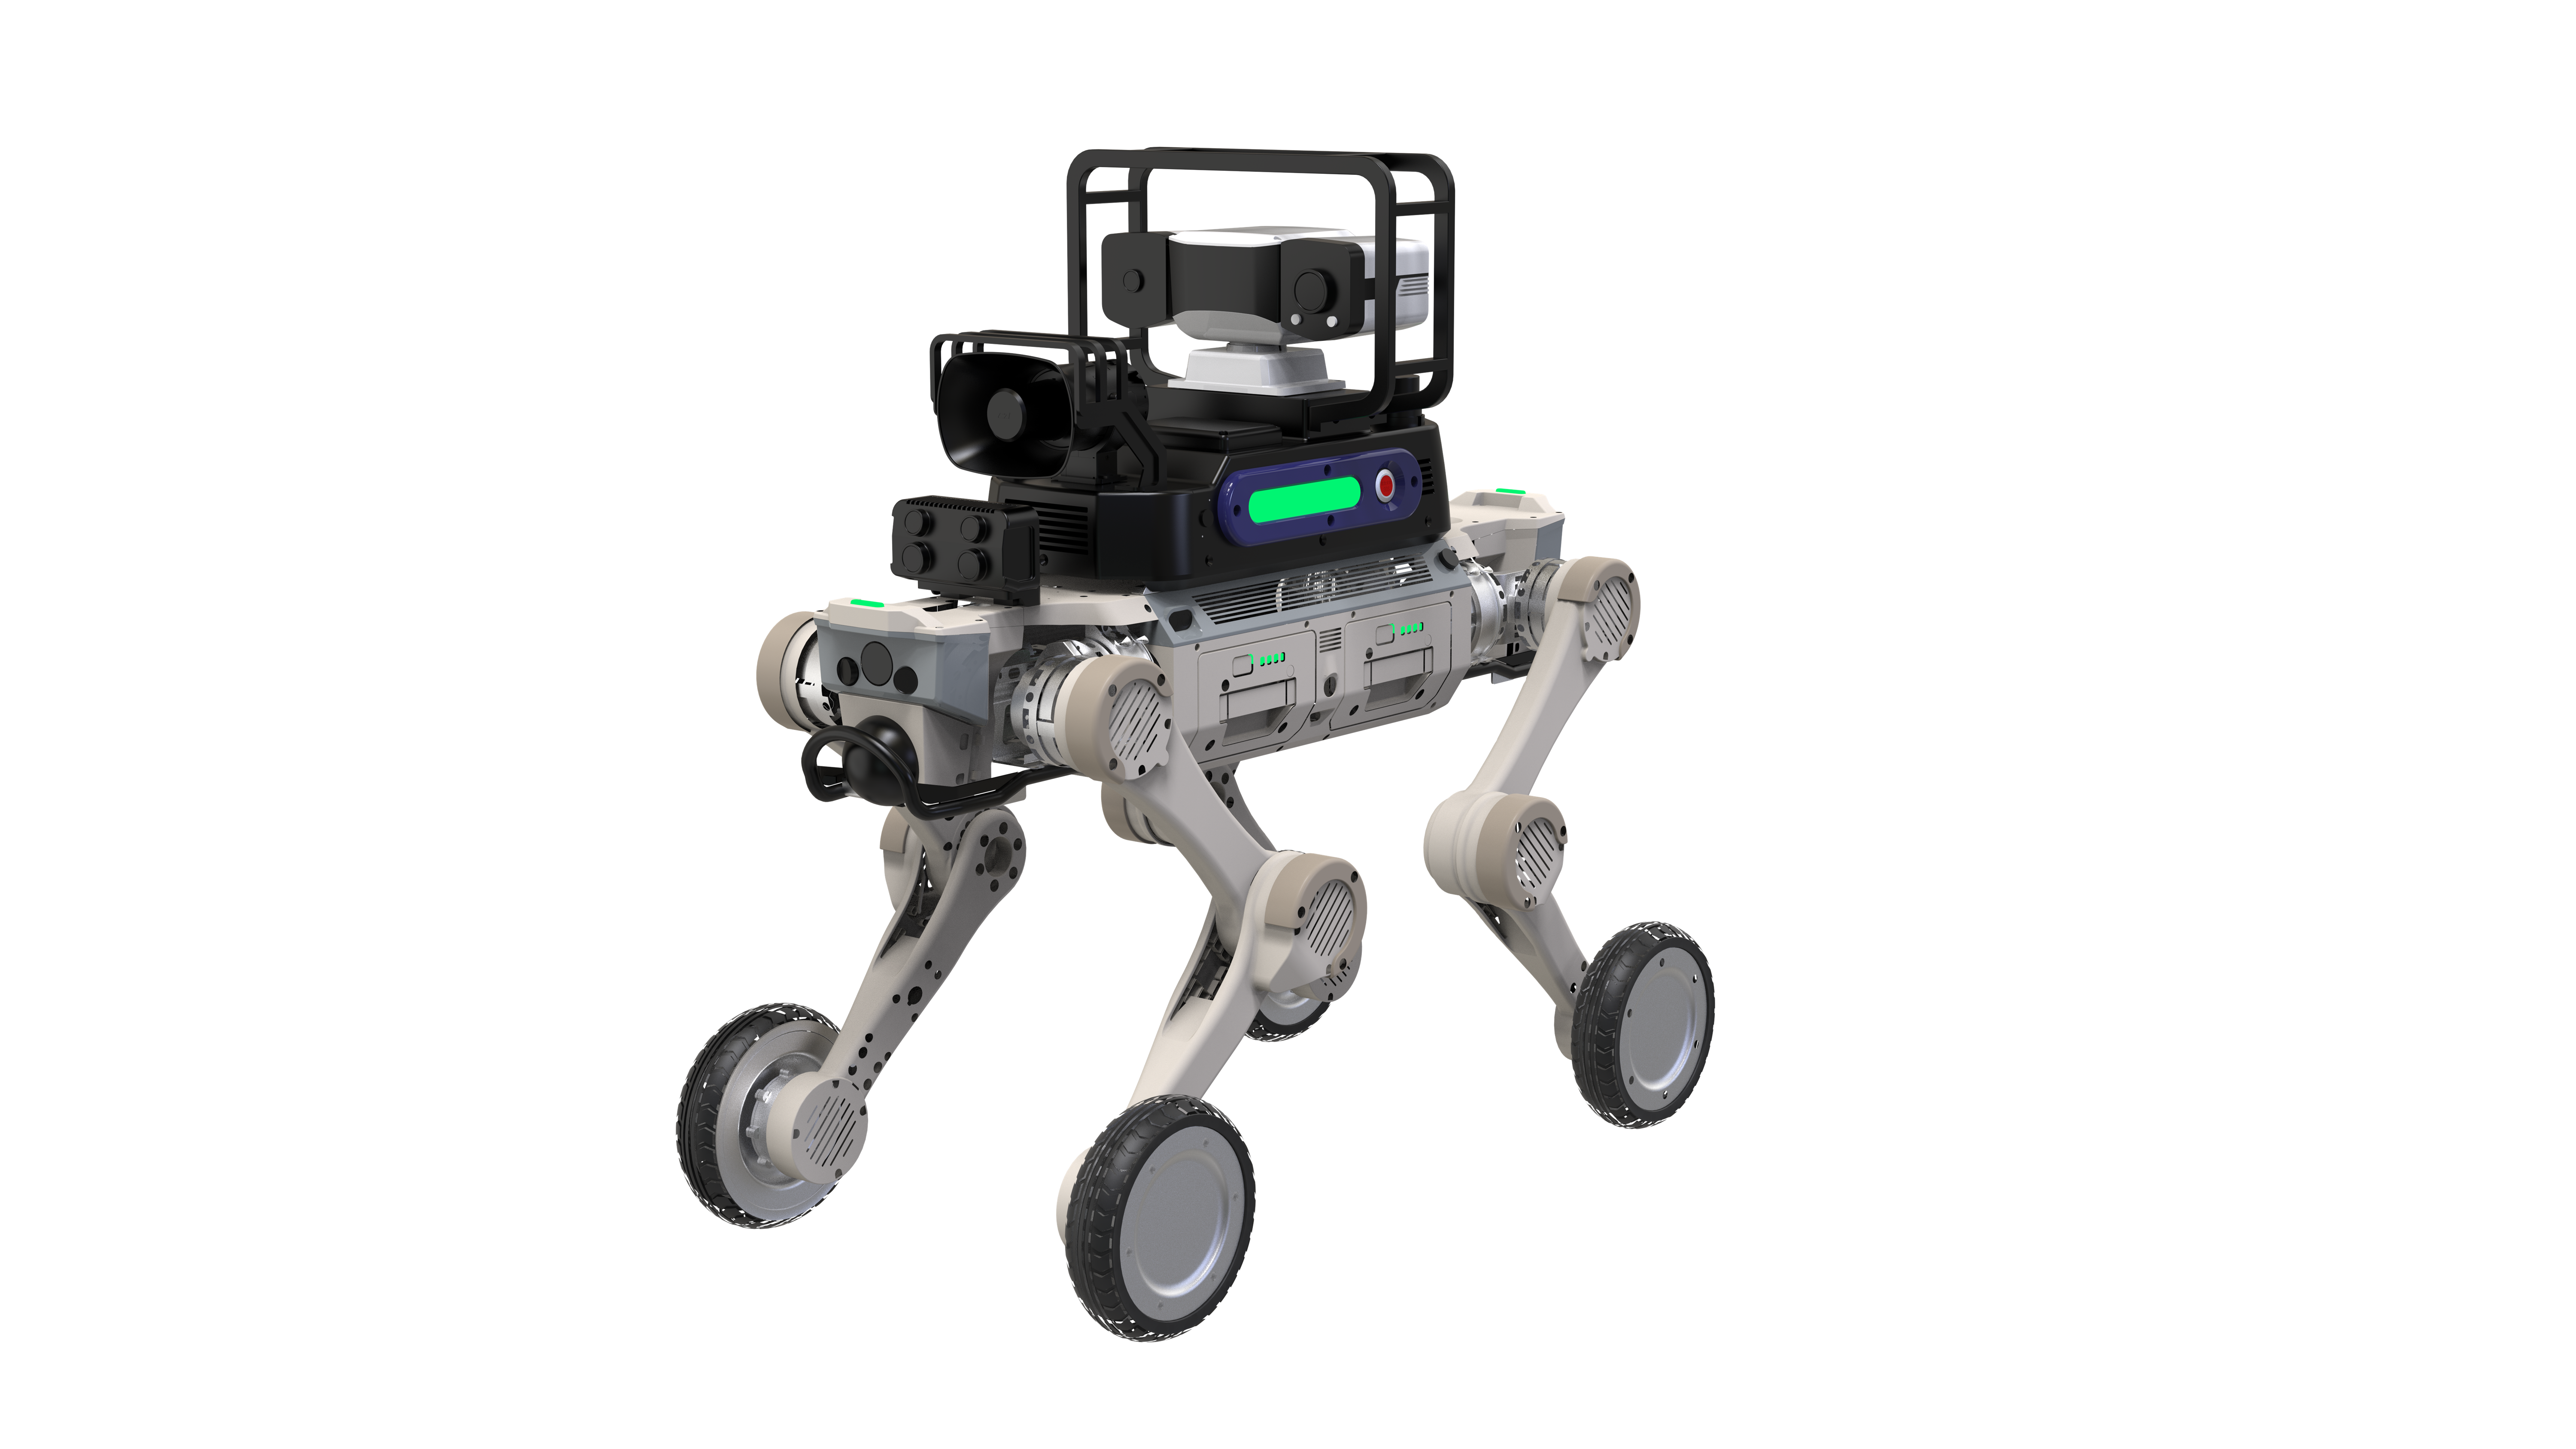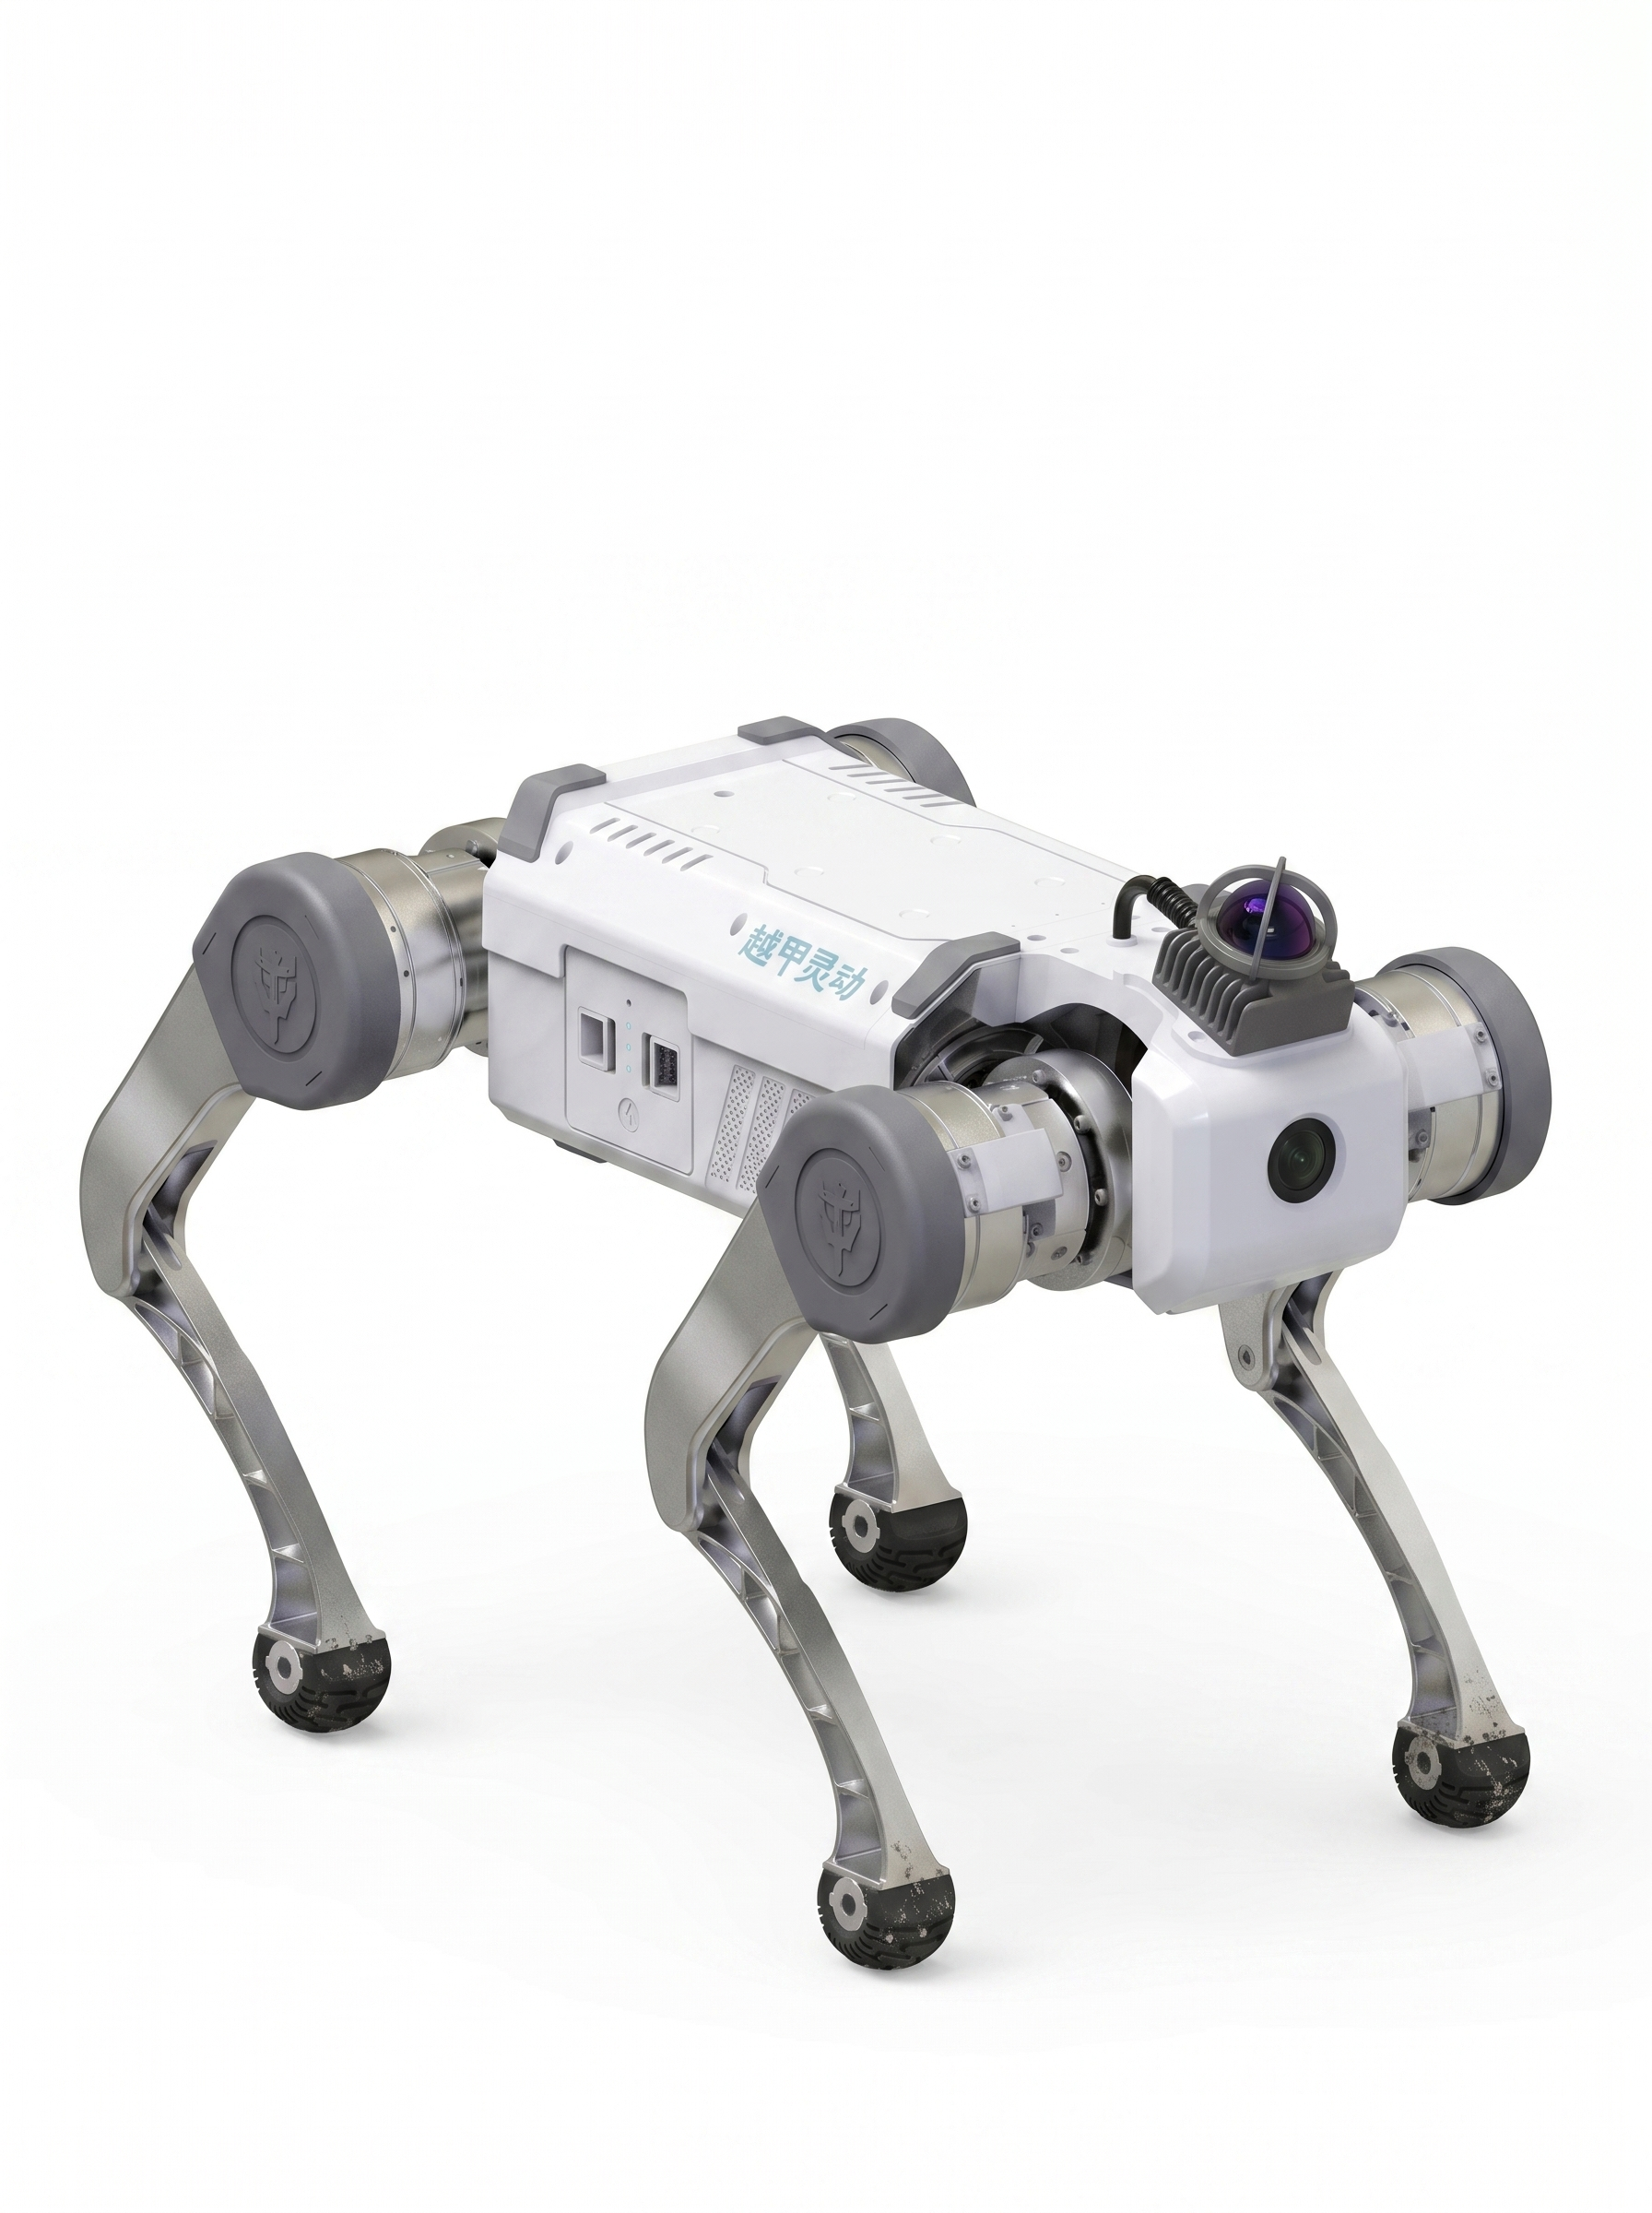
Commercial robotQuadruped
Yuejia Lingdong YJ 30 Series
Official specs 15
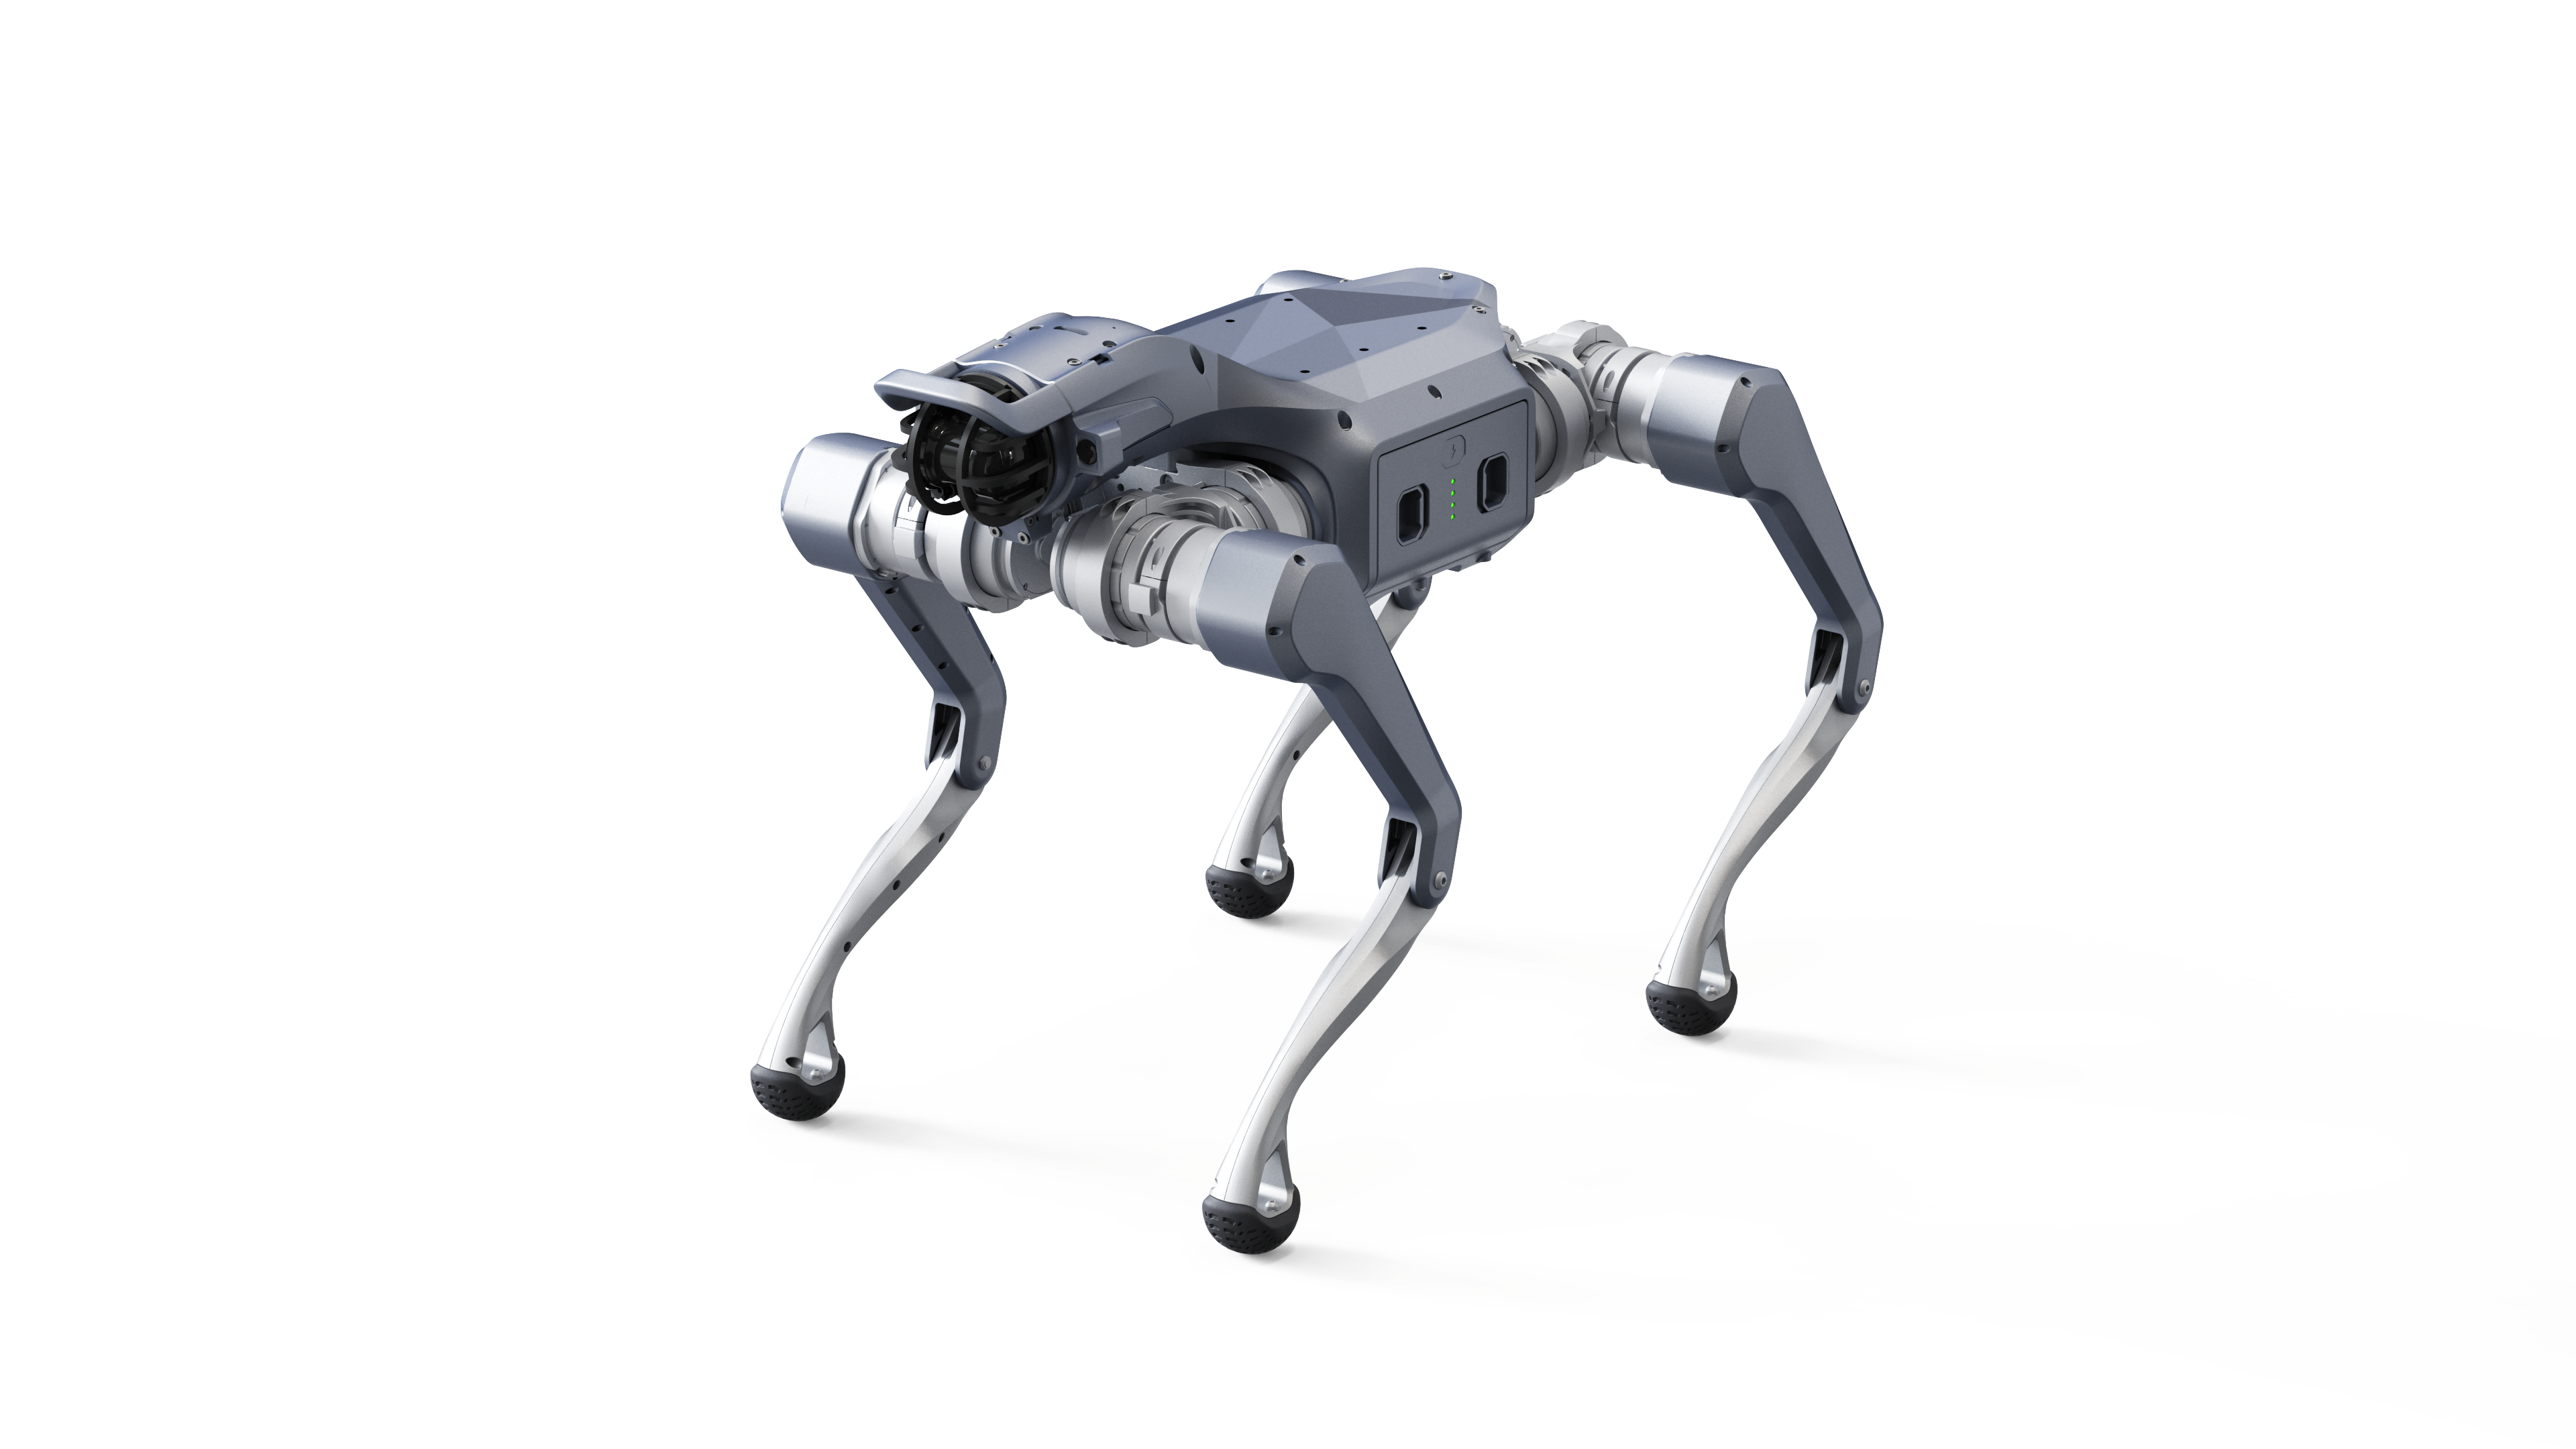
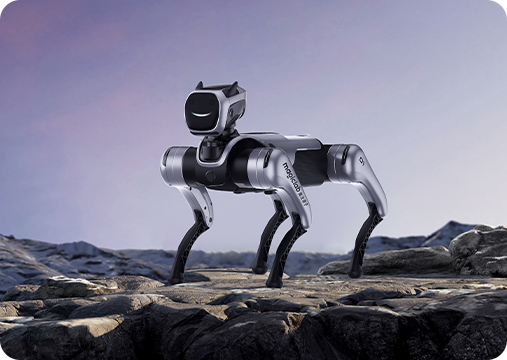
MagicLab MagicDog, a quadruped robot.
Data & sources
Key specifications
| Weight | 15.8 kg |
|---|---|
| Weight | 17 kg |
| Standing dimensions | 670×350×560 mm |
| Dimensions lying | 720×440×290 mm |
| Standing dimensions | 67 × 35 × 56 cm |
| Total degrees of freedom | 13 DOF |
|---|---|
| Total degrees of freedom | 13 DOF |
| Joint torque max | approximately 37.5 N·m |
| DoF | 13 DoF |
| Joint degrees of freedom | 13 joint degrees of freedom |
| Electric joints | low-noise high-torque electric joints |
| Power max | 3200 W |
|---|---|
| Operating voltage range | 22–36 V |
| Battery voltage | 29.6 V |
| Battery capacity | 8200 mAh |
| Battery fast release rating | 240.7 W fast release |
| Runtime | 1.5–3 h |
| Battery life | 2.5 h |
| maximum climbing clearance | 15 cm |
|---|---|
| maximum slope angle | 40° |
| Maximum speed | 3.0 m/s |
| Obstacle height max | 15 cm |
| Climbing angle max | 40° |
| Climbing angle | 40° |
| Obstacle step | 18 cm |
| Robot type | quadruped robot dog |
| Demonstrated postures | backflip, moonwalk, handshake, stretching |
| High difficulty postures | more than 30 high-difficulty postures |
| Obstacle crossing | active obstacle crossing |
| Adaptive uneven terrain mobility | adaptive mobility on slopes, gravel roads, and uneven terrain |
| Maximum climbing height difference | 15 cm |
| Maximum slope angle | 40 degrees |
| General payload | approximately 5 kg |
|---|
| Sensor suite | Sensors: 2D LiDAR, dual camera, depth camera, 4K HD camera, fisheye camera, ultrasonic sensor. |
|---|
| Payload | 5 kg (max 10 kg) |
|---|
| Movement speed | 0–3 m/s |
|---|
| Emotional interaction system | built-in emotional interaction system |
|---|---|
| Emotional expression | autonomous emotional expression |
| First model claim | first model |
|---|
01 · Official source
02 · Official source