Commercial robotHumanoid
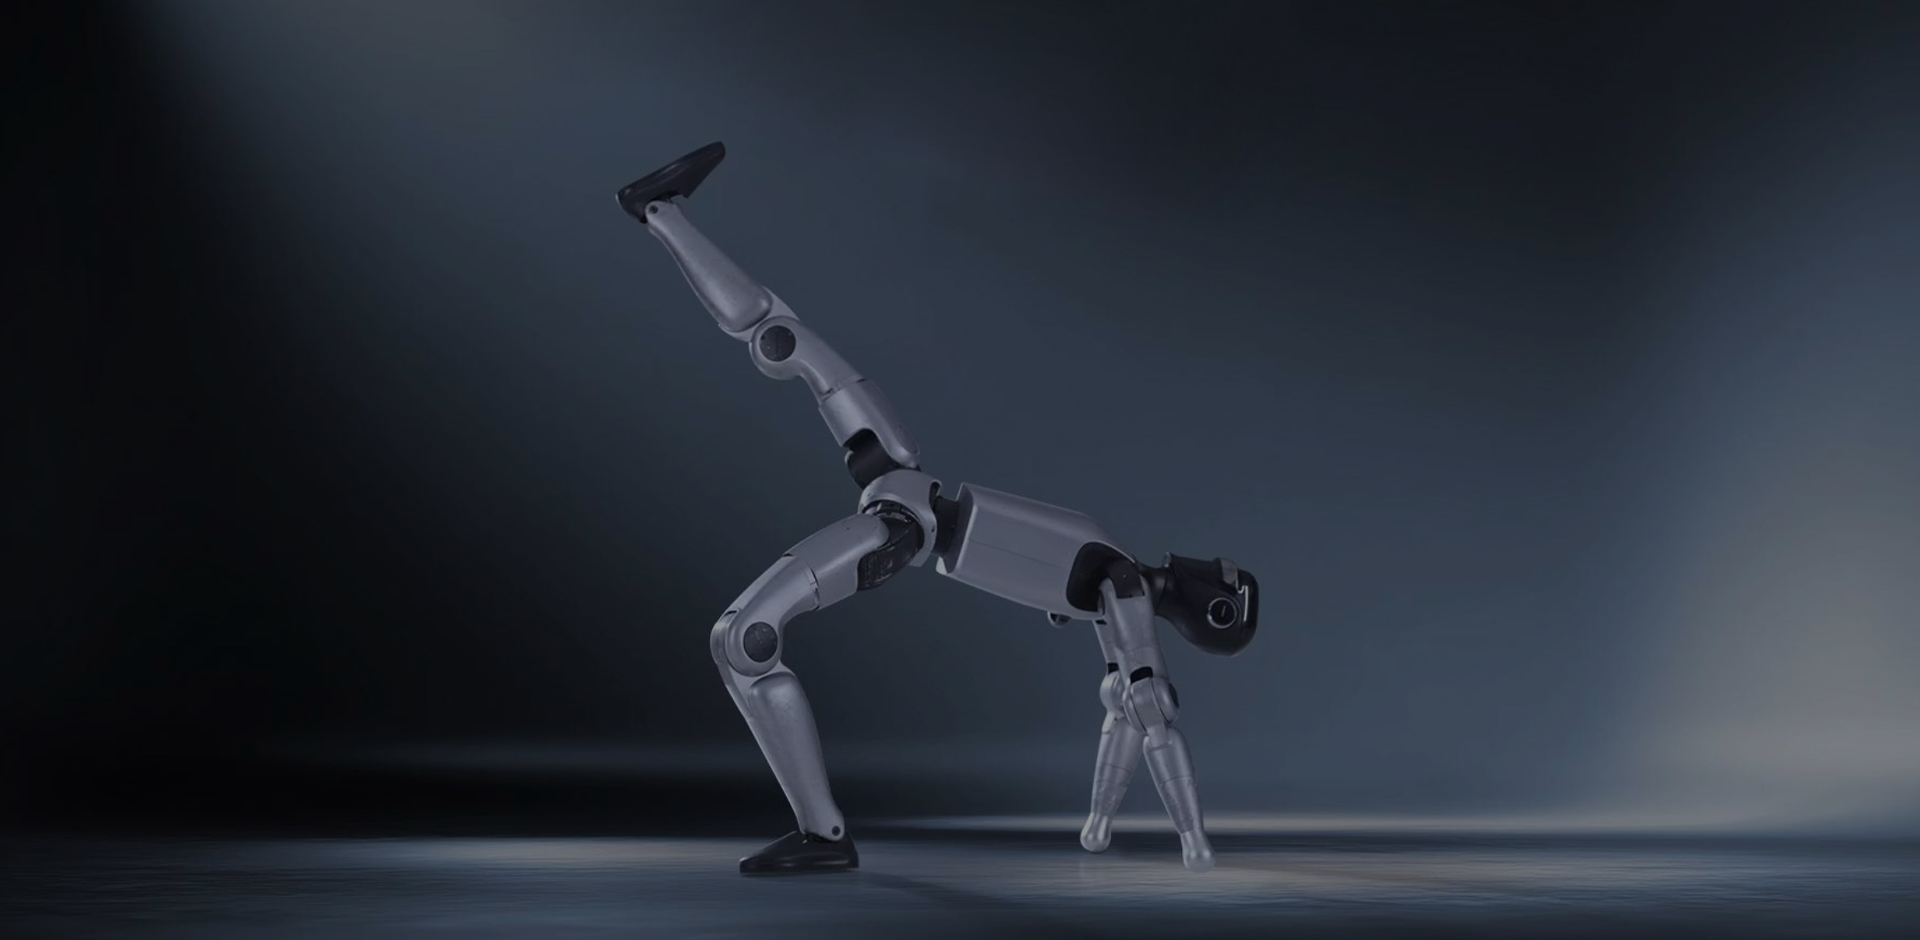
MagicLab MagicBot D1
Official specs 19
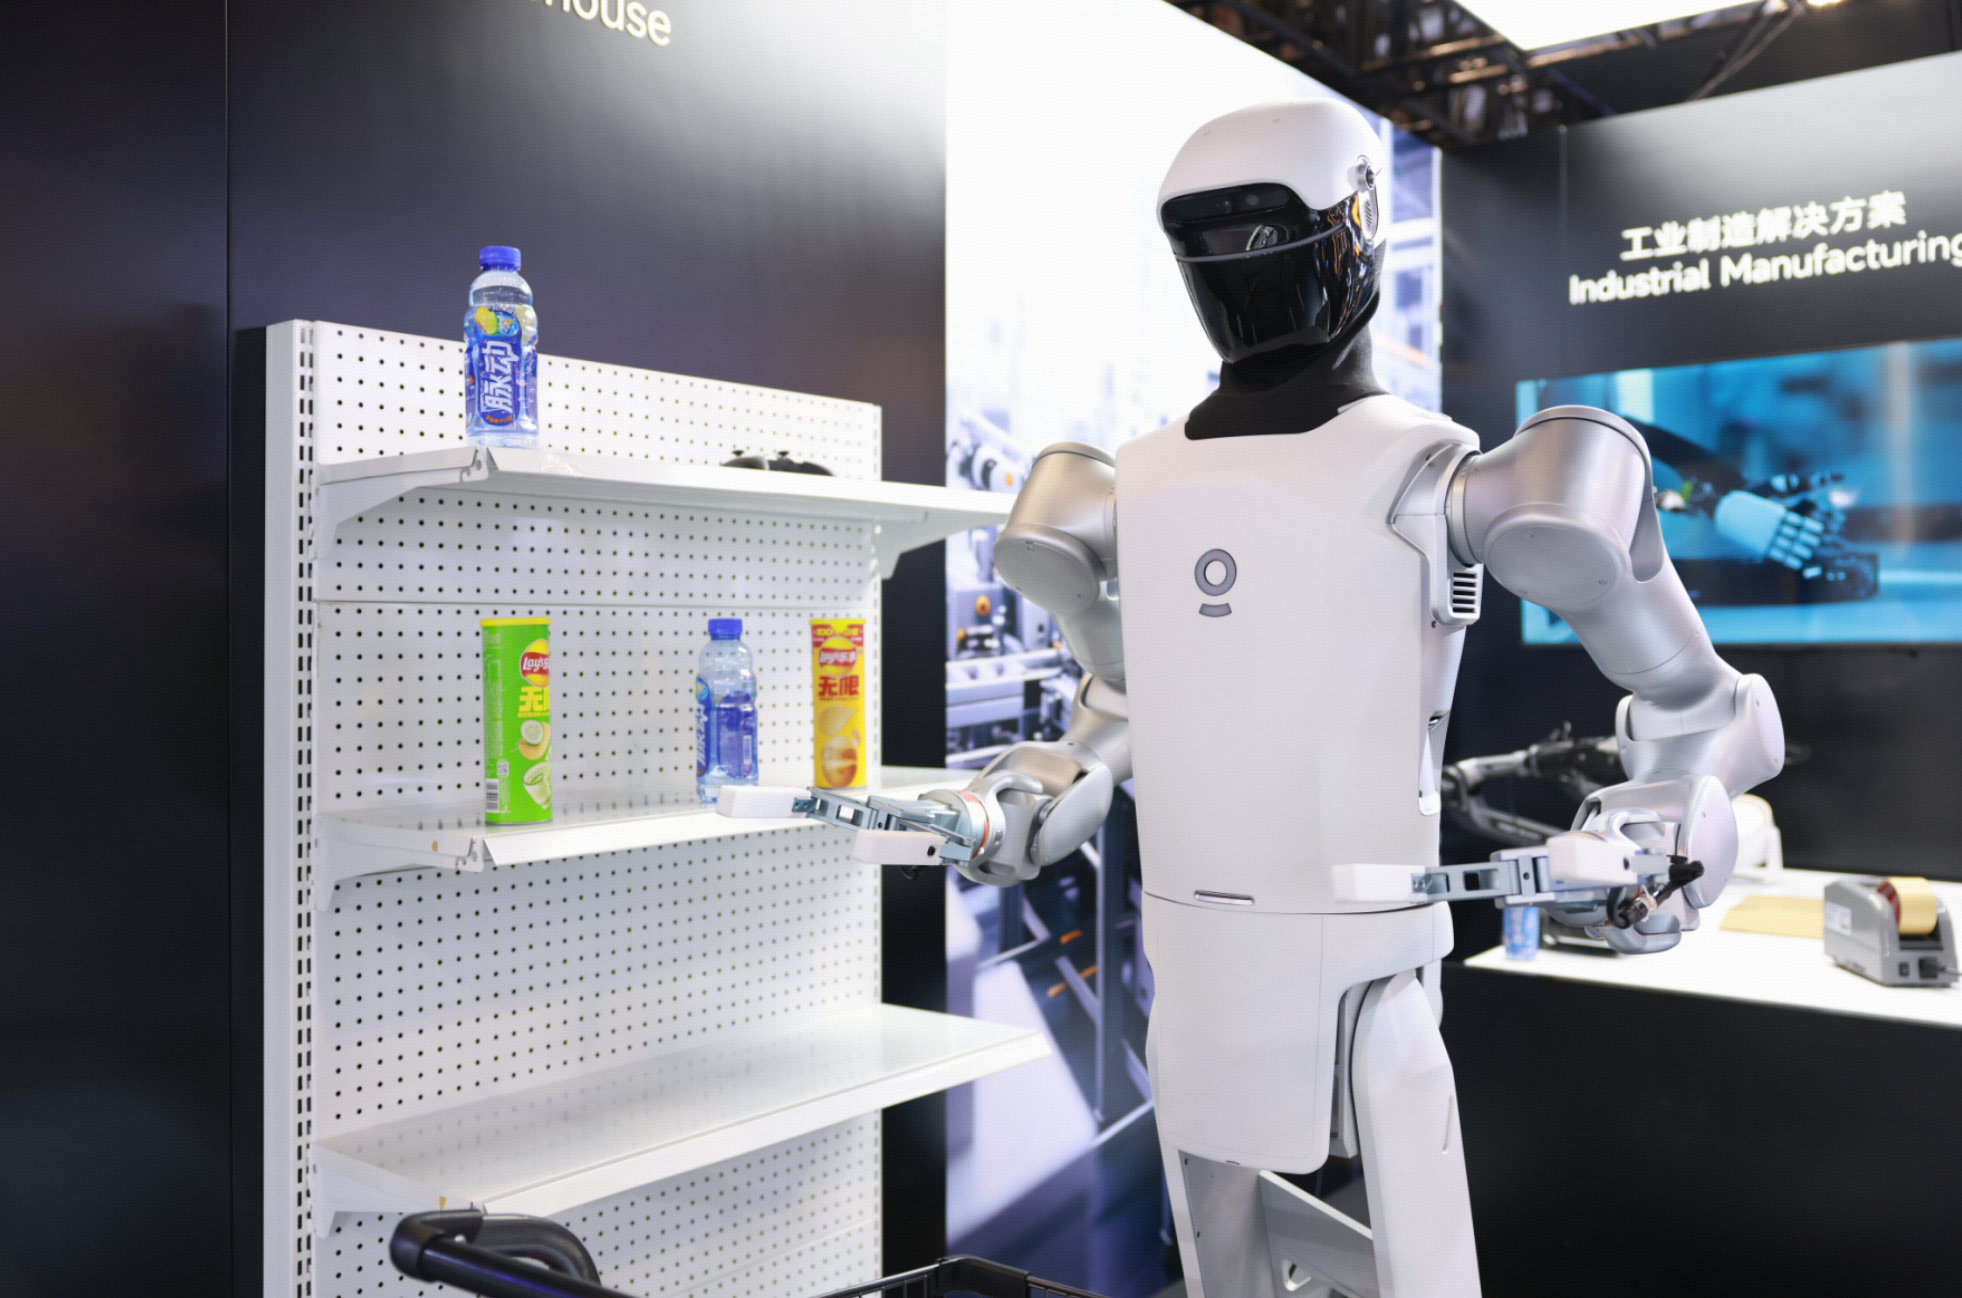
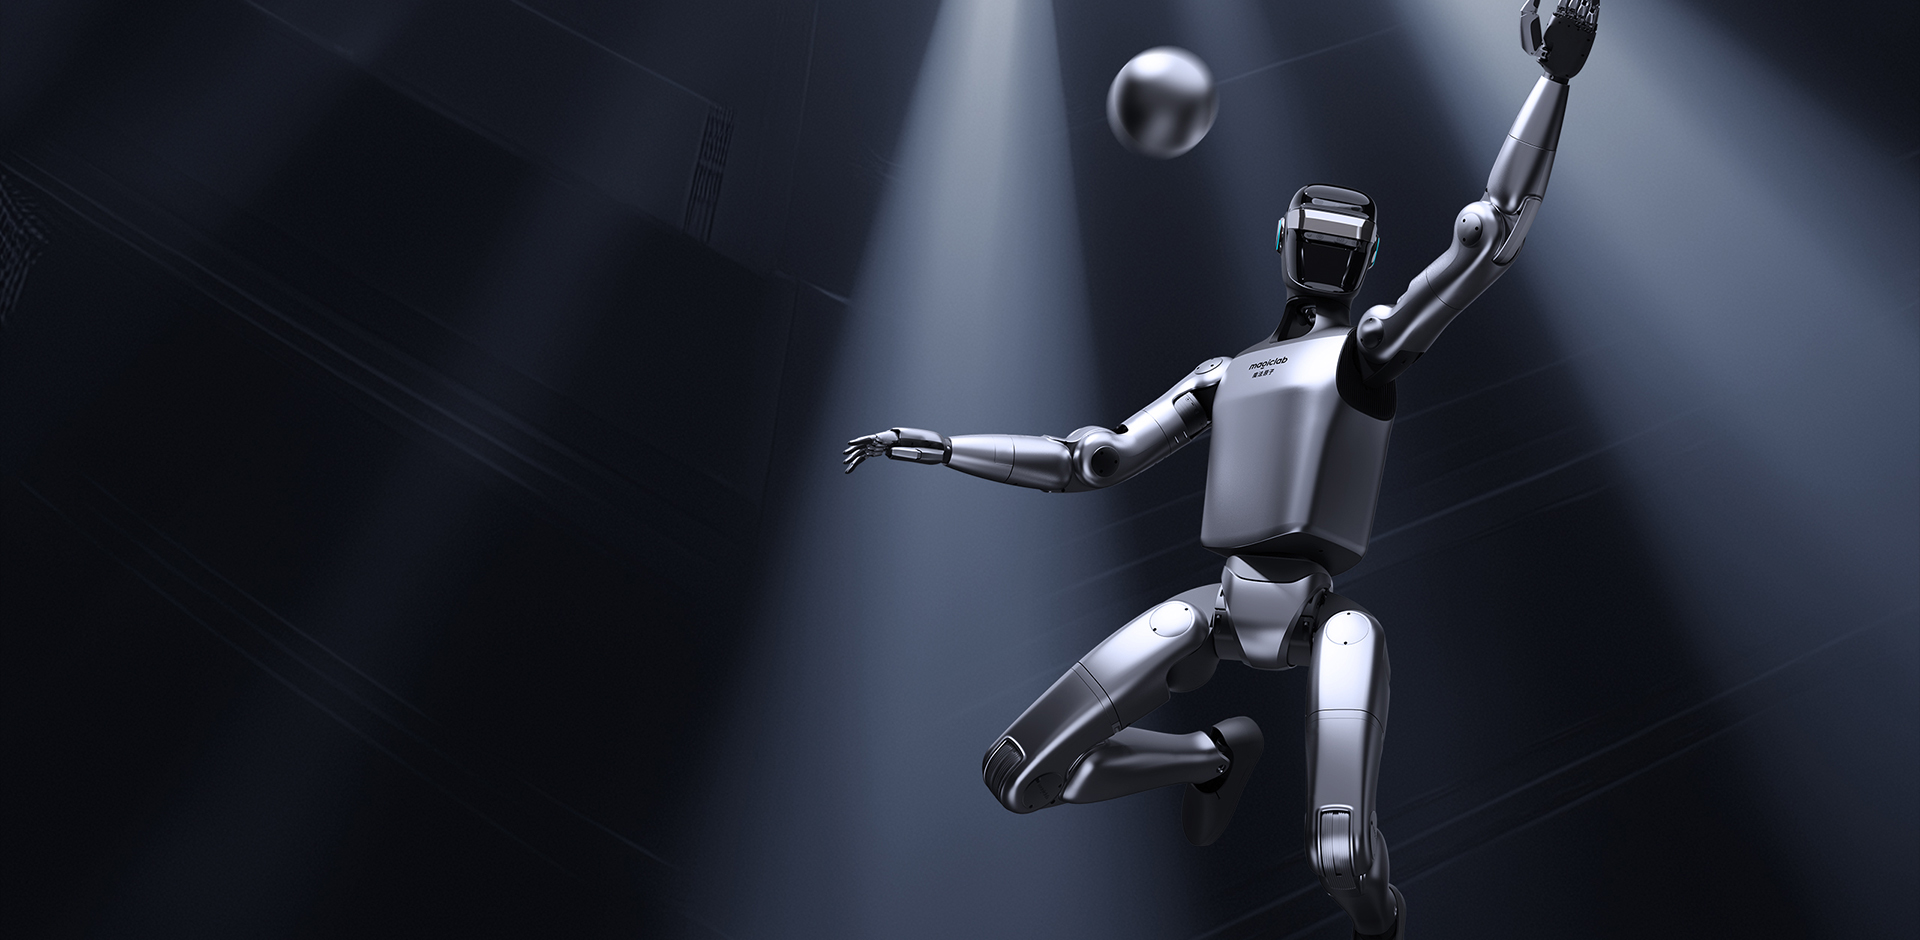
MagicLab MagicBot Z1, a humanoid robot.
Data & sources
Key specifications
| Weight | approximately 40 kg |
|---|---|
| Weight | 40 kg |
| Weight | ≥40 kg |
| Standing dimensions | 1.369 × 0.422 × 0.2 m |
| Folded dimensions | 0.73 × 0.422 × 0.395 m |
| Shank and thigh length | 0.6 m |
| Arm span | approximately 0.5 m |
| Standing dimensions | 1369 × 422 × 200 mm |
| Standing dimensions | 1369 × 422 × 200 mm |
| Total degrees of freedom | 24 DOF |
|---|---|
| Total DoF | 24 DoF |
| Total degrees of freedom | 24 basic DoF; expandable to 50 DoF |
| Joint maximum torque | over 130 N·m |
| Joint motion range | up to 320° |
| Construction materials | high-strength aluminum alloy and engineering plastics |
| Thermal management | thermal simulation technology to optimize its overall structure and airflow design, maintaining ideal internal temperatures |
| Degrees of freedom per leg | 6 DOF |
| Head degrees of freedom | 1 |
| Waist degrees of freedom | 1 DOF |
| Degrees of freedom per arm | 5 DOF |
| Dexterous hand degrees of freedom | 11-DOF tactile dexterous hand |
| Joint output bearing | Industrial-grade high-rigidity roller bearing |
| Joint motor | Low-inertia, high-speed, high-overload permanent magnet synchronous motor |
| Maximum knee torque | 100 N·m 130 N·m |
| Head z axis joint rom | ±40° |
| Lumbar z axis joint rom | ±160° |
| Knee joint rom | 0~152° |
| Hip joint rom | P±160°、R-30~+110°、Y±160° |
| Maximum knee torque | 100 N·m |
| Single arm DoF | 5 DoF |
| Single leg DoF | 6 DoF |
| Single arm degrees of freedom | 5+ DoF |
| Maximum joint torque | 130 N·m |
| Whole body motion | whole-body motion |
| Power supply mode | 15-cell battery |
|---|---|
| Smart battery capacity | 10000 mAh |
| Runtime | approximately 2 h |
| Battery life | 2 h |
| Battery capacity | 10000 mAh |
| Impact and wear resistance | resistance to impact and wear; subjected to falls or collisions, it remains stable |
|---|---|
| Heat dissipation system | Intelligent air-cooled heat dissipation |
| Wireless connectivity | WiFi6 and Bluetooth 5.2 |
| Microphone array | Available |
| Speaker power | 5 W |
| Handheld remote control | Available |
| Emotional interaction | anthropomorphic emotional interaction |
| Open apis | Rich suite of open APIs |
|---|---|
| Vln navigation algorithms | VLN navigation algorithms |
| Vlm multimodal model | VLM multimodal large model |
| Basic computing power | 8-core high-performance CPU |
| High computing power module | None |
| Ota upgrade | Supported |
| Secondary development | Available |
| All domain perception | All-domain perception |
|---|---|
| Multi source sensing | Multi-source heterogeneous sensors |
| Sensor suite | 3D LiDAR, depth cameras and binocular cameras |
| Joint encoder | Dual encoder |
| Perception sensors | 3D LiDAR + depth camera + binocular fisheye camera + head tactile sensor |
| Sensor configuration | 3D LiDAR, depth camera, binocular fisheye camera |
| World perception | world perception |
| Autonomous mobility | enables autonomous mobility in complex environments |
|---|---|
| Autonomous navigation | Autonomous navigation and obstacle avoidance |
| Terrain adaptation | flat ground, grass, gravel, and stairs |
| All terrain capability | exceptional all-terrain capability |
| Robot type | bipedal humanoid robot |
| Single-arm payload | 2 kg |
|---|---|
| Maximum single arm payload | 3 kg |
| Dexterous manipulation | dexterous manipulation |
| Physical interaction | physical interaction |
| Maximum arm load | 2 kg |
|---|
| Release date | July 8, 2025 |
|---|
01 · Official source
02 · Official source
03 · Official source
04 · Official source