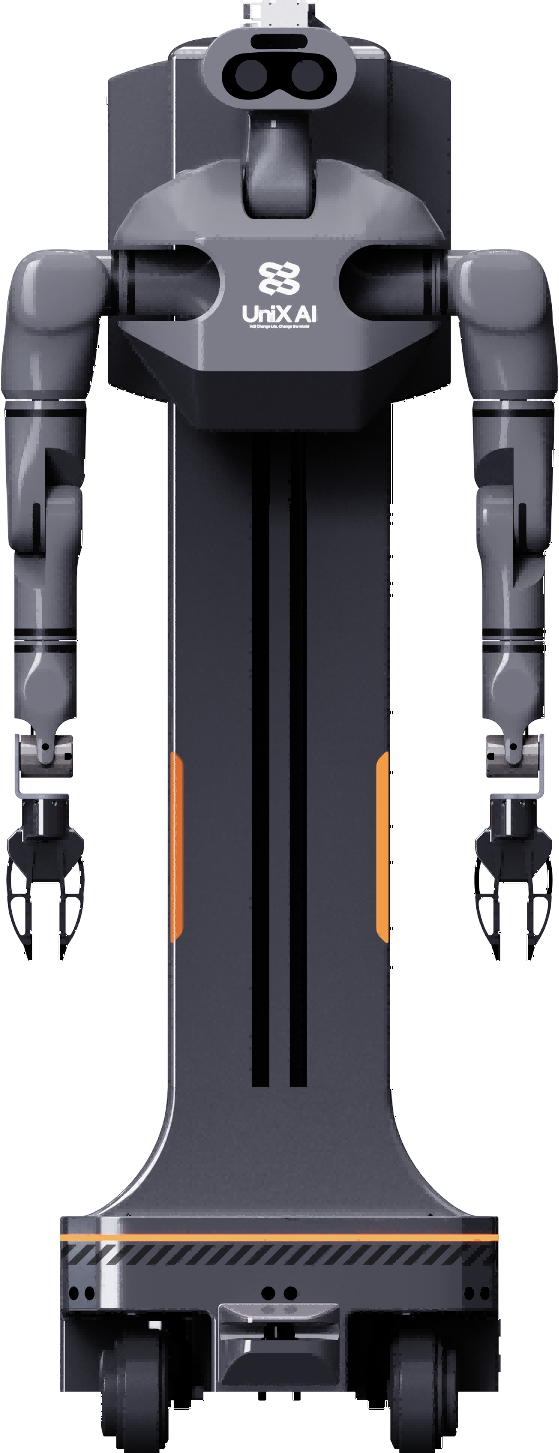
Commercial robotHumanoid
Booster Robotics Booster T1
3 editions
Official specs 68
Karlsruhe Institute of Technology (KIT) ARMAR-7, a humanoid robot.
Karlsruhe Institute of Technology (KIT)
Data & sources
Key specifications

| Humanoid body components | Humanoid hands, head and torso |
|---|
| Degrees of freedom per arm | 8 DoF per arm |
|---|---|
| Arm control mode | torque-controlled anthropomorphic arms |
| Hand dof | 4 DoF underactuated humanoid hands |
| Hand actuation mode | underactuated humanoid hands |
| Head dof | 3 DoF head |
| Knee hip kinematics dof | 2 DoF knee/hip kinematic |
| Torso height adjustment | allows the robot to bow and adjust it’s torso height |
| Omni wheel count | three omni-wheels |
| Cognitive architecture | ArmarX cognitive architecture |
|---|---|
| Software architecture | latest version of our cognitive software architecture ArmarX |
| Intended environment | for-human-made environments, like households or nursing facilities Human-made environments such as households and nursing facilities |
|---|---|
| Privacy aware operation | Privacy-aware operation |
| Spoken language interaction | Spoken-language interaction |
| Privacy protection | ensuring privacy of sensitive data |
| Locomotion type | holonomic mobile platform |
|---|
| Arm count | two arms |
|---|
| Hand rgb camera | A RGB camera is integrated in each of these hands |
|---|---|
| Head camera systems | several integrated camera systems |
01 · Official source