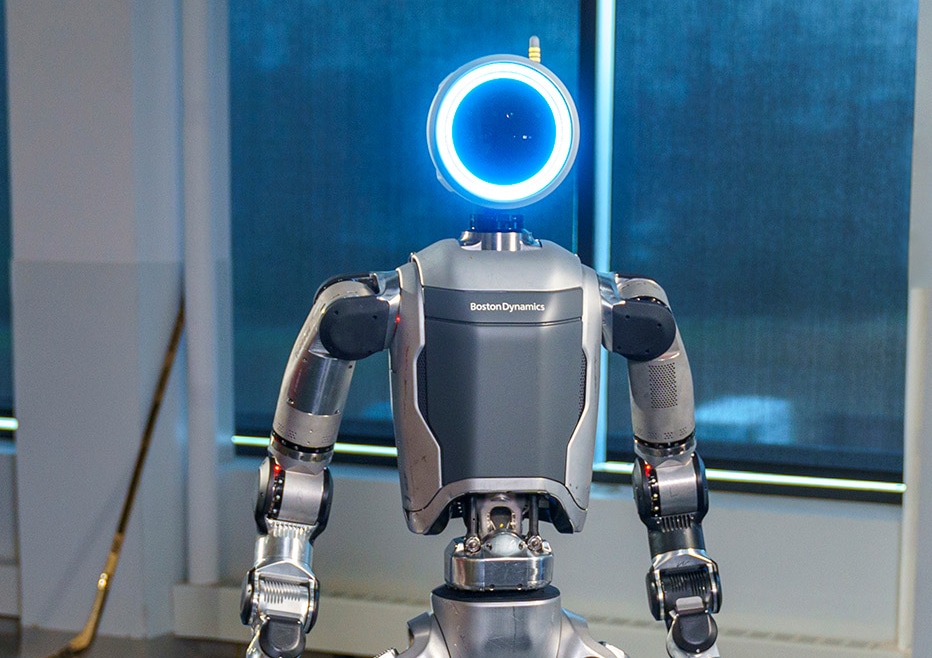
Commercial robotHumanoid
HUMANOID HMND 01 Alpha Wheeled
Official specs 14 · Research specs 8
description: HMND 01 Alpha Bipedal is autonomous, adaptive, and built for real-world impact. · Power/control platform: Powered by KinetiQ
Data & sources
Key specifications

| Height | 1.79 m |
|---|---|
| Weight | 90 kg |
| Total degrees of freedom | 29 DOF |
|---|
| Runtime | 4 hr |
|---|
| Power control platform | Powered by KinetiQ |
|---|---|
| Ai stack | KinetIQ, a proprietary four-layer AI stack built on NVIDIA compute |
| Fleet orchestration | KinetIQ is our own AI framework for end-to-end orchestration of humanoid robot fleets. |
| Embodiment coordination | With KinetIQ, a single system can coordinate robots with different embodiments — wheeled and bipedal — across industrial, service, and home environments. |
| Maximum speed | 2 m/s |
|---|
| General payload | 15 kg |
|---|---|
| End effector configuration | Modular design featuring 12-DOF 5-finger hand or 1-DOF parallel gripper. |
| Sensor configuration | Sensors RGB, depth and 6D F/T sensors, haptic feedback |
|---|---|
| Head sensors and hri | RGB Cameras + 2xDepth sensors. Engaging Multimodal Human Robot Interaction with a head display, LEDs, 6-mic array, speakers. |
| Torso body sensing | 6D F/T sensors. Wrist RGB cameras end effector F/T sensors. Haptic feedback sensors. |
| Protective garments | Interchangeable garments for protection and safety. |
|---|
01 · Official source