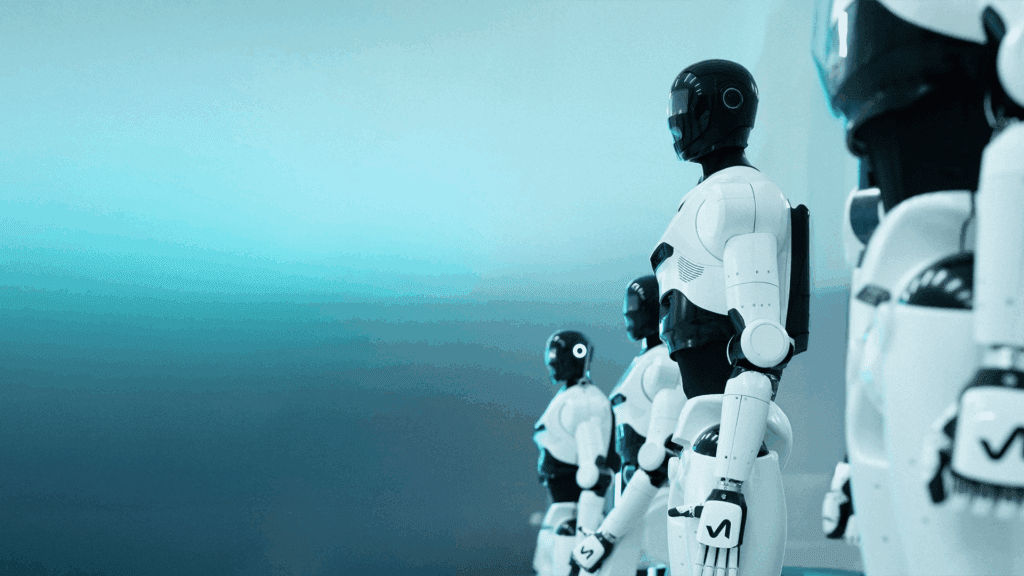
Commercial robotHumanoid
High Torque Mini Hi
Official specs 12
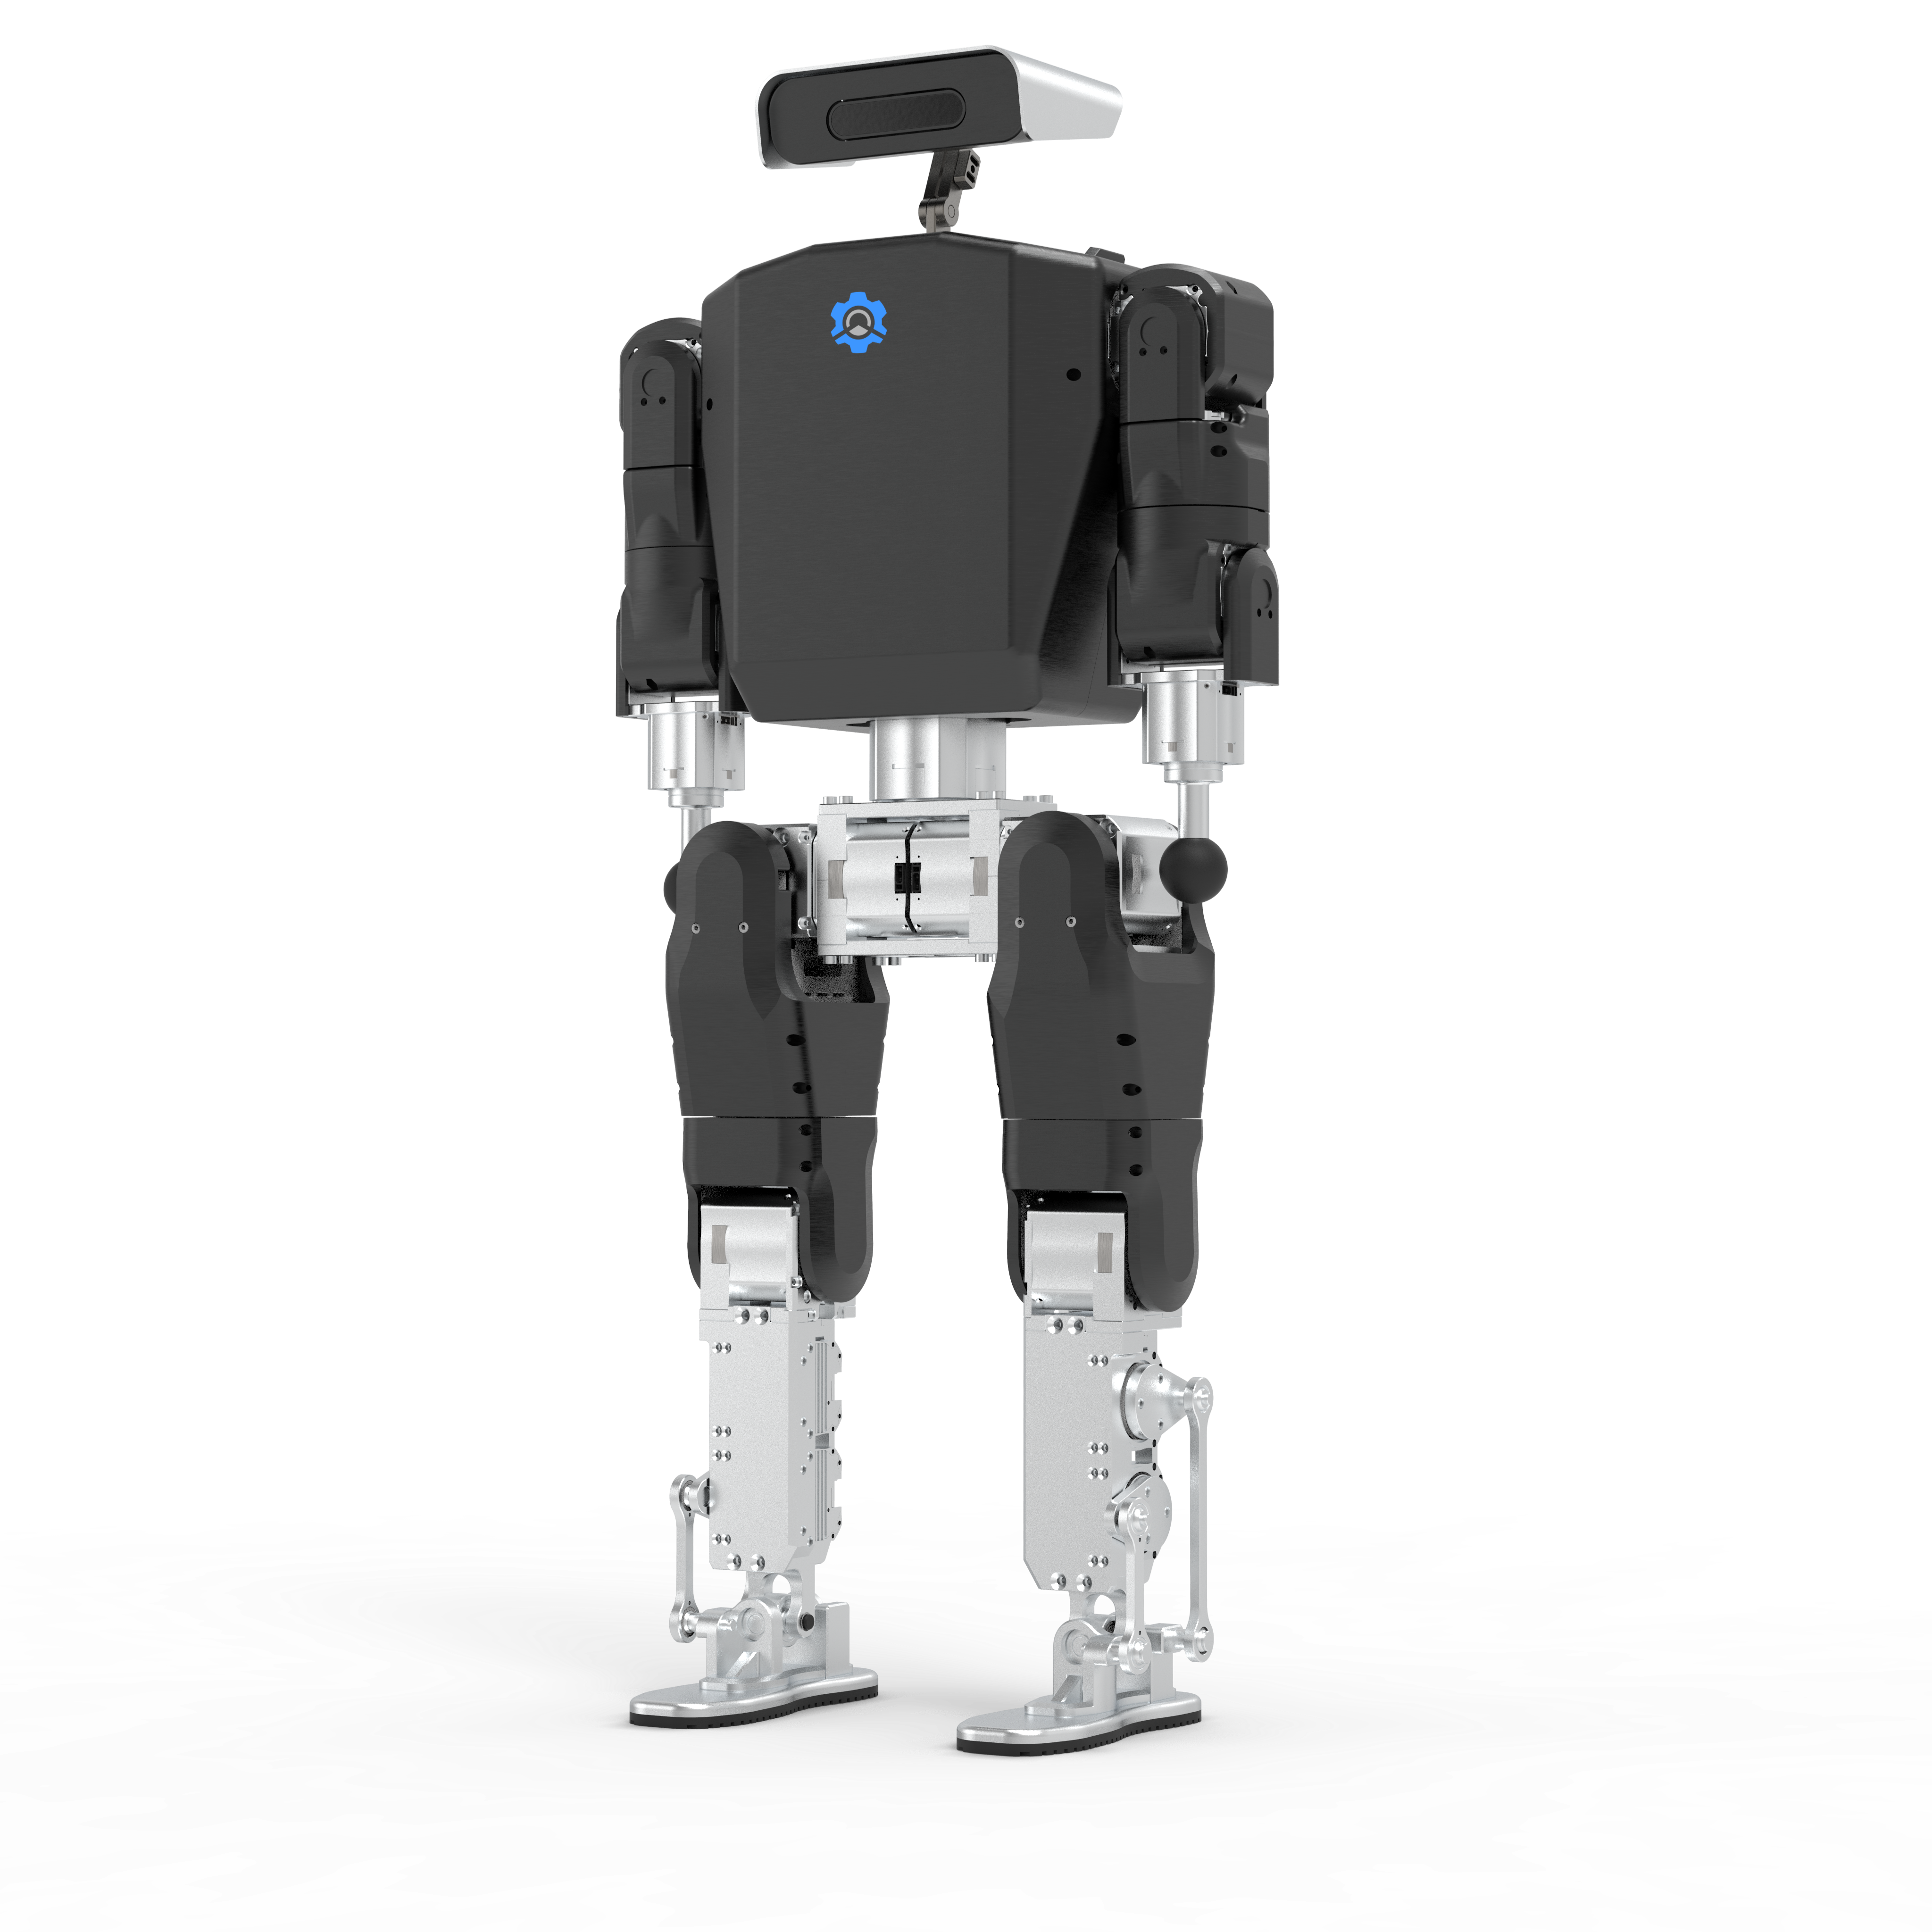
High Torque Mini Pi, a humanoid robot.
Data & sources
Key specifications
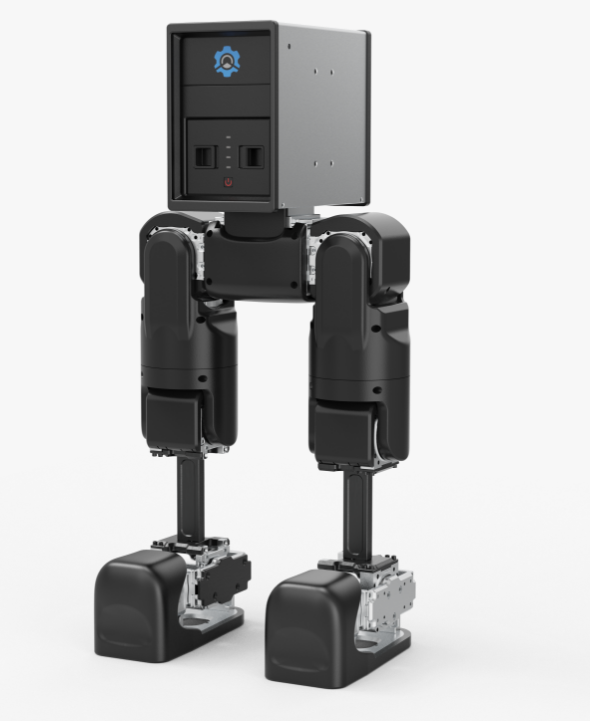
| Height | 0.59 m |
|---|---|
| Height | 59 cm |
| Weight | 7 kg |
| Joint modules | self-developed joint modules throughout body |
|---|---|
| Torque | high torque |
| Runtime | More than 2 hours |
|---|---|
| Battery runtime | over 2 |
| Thermal behavior | stable; no overheating |
| General payload | 10 kg |
|---|---|
| Payload | 10 kg |
| Structural design | modular and quick-release design |
|---|---|
| Interface integration | integrated interfaces |
| Operation visualization | visualized operation |
| Supported extensions | mechanical arm; depth camera; gimbal; voice large model |
| Disturbance rejection | high disturbance rejection |
|---|---|
| Self righting | autonomous self-righting after a fall |
| Motion capabilities | Ip Man squat; football kicking; splits; high-difficulty motions |
| SDK and algorithms | open SDK; open-source ZMP, MPC, and reinforcement-learning algorithms |
|---|
01 · Official source