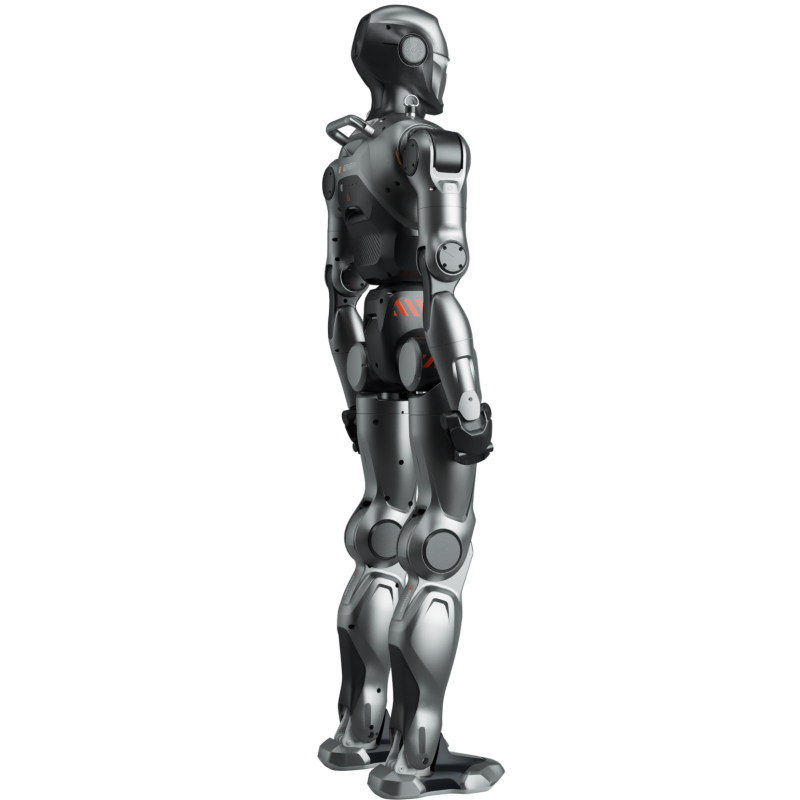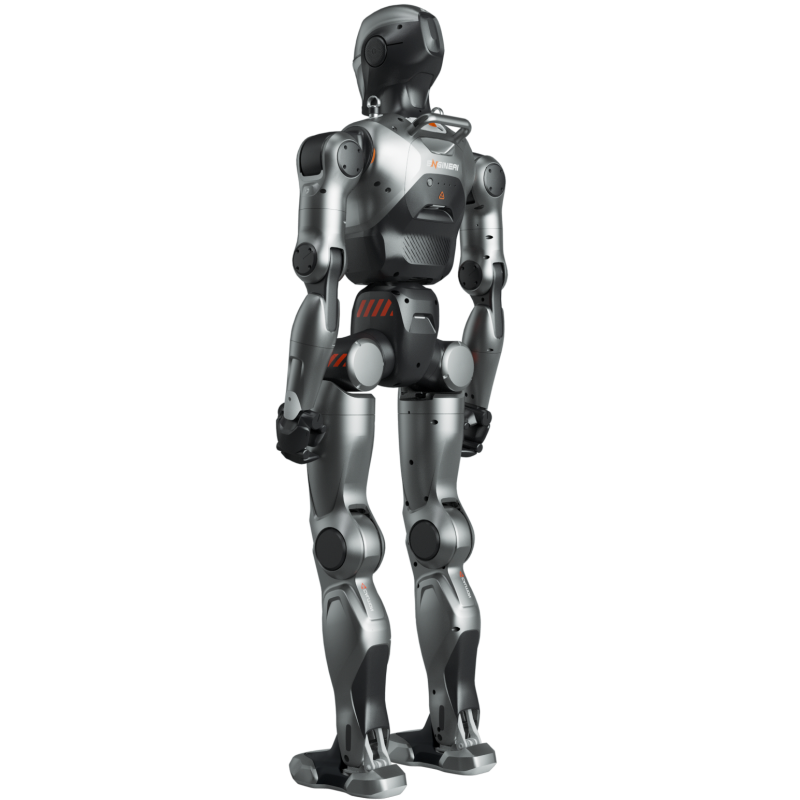
Commercial robotHumanoid
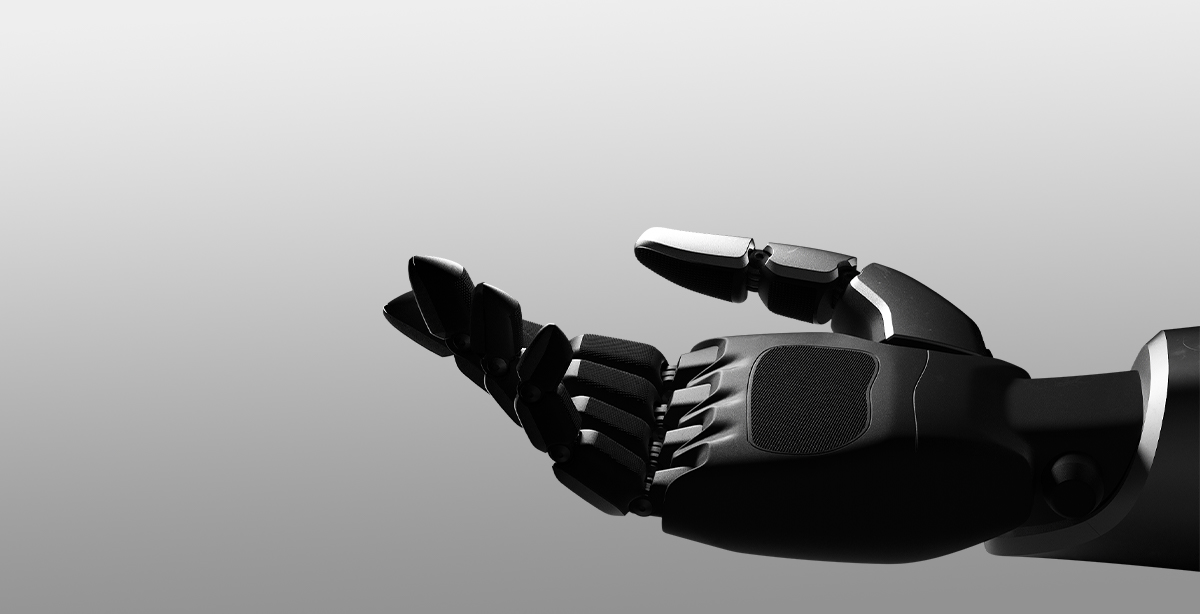
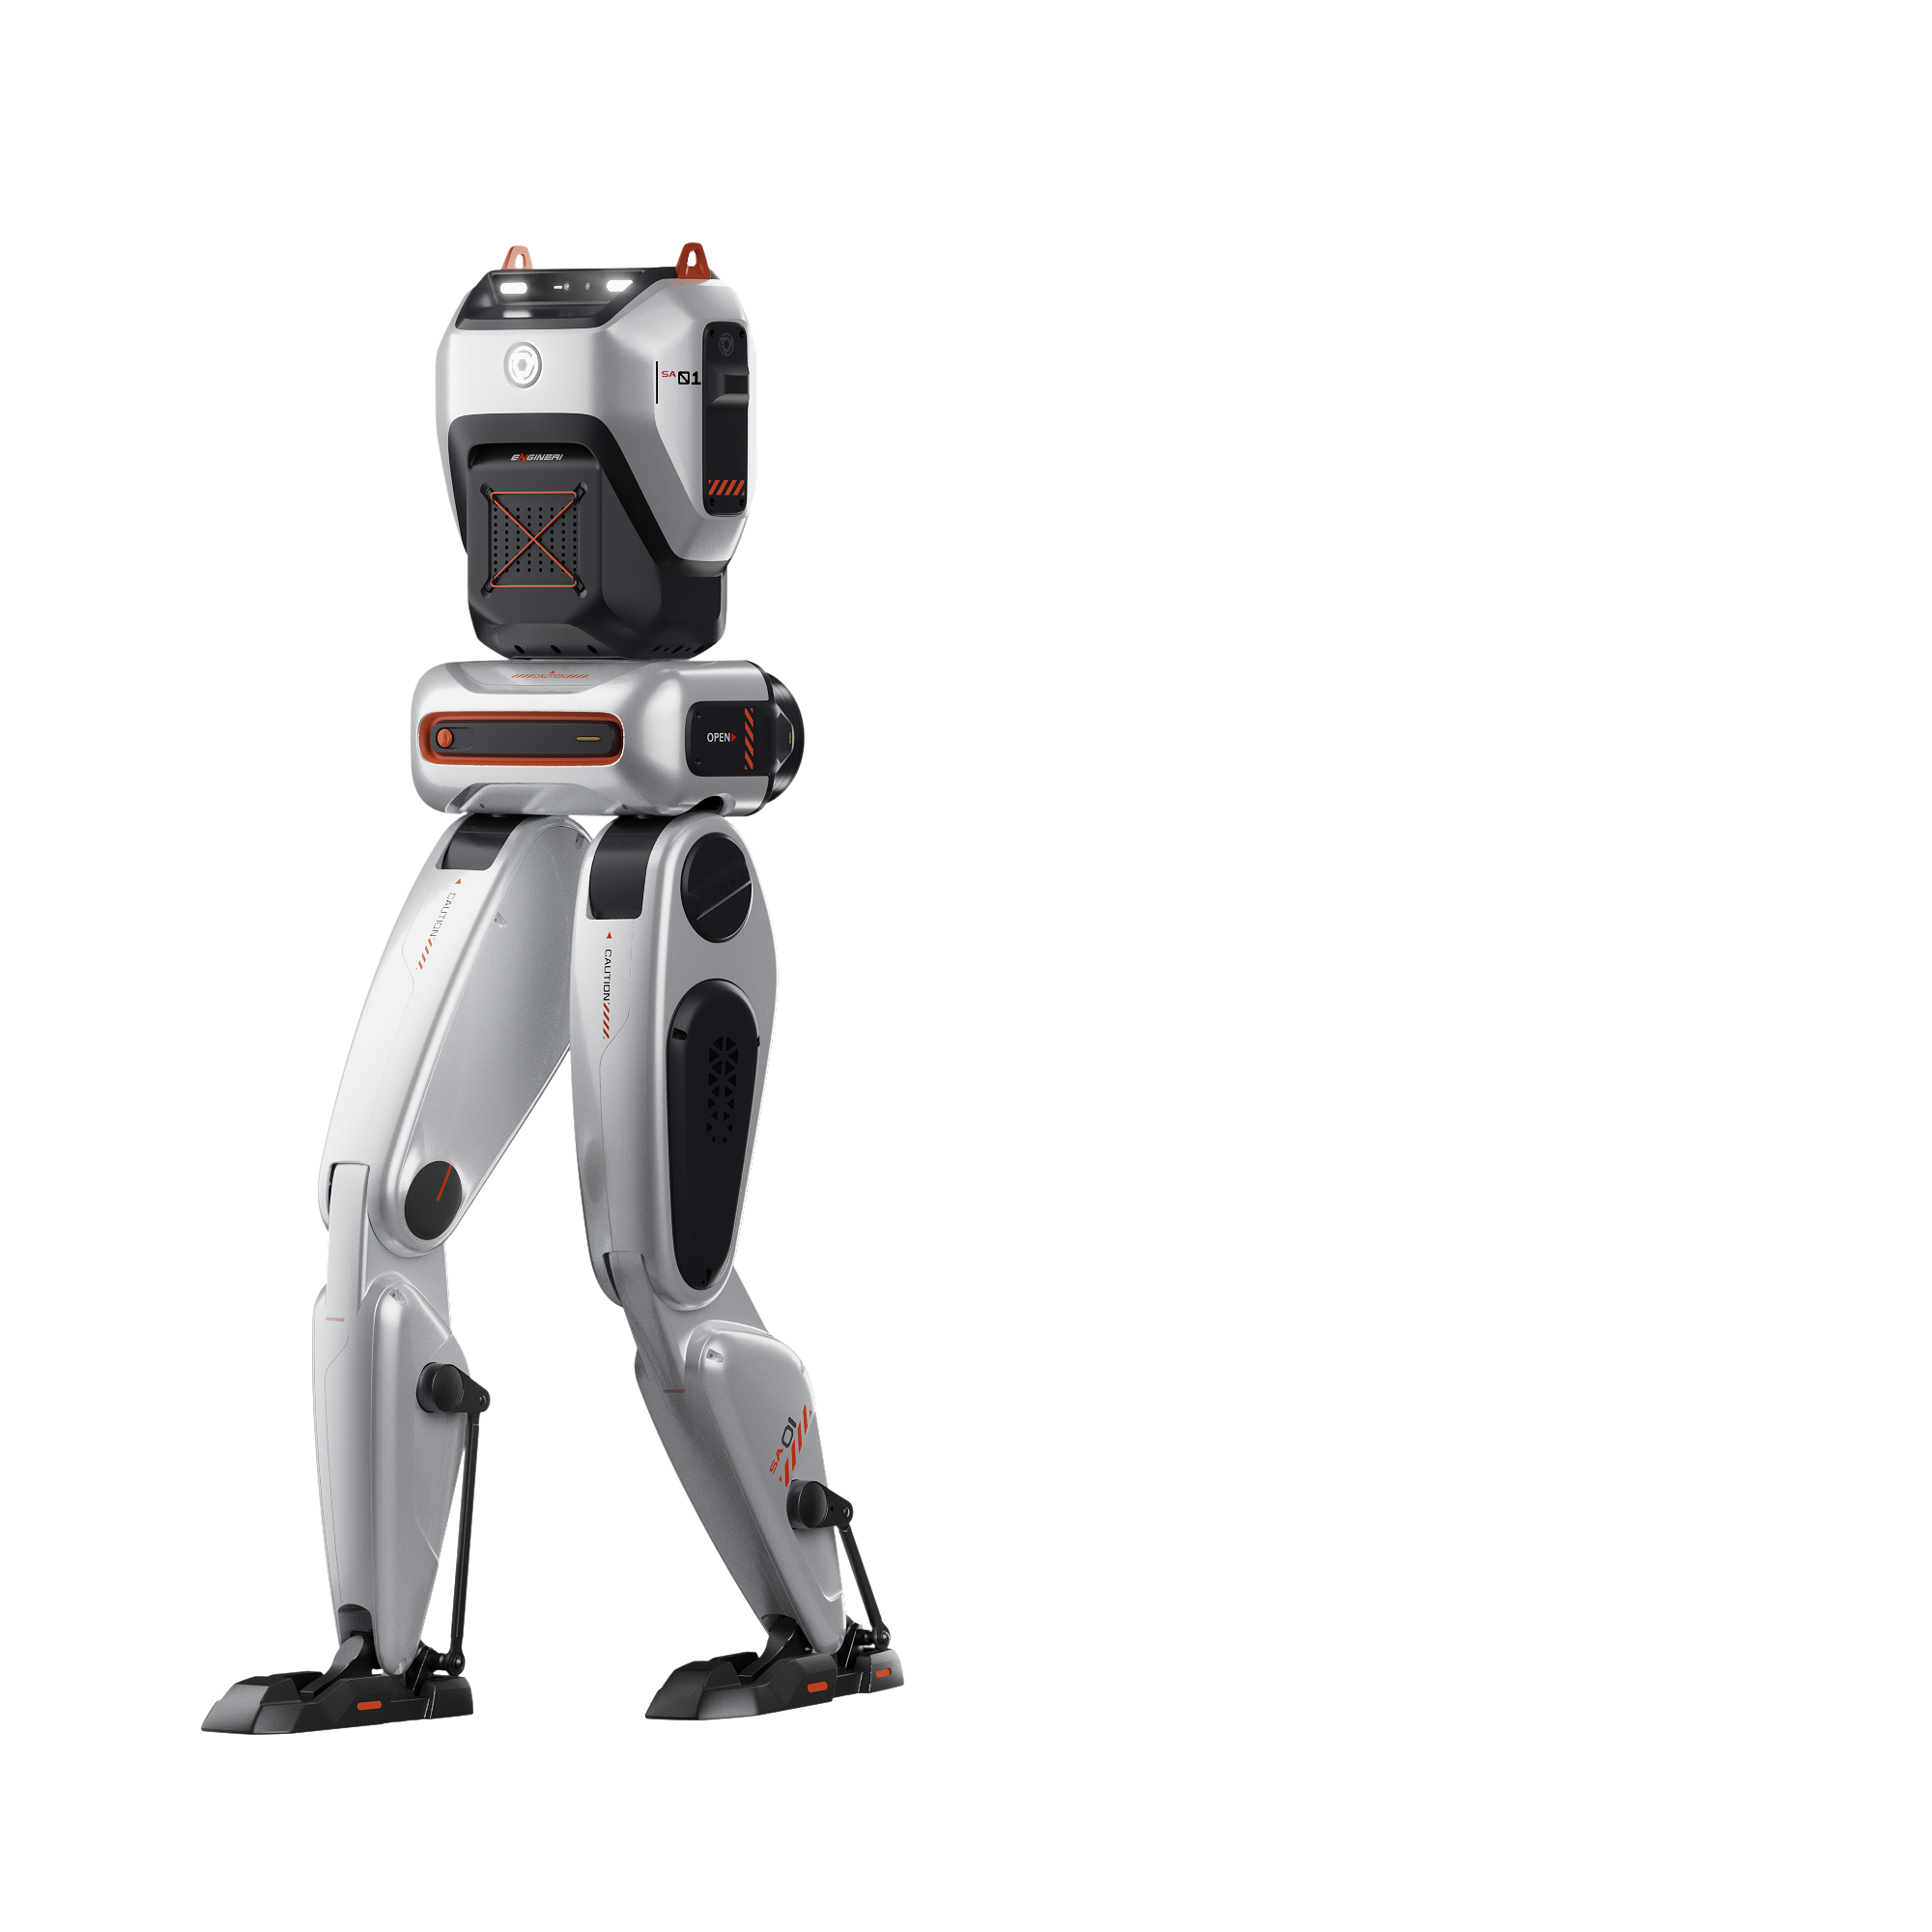
EngineAI SA01
Official specs 10
Product description: lightweight, highly-dynamic, and fully-open embodied intelligent agent. · capabilities: A lightweight, highly-dynamic, and fully-open embodied intelligent agent.
Data & sources
Key specifications
| Height | 1.38 m |
|---|---|
| Height | 1.38 m |
| Weight | approximately 40 kg |
| Weight | about 42 kg |
| Standing dimensions | 1.4 m (H) × 0.53555 m (W) × 0.25266 m (D) |
| Body height | 1.38 m |
| Body weight | 40 kg |
| Total degrees of freedom | 24 DOF |
|---|---|
| Total degrees of freedom | 24 DOF |
| Integrated joint peak torque | 130 N·m |
| Peak torque density | 130 N·m/kg 100 N·m/kg |
| Waist rotation | 320 degrees free rotation |
| Waist rotation | 320° >300° |
| Degrees of freedom per arm | 5 DOF |
| Degrees of freedom per leg | 6 DOF |
| Hip joint range | R-29°~+134°, P-180°~+140°, Y-90°~+230° |
| Torque | up to 300 N·m |
| Lumbar joint range | -230°~90° |
| Knee joint range | -30°~+137° |
| Joint type | Planetary |
| Maximum torque | 50 N·m |
| Maximum motor speed | 8400 rpm |
| Reduction ratio | 25 ratio |
| Motor weight | 0.5 kg |
| Calf thigh length | 686.5 mm |
| Hollow joint internal routing | supported |
| Degrees of freedom | 24 degrees of freedom |
| Waist rotation | 320 degrees |
| Battery capacity | 10000 mAh |
|---|---|
| Runtime | nearly 2 h |
| Charging power | 54.6 V 4.5 A hours |
| Charging time | nearly 2 h |
| Learning methods | reinforcement learning and imitation learning |
|---|
| Maximum speed | >2 m/s |
|---|---|
| Forward somersault | forward somersault |
| Environment adaptability | adapts to multiple complex environments |
| Compute module | NVIDIA Jetson Orin NX (16G) |
|---|---|
| Cpu | 4-core high-performance CPU |
| Secondary development support | support |
| Ros support | open-source AI framework with full ROS support |
| Neural architecture | end-to-end neural network solution |
| Price | 20000 USD |
|---|
| Signature light | signature star halo light |
|---|---|
| Touchscreen | touchscreen supported |
| Handheld remote control | supported |
| Lighting configuration | Eye lamp, Buttock lamp |
| Touchscreen control interface | touchscreen display on chest |
| General payload | 15 kg |
|---|
| Joint encoder | Dual Encoding |
|---|---|
| Perception sensors | Two depth cameras (head and waist) |
| Vision sensors | stereo depth cameras and LiDAR |
01 · Official source
02 · Official source
03 · Official source