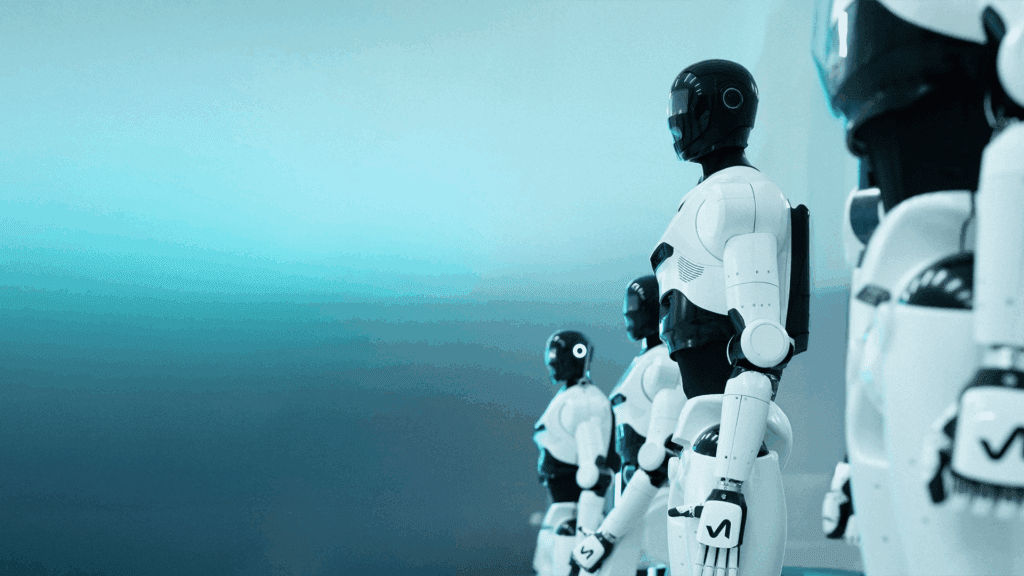
Commercial robotHumanoid
1X Technologies 1X NEO
Official specs 54 · Research specs 16
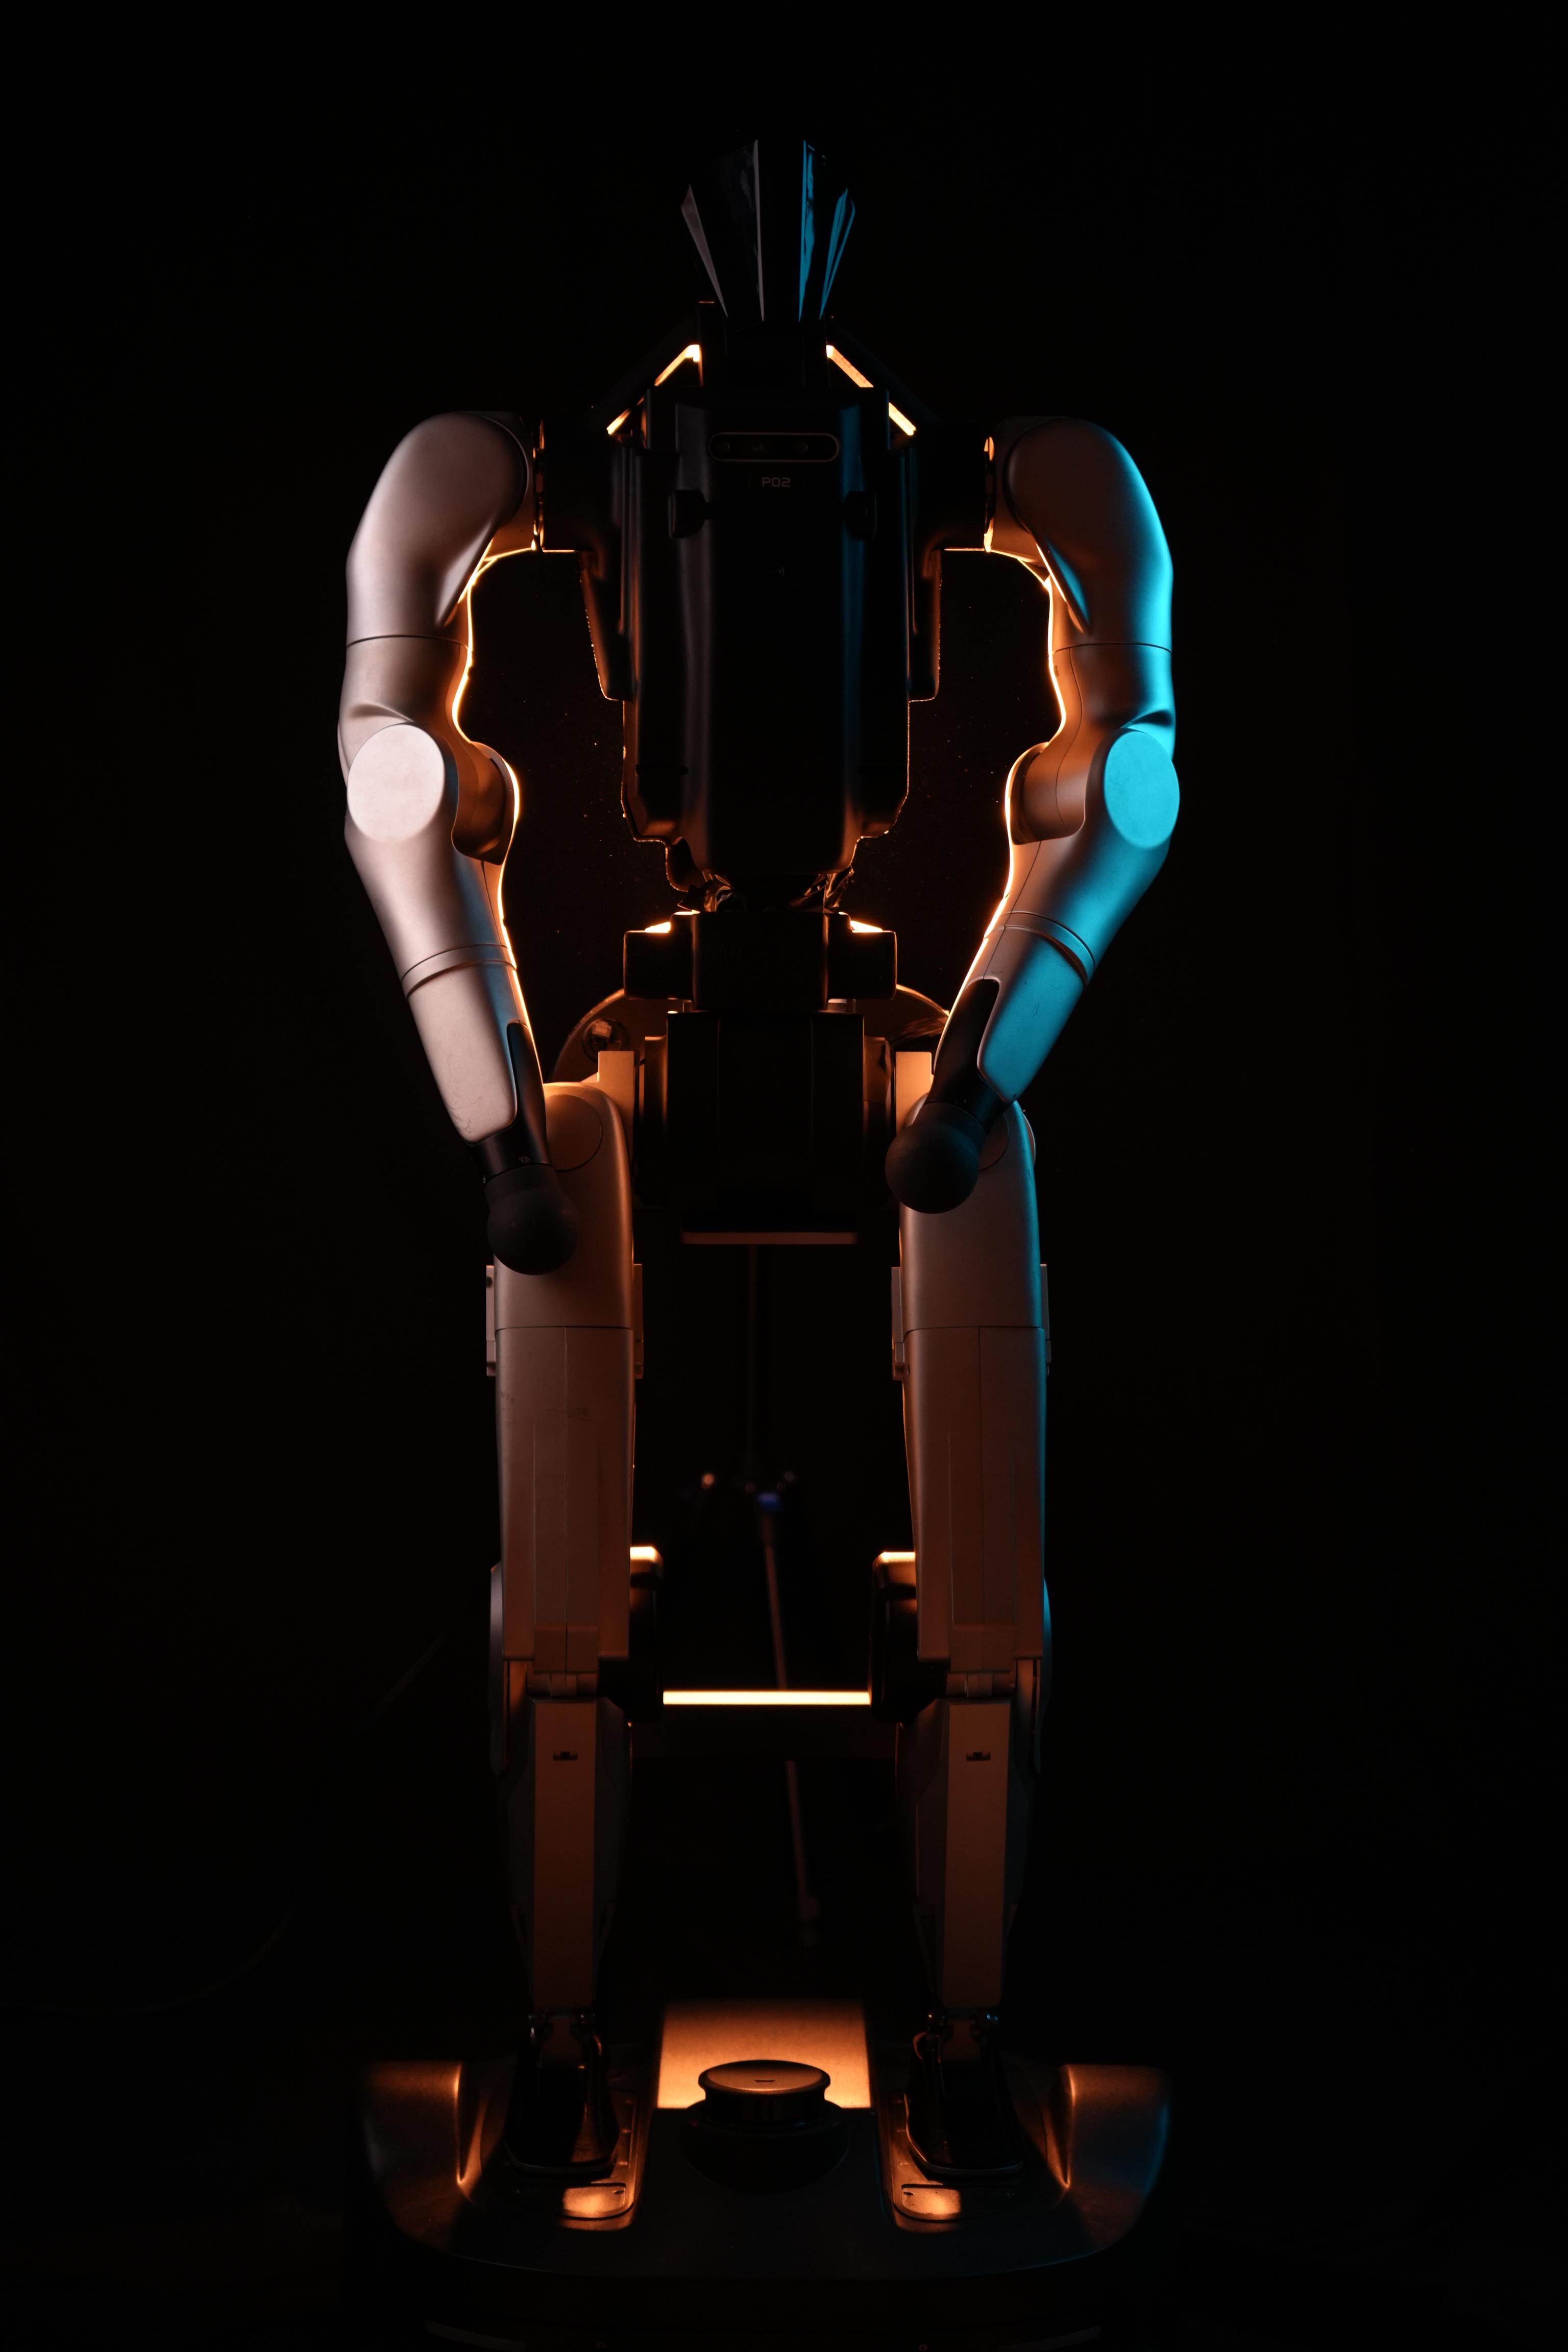
Digital Huaxia Xingxingxia P02, a humanoid robot.
Data & sources
Key specifications
| Motion control algorithm | self-developed motion-control algorithm |
|---|
| Locomotion type | Wheeled and bipedal locomotion switchable |
|---|---|
| Coordinated walking | multi-joint coordinated walking |
| Form count | 2 forms |
| Mobility modes | switchable wheeled and bipedal modes |
| Robot type | high-performance general-purpose humanoid robot |
|---|
| Architecture | EtherCAT architecture |
|---|---|
| Computing | self-developed computing |
| Voice large model | voice large model |
| Fine manipulation | fine manipulation |
|---|
| Depth vision | depth vision |
|---|
| Commercial use case | mall reception |
|---|---|
| Commercial use case | exhibition hall guidance |
| Service solution | full-stack intelligent service solution |
01 · Official source