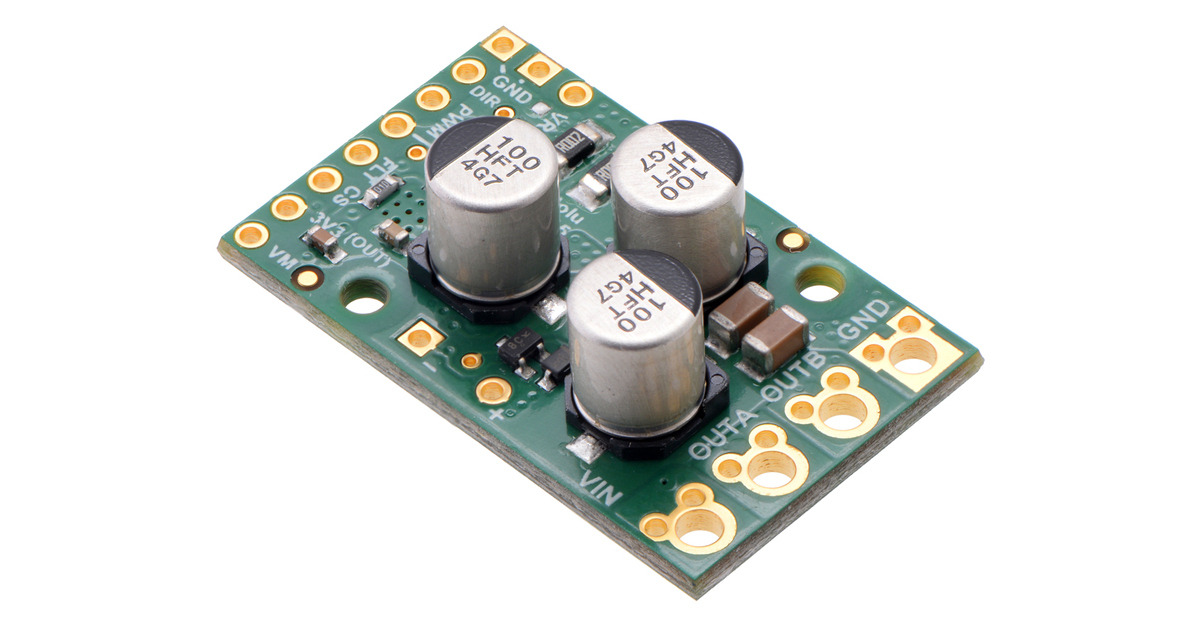
Dimensions
| Length | 33.02 mm |
|---|---|
| Width | 20.32 mm |
| Weight | 5 g Other recorded values
|
| Dimensions | 1.3 × 0.8 in (33.02 × 20.32 mm) Other recorded values
|
Electrical
| Minimum input voltage | 6.5 V |
|---|---|
| Maximum input voltage | 40 V |
| Logic voltage | 5.5 V Other recorded values
|
| Continuous output current / channel | 21 A |
| Operating voltage | 6.5–40 V |
| Continuous output current | 21 A |
| Current sense | 0.02 V/A |
| Input voltage (min) | 6.5 V |
| Input voltage (max) | 40 V |
| Current Sense Method | current_sense |
| Input voltage | 6.5 V – 40 V |
Control
| Communication interfaces | PWM;analog |
|---|---|
| Control modes | duty_cycle;voltage |
| Control algorithm | PWM |
| Maximum PWM frequency | 100 kHz |
| PWM frequency | 100 kHz |
| Switching Frequency Khz | 100 |
Mechanical
| Board architecture | standalone_board Other recorded values
|
|---|
General
| Board kind | motor_driver Other recorded values
|
|---|---|
| Primary application | robotics;mobile_robot;general |
| Safety features | reverse_polarity;overcurrent |
| Motor drive | brushed_dc Other recorded values
|
| Motor channels | 1 |
| Phases | 2 |
| Protections | reverse_polarity;overcurrent |
| Pololu item | 2995 |
| Motor supply | 6.5–40 V |
| Continuous output | 21 A/channel without heat sink |
| Size | 1.3 × 0.8 in |


